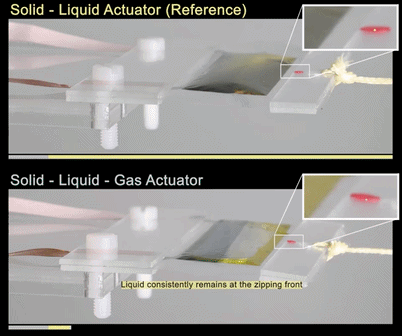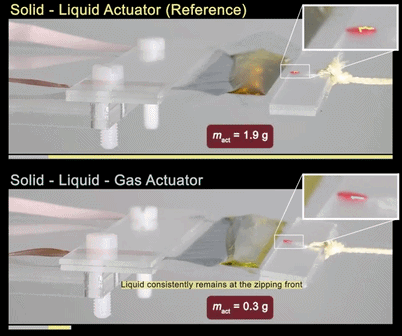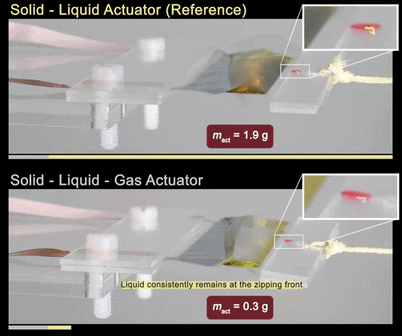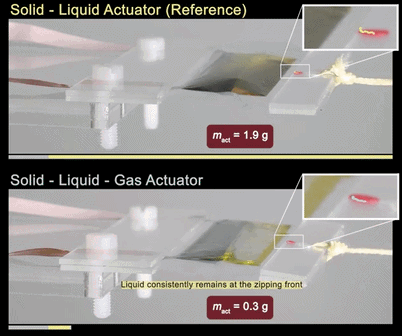
Ultralight soft electrostatic actuators based on solid-liquid-gas architectures
The introduction of the third phase, gaseous dielectrics, into solid-liquid actuators allows for the creation of ultralight soft electrostatic actuators.
publication-type
The introduction of the third phase, gaseous dielectrics, into solid-liquid actuators allows for the creation of ultralight soft electrostatic actuators.
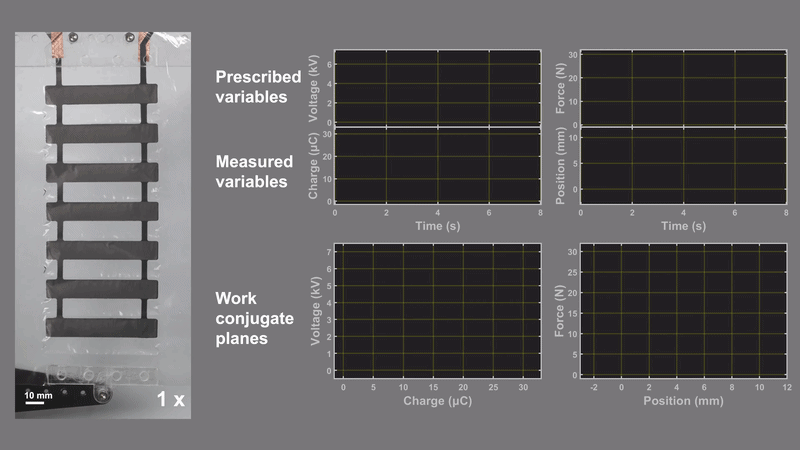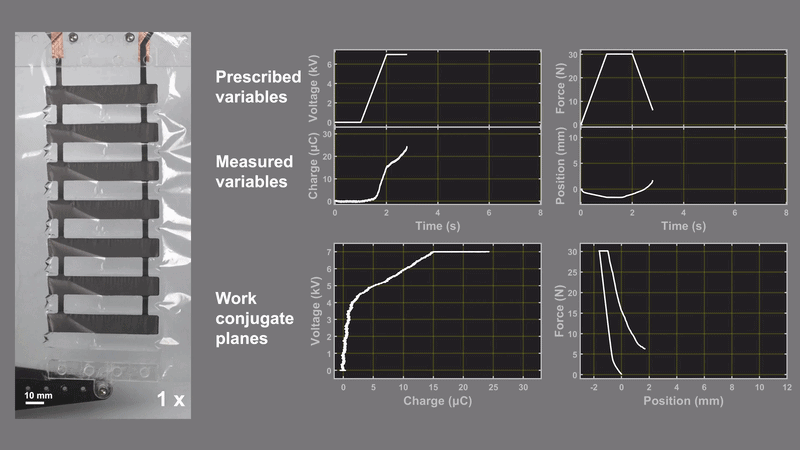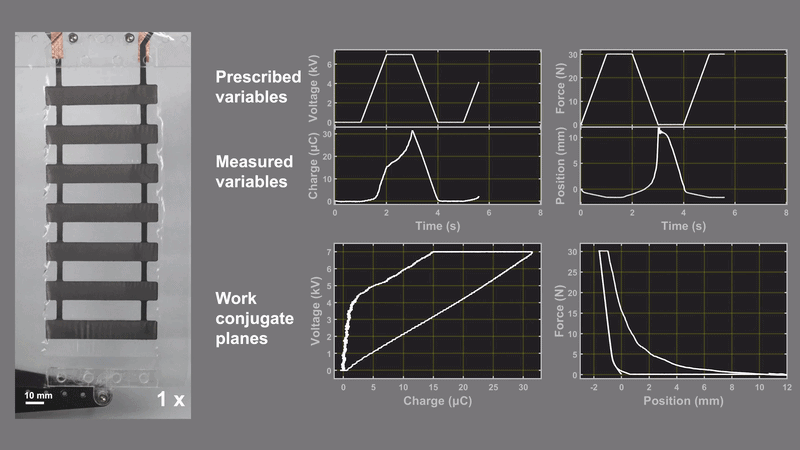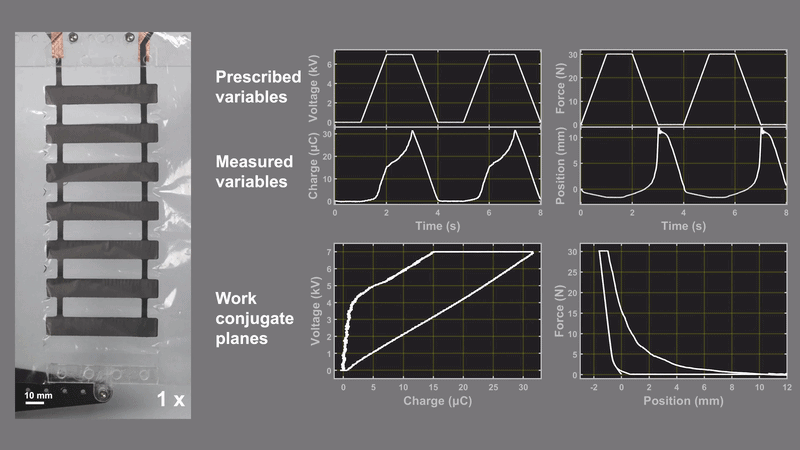
Closed cycles on the work conjugate planes enables study and enhance energy efficiency of soft electrostatic actuators.
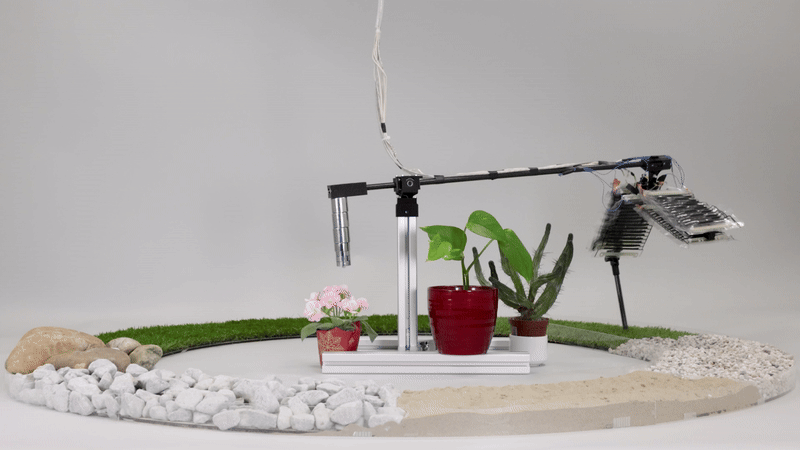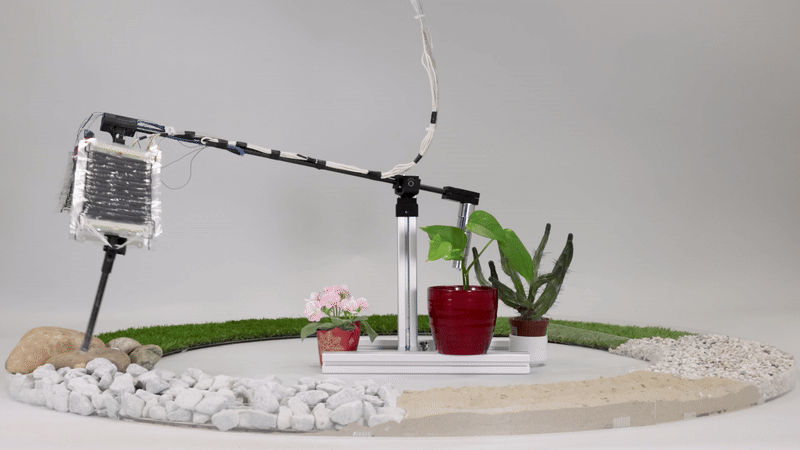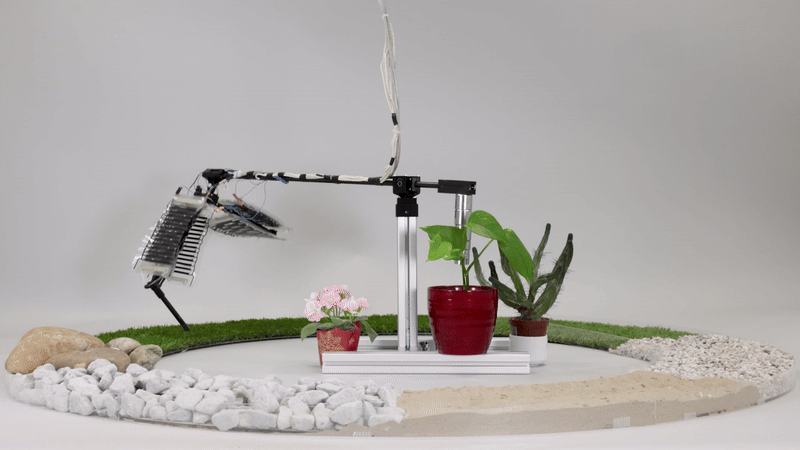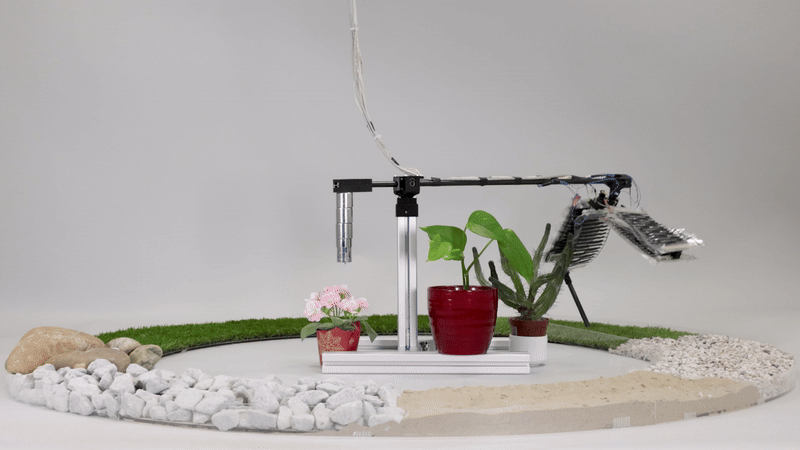
Soft electrohydraulic artificial muscles enable robotic legs for agile, adaptive, yet energy-efficient locomotion.
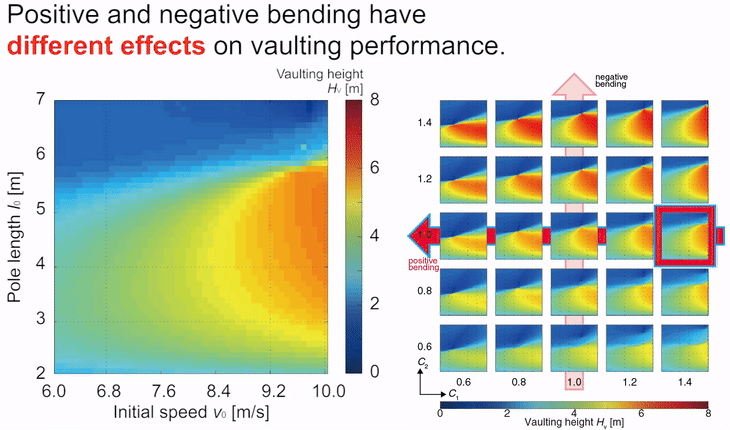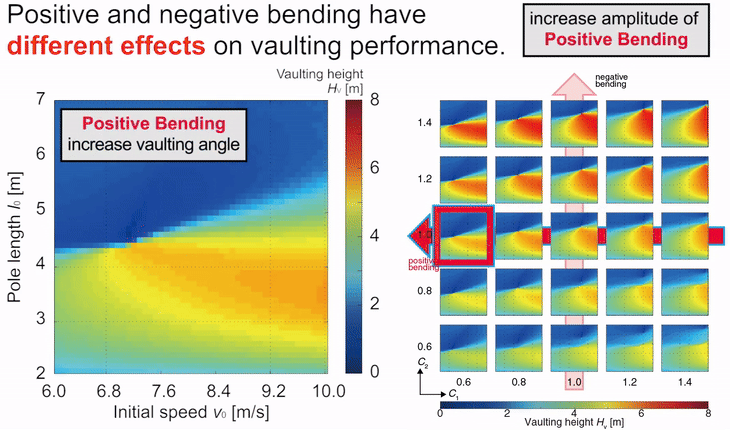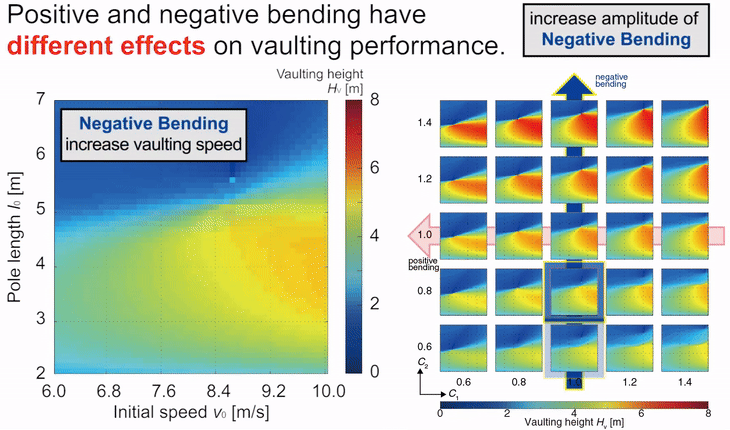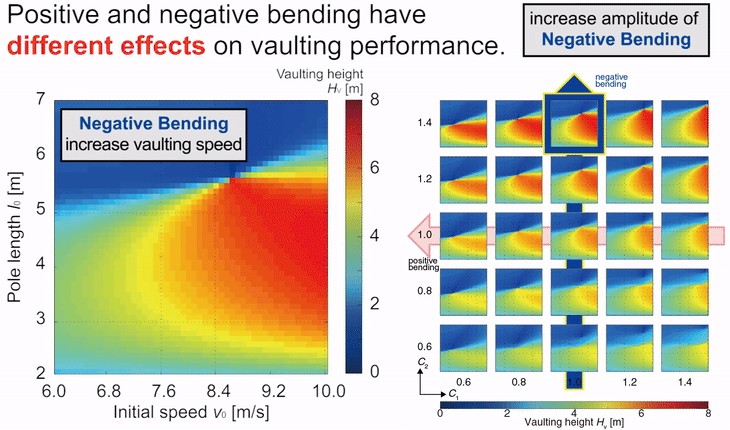
Globally explore sensitivities and interacteve effects of motion parameters during pole support phase to increase vaulting height
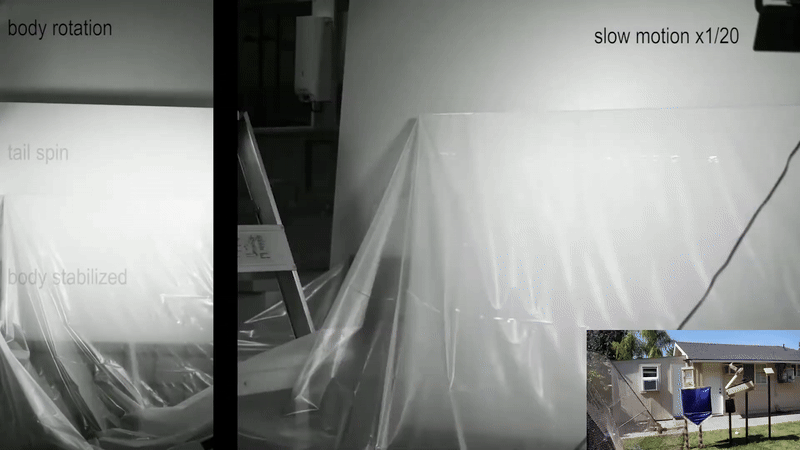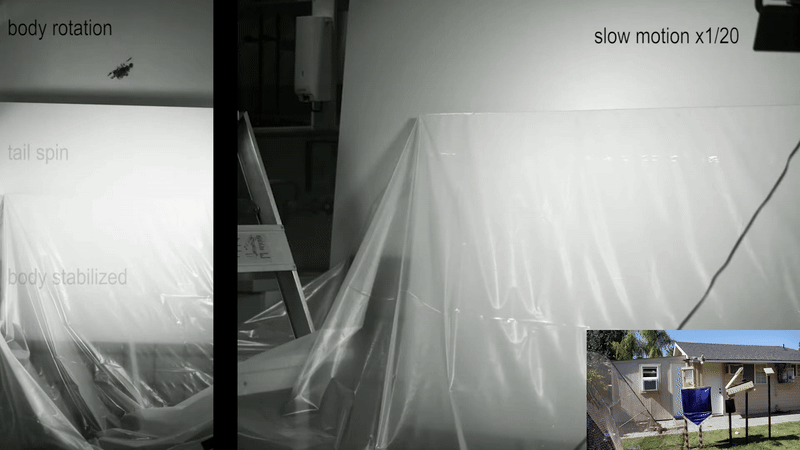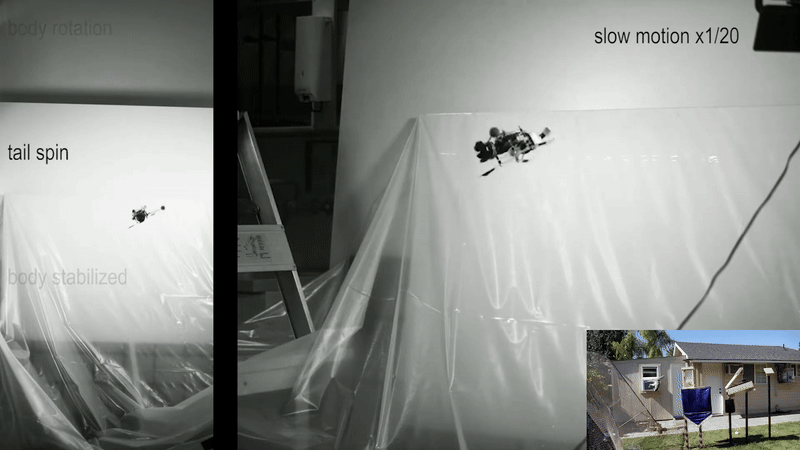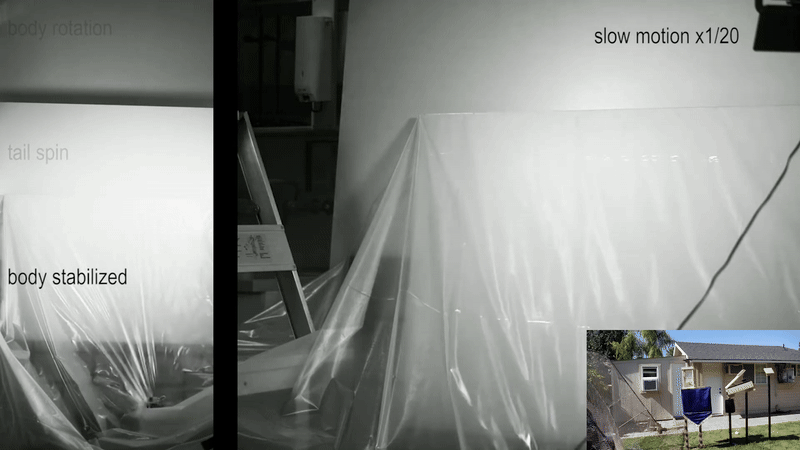
Squirrel’s very light tail (just 3% of body mass) can inertially stabilize their body from unexpected falls.
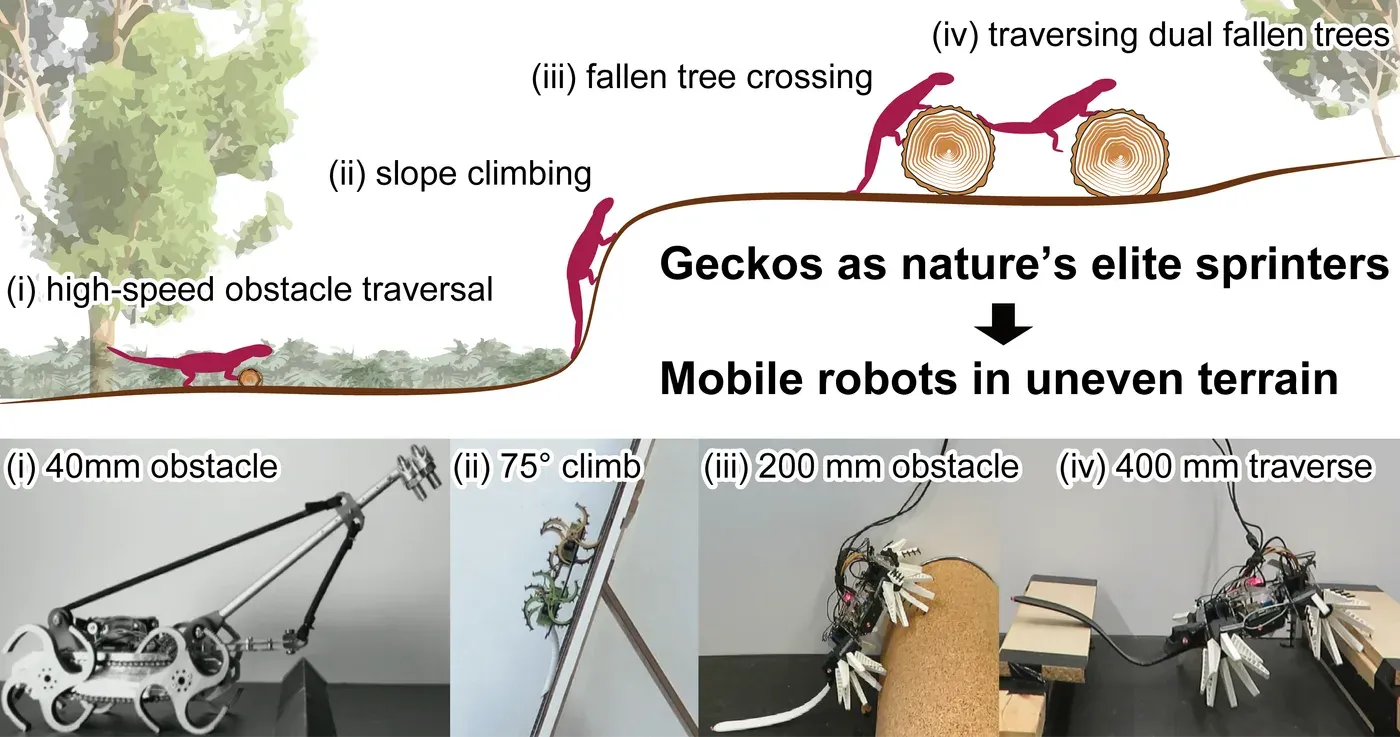
Geckos, as nature's elite sprinters, inspire mobile robots on uneven terrain.
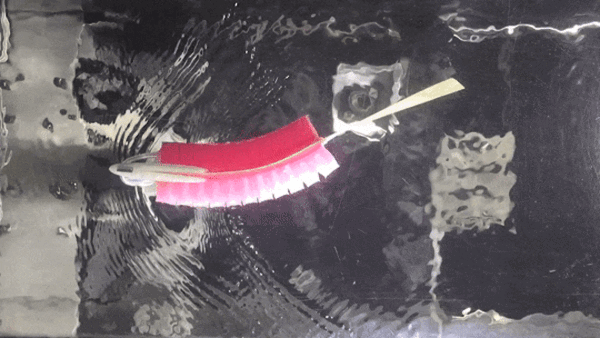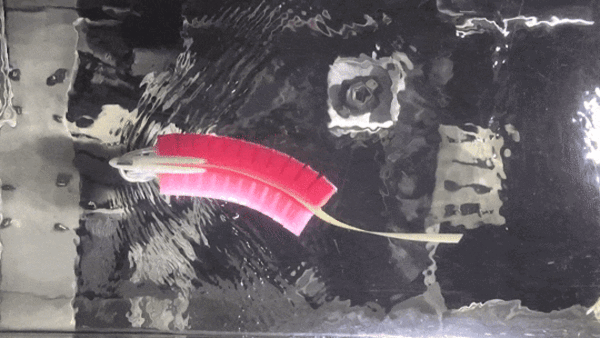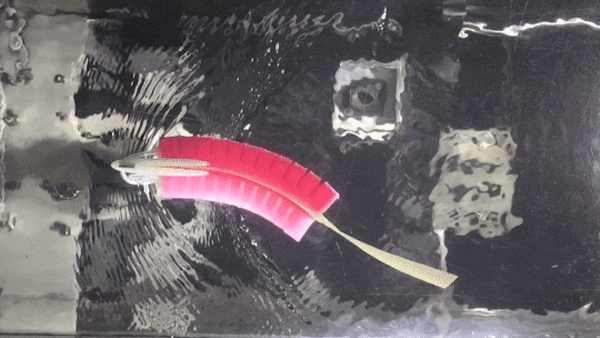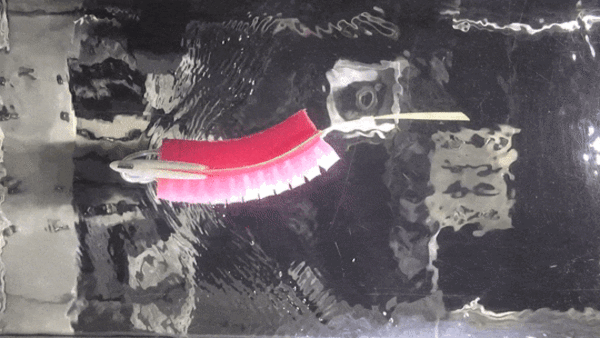
Soft robotic fish: real-time tail-beat control using eGaIn strain sensing and a lightweight-data-driven model.
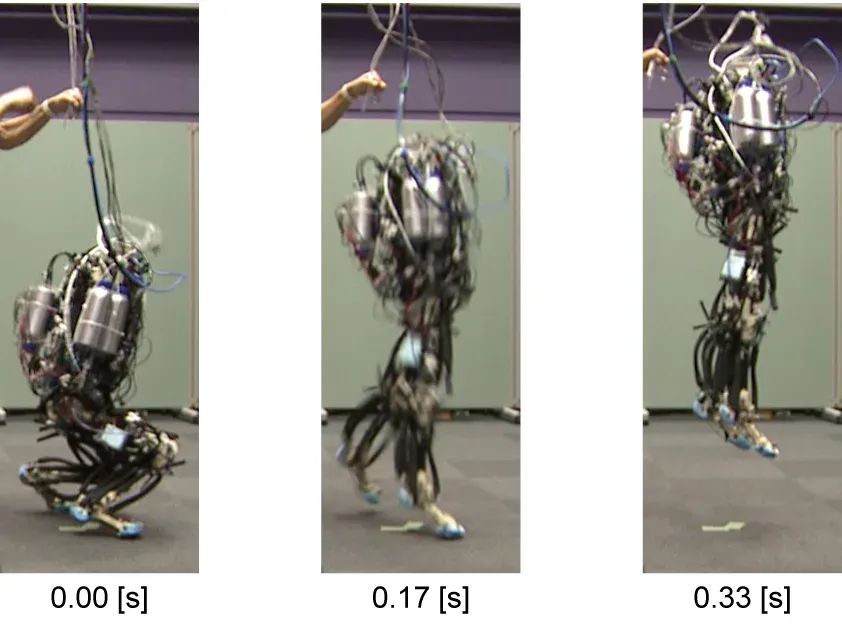
Angle-dependent moment arm (ADMA) extends the range of possible jumping postures for musculoskeletal robots.
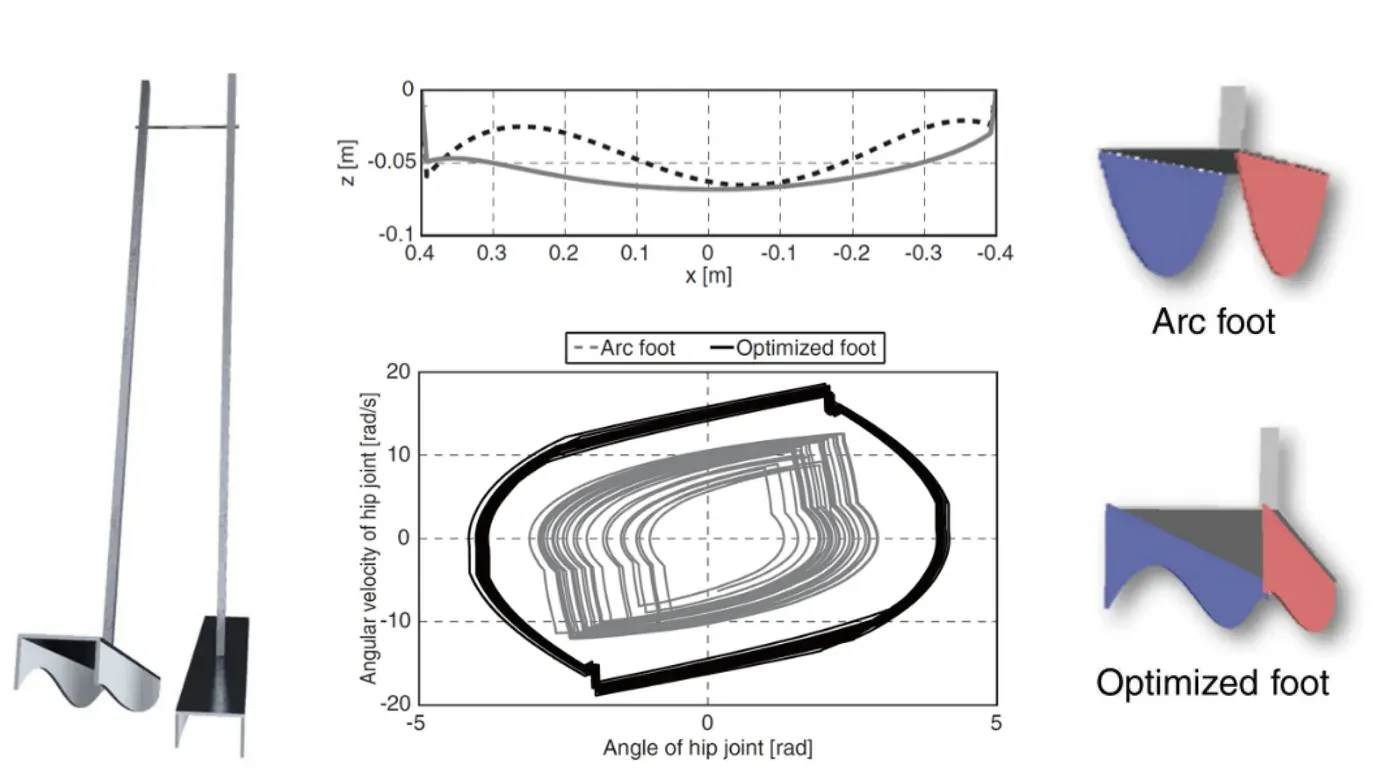
Optimized feet shape of the passive dynamic walker enhance its walking robustness in slope angles.