
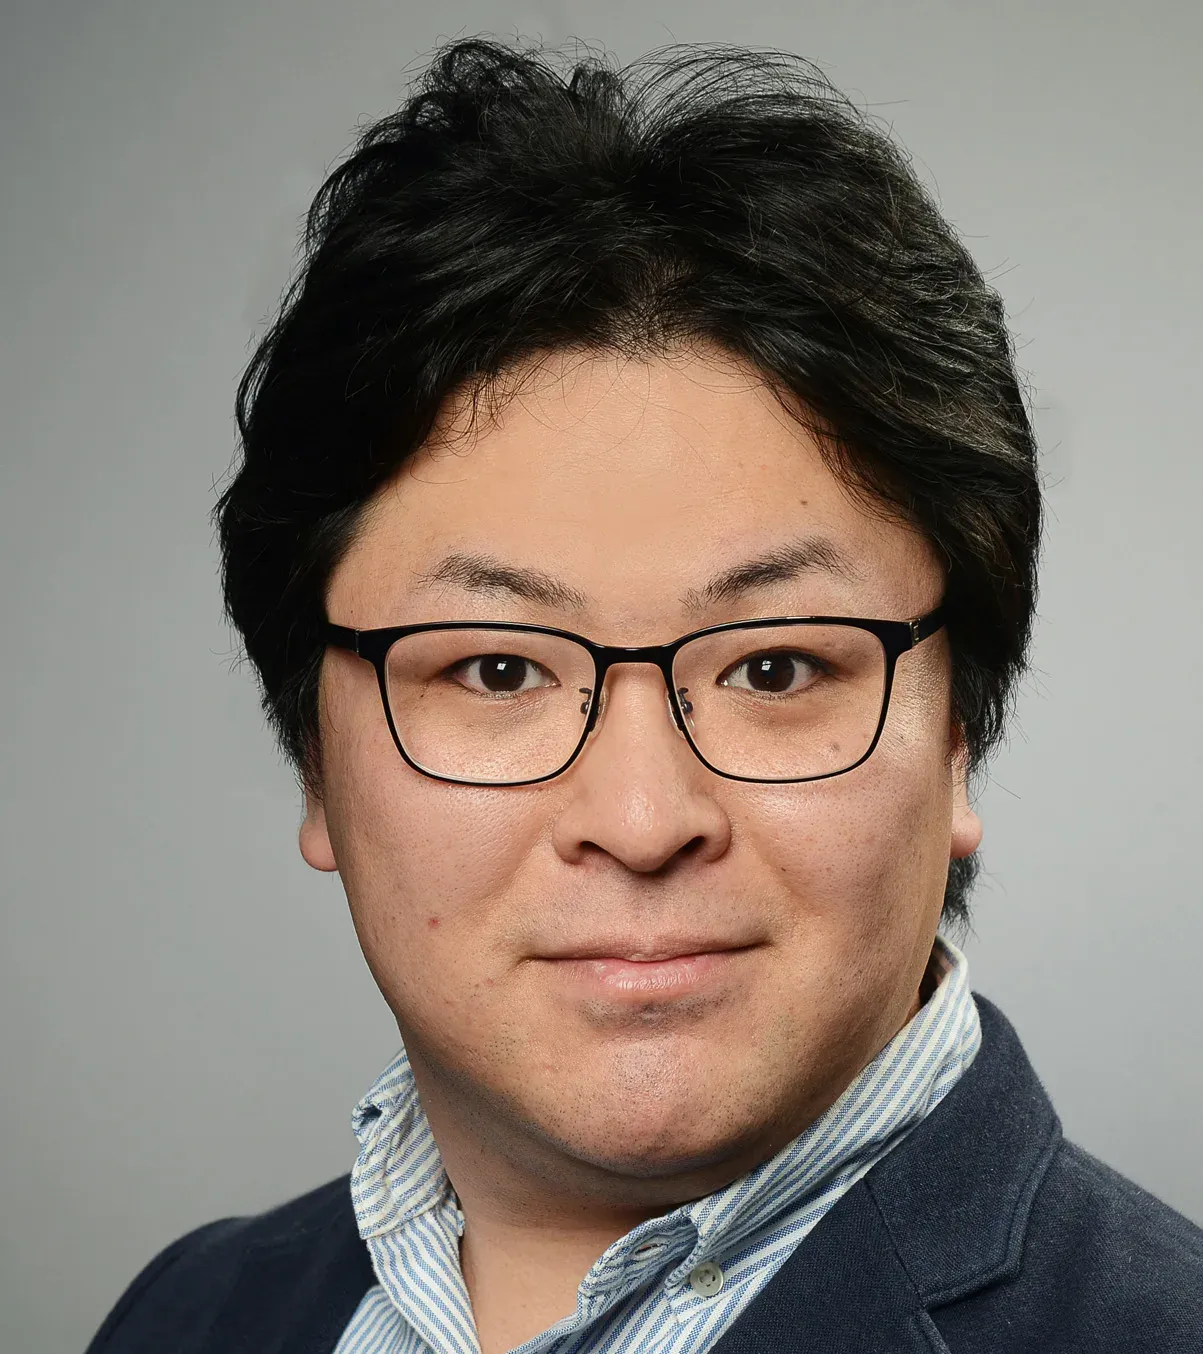
Toshihiko Fukushima
Senior Researcher
“Work Hard, Play Harder”
Download CV
🌱 Motivation
Understand nature through robots and evolve the robots
- Observe animals, develop and test robotic animals to understand their behavior and intelligence
- Engineer and functionalize the intelligence to expand the robots’ task space
Control complex systems with a simple law
- Control fuzzy Human-in-the-loop systems in the real world
- Utilize embodied intelligence and inherent feedback systems
Fast prototyping and quick iterations
- What I cannot create, I do not understand.
- You cannot model it if you cannot see its unexpected behavior in the real world
- Robotics Bio-inspired robot, Legged robot, Musculoskeletal robot, Biomimetics, Embodied intelligence, Locomotion, Pneumatic actuator, Electrohydraulic actuator, HASEL, Sensor fusion
- Mechatronics Mechanical design, Electrical design, BLDC motor, Embedded system, Arduino
- Software & CAD Matlab, Simulink, Simscape, MuJoCo, Genesis, DeepLabCut, Solidworks, CATIA
- Automobile Steering system, Vehicle test, By-wire system, NVH, HiL, MBD, Functional safety
- Automotive software dSPACE, MicroAutobox, ControlDesk, ModelDesk, ASM, CarSim
- IT Adobe, Illustrator, Photoshop, Premiere Pro, UNIX, DNS, Apache, Samba, OpenSSH, Bootstrap
💻 Language
Natural language
- 🇯🇵 Japanese (Native)
- 🇺🇸 English (Professional)
- 🇩🇪 German (Beginner)
- 🇨🇳 Chinese (Beginner)
Computer language
- Programming: Python, C, C++, Shell script
- Numerical computing & simulation: MATLAB, Simulink
- Embedded development: Arduino, ESP32, STM32
- Image processing & graphics: OpenCV, Processing
- Web: HTML5, CSS, PHP
- Typesetting:
Senior Researcher — OMRON SINIC X Corporation
- Research embodied intelligence in robotics
Guest Scientist — Max Planck Institute for Intelligent Systems (MPI-IS)
Associated Fellow — Max Planck ETH Center for Learning Systems (CLS)
- Research embodied intelligence in soft robotics
- Collaborate with international institutions and universities
- Supervise master and bachelor students
Doctoral Researcher — Max Planck Institute for Intelligent Systems (MPI-IS)
- Research soft robotics with soft electrohydraulic actuators (HASELs)
- Develop musculoskeletal robotic legs for agile, adaptive, yet energy-efficient locomotion
- Develop compact sensing and controlling devices for high-voltage-driven robots (~10kV) to optimize the system efficiencies
Research Engineer — Max Planck Institute for Intelligent Systems (MPI-IS)
- Research morphological intelligence of animals and deploy them to robotic systems
- Published 3 journal papers about robotic locomotion inspired by geckos, fish and squirrels
Application Engineer — NTN Wälzlager (Europa) GmbH
- Develop bearing systems for automotive customers (EV motor, engine, transmission, steering, etc.)
- Coordinate worldwide development teams and managed customer requirements and their deliveries
Control System Engineer — Toyota Motor Sports GmbH
- Develop an Active Suspension System and promote Model based Development (MBD)
- Coordinate international branches and teams, and integrate multi-located systems
Chassis System Engineer — Toyota Motor Corporation
- Develop a steering-by-wire system for concept cars (Feb. 2018 — Oct. 2018)
- Develop a steering and leaning by-wire system for a 3-wheeled ultra compact EV (Jan. 2016 — Jan. 2017)
- Develop Electric Power Steering Systems (EPS) for mass production cars (Jun. 2014 — Dec. 2015)
Technical Assistant — The University of Tokyo
- Maintain UNIX server systems (DNS, mail, HTTP and Samba)
- Renew website of a research lab. (Twitter Bootstrap, PHP)
Internship — Toyota Boshoku Corporation
- Develop a charge-discharge system for a compact car
🎓 Education
PhD - Engineering — University of Stuttgart (research at Max Planck Institute for Intelligent Systems (MPI-IS))
- Robotic Materials Department led by Prof. Christoph Keplinger
- Research robotic applications of soft electrohydraulic actuators(HASELs)
- Robotics, Soft robotics, Mechatronics, Electrical Engineering
MAS - Interdisciplinary Information Studies — The University of Tokyo
- Intelligent systems and Informatics Lab. led by Prof. Yasuo Kuniyoshi
- Thesis: Active bending motion of pole vault robot to improve vaulting height
- Robotics, Computer Science, Mechatronics, Mechanics
BE - Engineering — Toyota Technological Institute
- Control System Lab. led by Prof. Tatsuo Narikiyo
- Thesis: Gait stabilization of passive dynamic walker by foot shape optimization
- Control System, Mechatronics, Mechanics, Computer Science
📸 Media Exposure
5 TV shows
BBC News (UK), 3sat (Germany, Austria, Switzerland), SWR (Germany), YTN (South Korea), WKYT (USA), TNN (Thailand), KBS (South Korea)
3 Radio programs
NDR (Germany), rbb24 (Germany), Radio Eins (Germany)
4 Magazines
National Geographic Deutschland, Wirtschafts Woche, Stuttgarter Maschinenbau, Max Planck Society Year book
200+ News articles in 12+ languages
REUTERS, AFP, heise, Computer Bild, EL Economista, The National Tribune, THE HINDU, etc.
🏆 Awards and Honers
Research highlights 2024
Max Planck Society (selected 12 papers out of 15,000+ publications)
Editors’ Highlights
nature communications, 2024
Video Friday Selection
IEEE Spectrum, 2024
Young Investigation Excellence Award
The Robotics Society of Japan, 2014
Scholarship for Students with Outstanding Achievements
Japan Student Services Organization (JASSO), 2014
Student travel grant
6th International Symposium on Adaptive Motion of Animals and Machines (AMAM), 2013
Presentation award
The 13th SICE System Integration Division Annual Conference (SICE SI), 2012