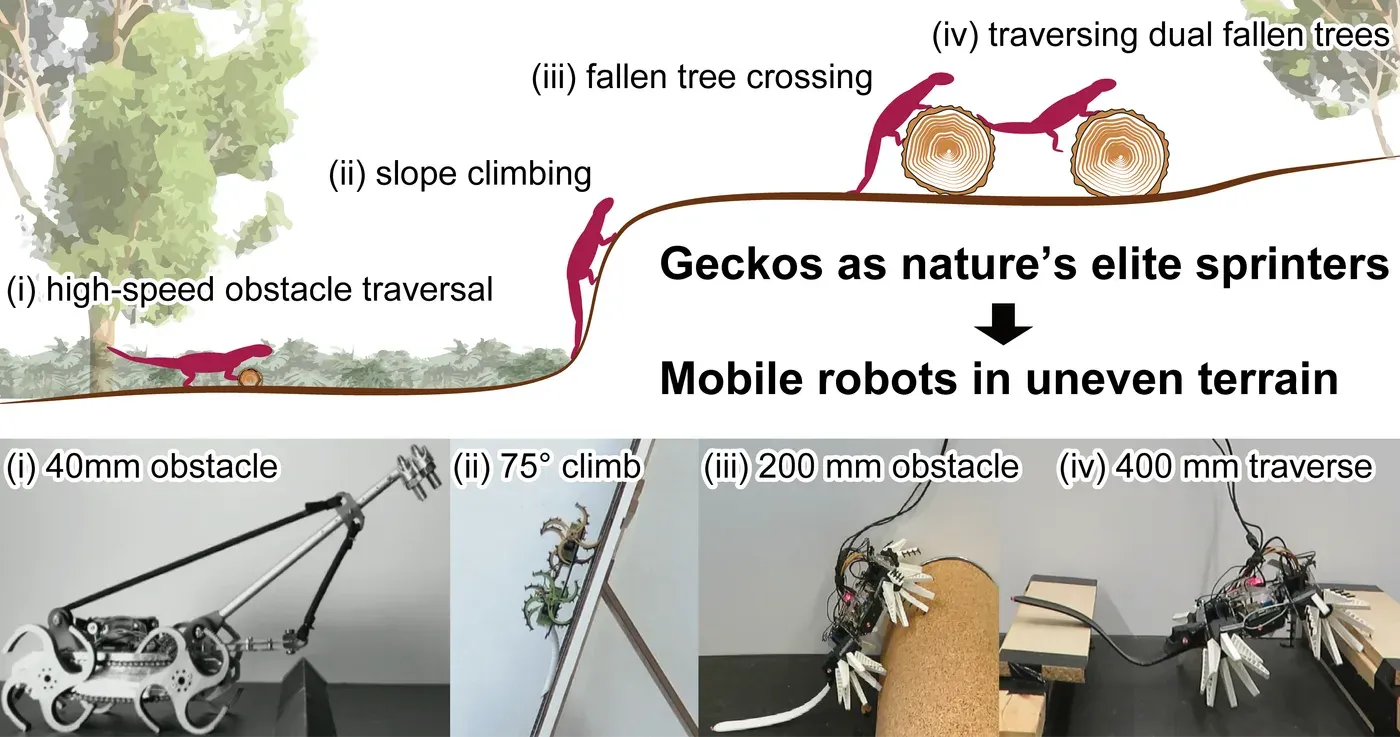
Compliance, mass distribution and contact forces in cursorial and scansorial locomotion with biorobotic physical modelsGeckos, as nature's elite sprinters, inspire mobile robots on uneven terrain.