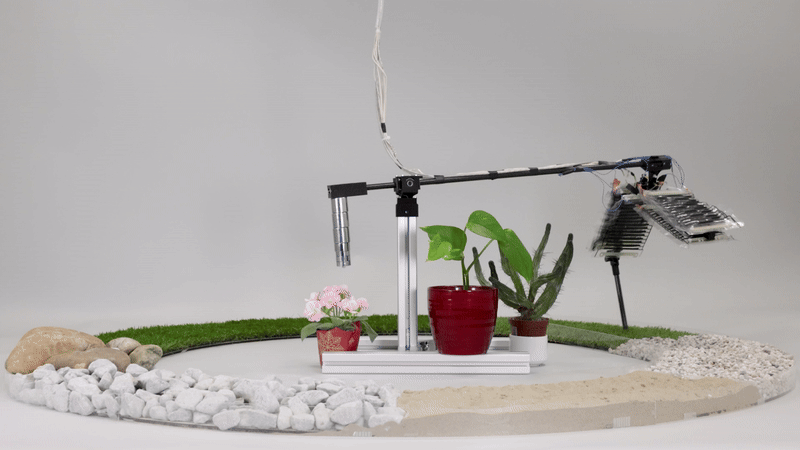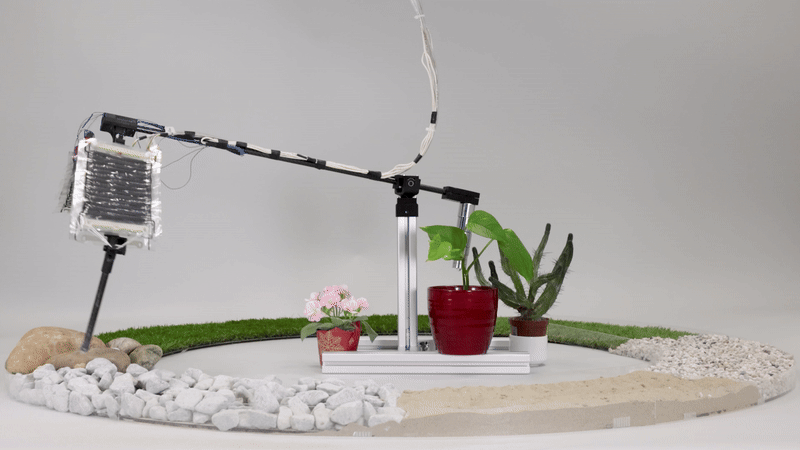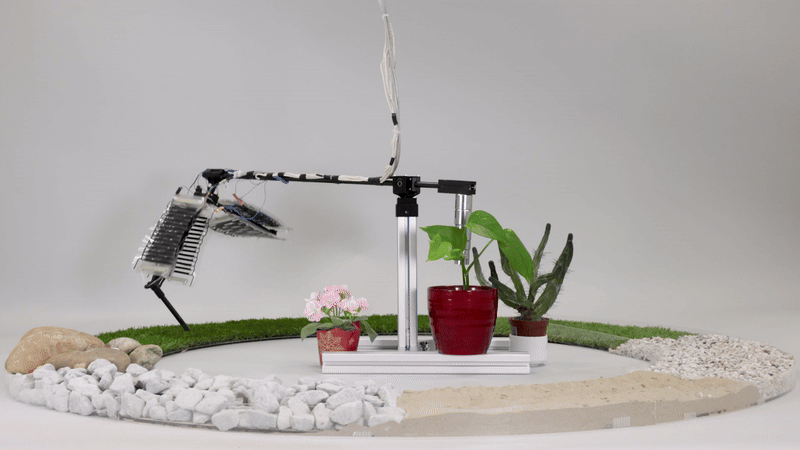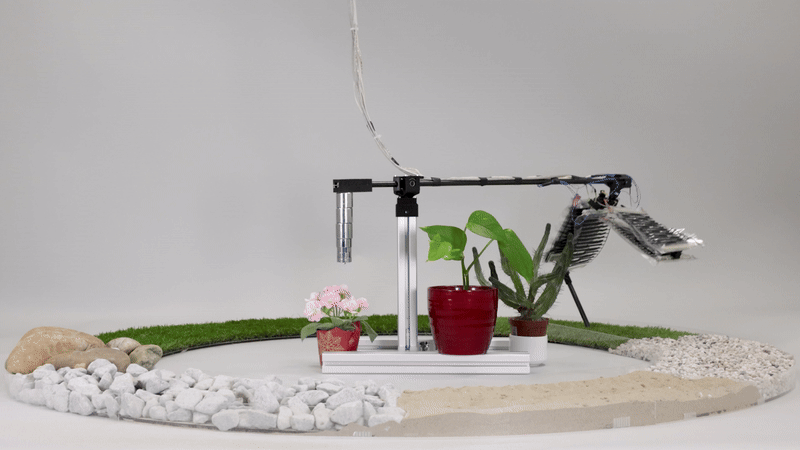
Electrohydraulic musculoskeletal robotic leg for agile, adaptive, yet energy-efficient locomotion
Soft electrohydraulic artificial muscles enable robotic legs for agile, adaptive, yet energy-efficient locomotion.

tag
Soft electrohydraulic artificial muscles enable robotic legs for agile, adaptive, yet energy-efficient locomotion.
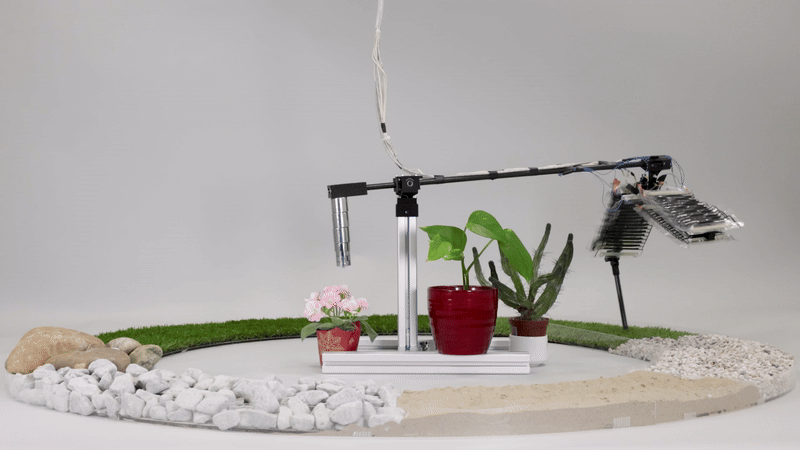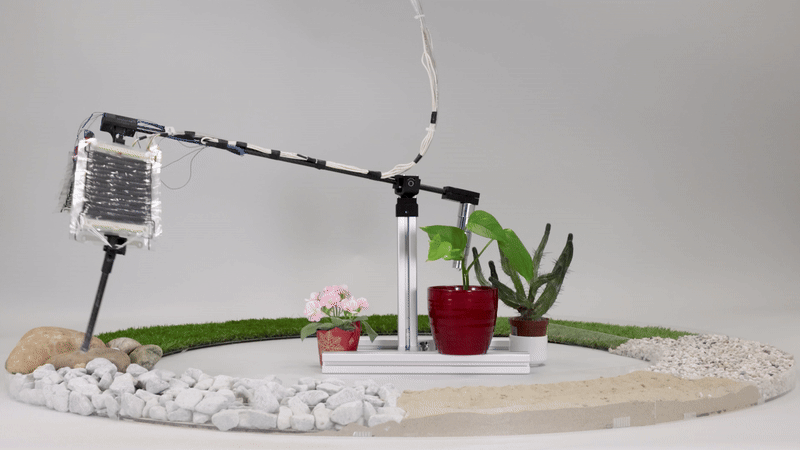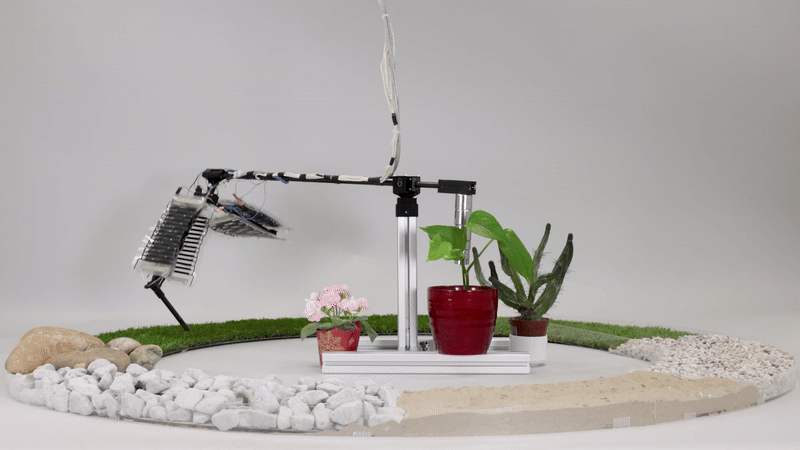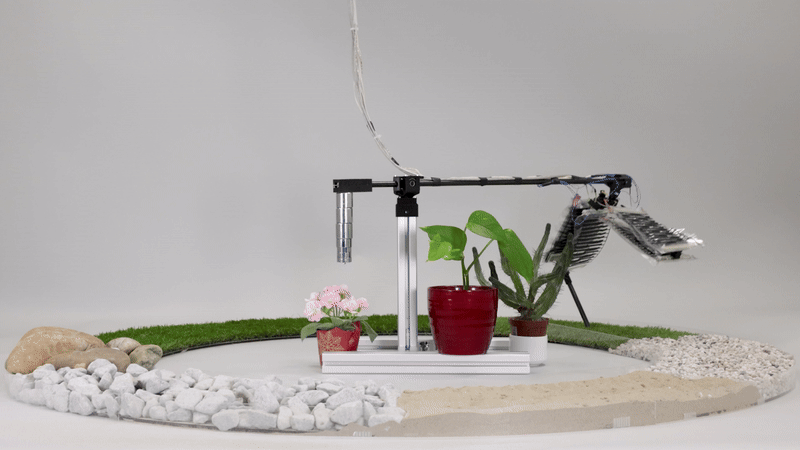
A robotic leg powered by electrohydraulic artificial muscles achieves agile, adaptive, yet energy-efficient locomotion.
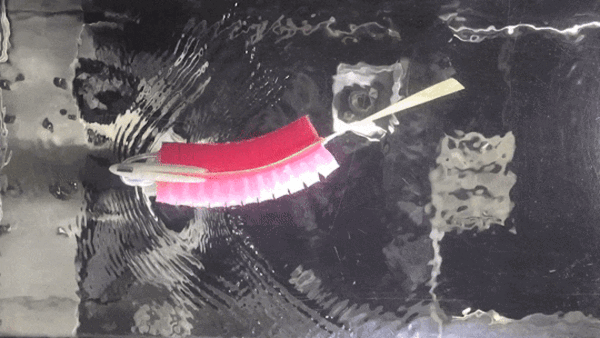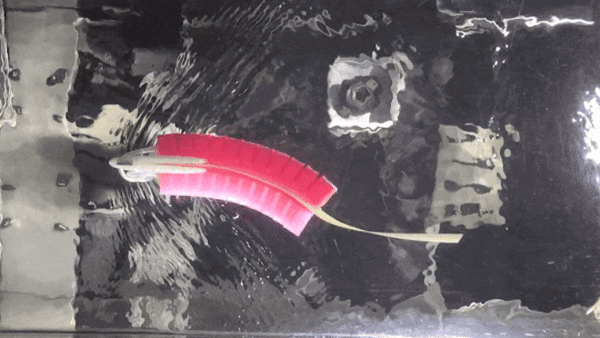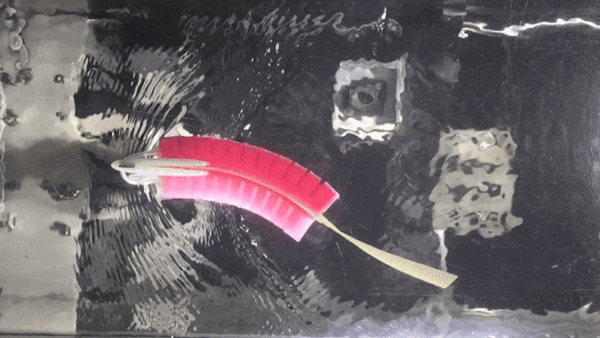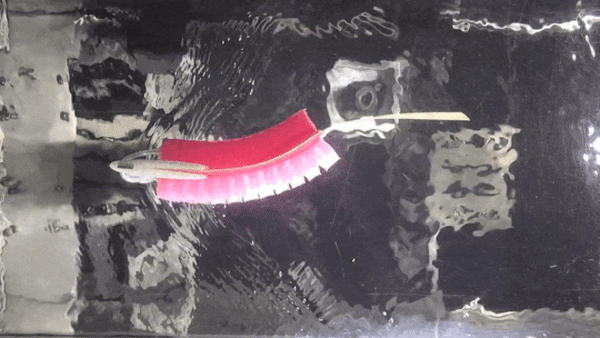
A fish robot as a robotic animal for understanding the biology of muscle activity for swimming locomotion
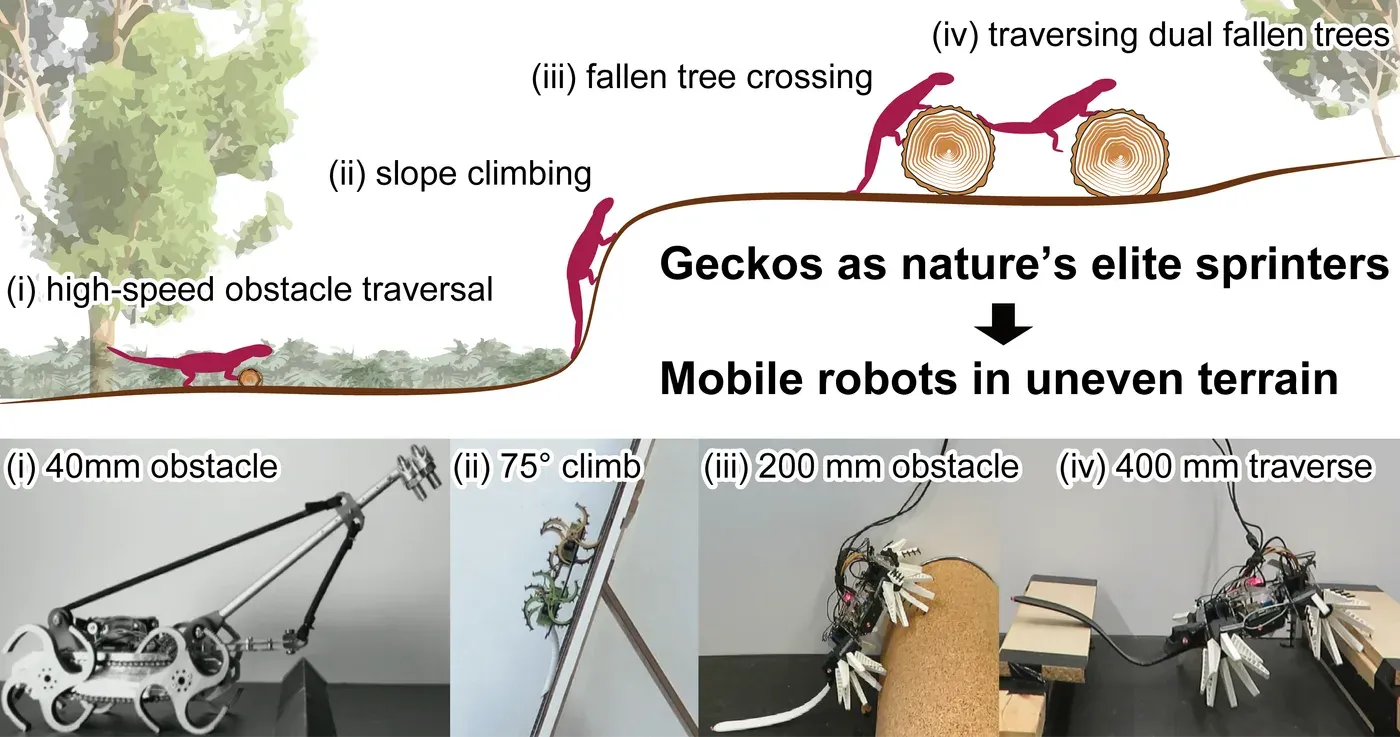
Geckos, as nature's elite sprinters, inspire mobile robots on uneven terrain.
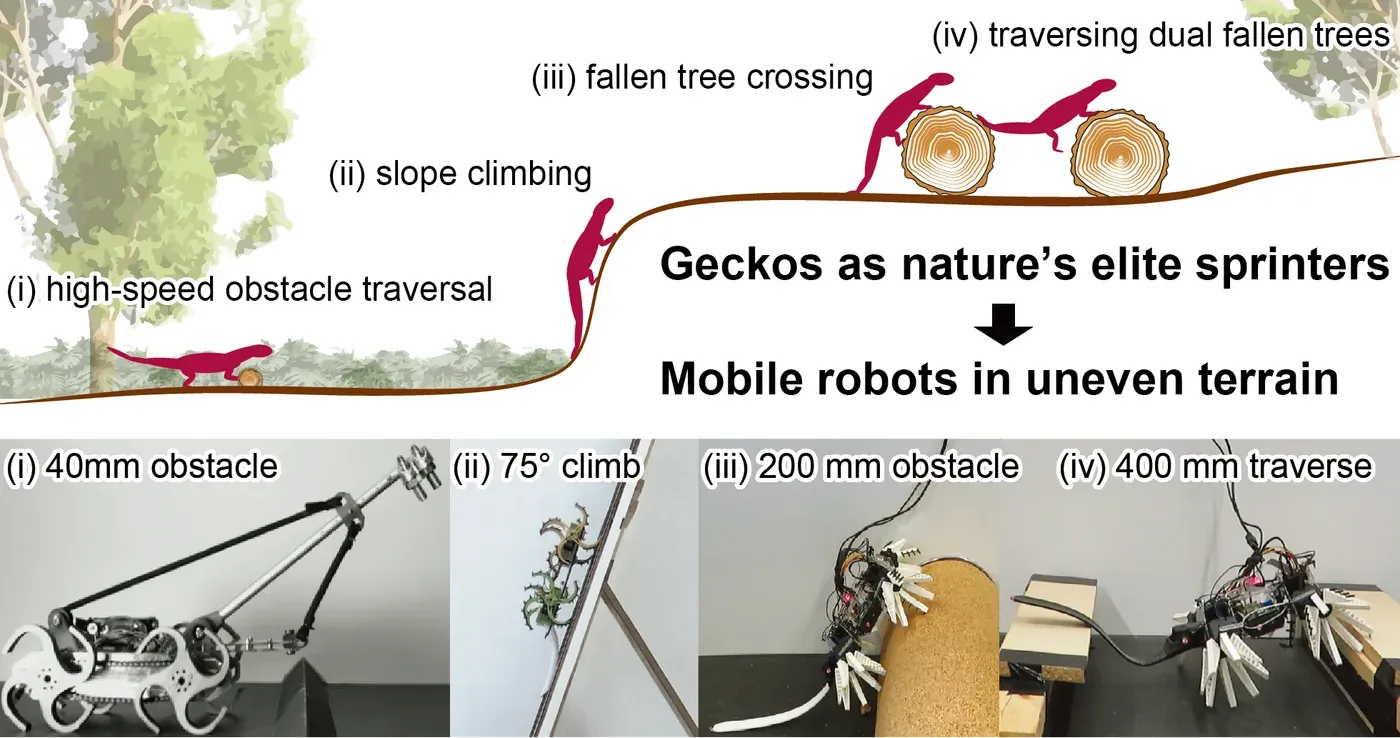
Geckos robots inspired from a nature's elite sprinter.
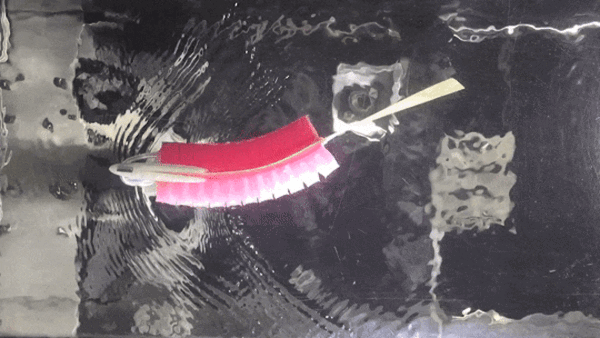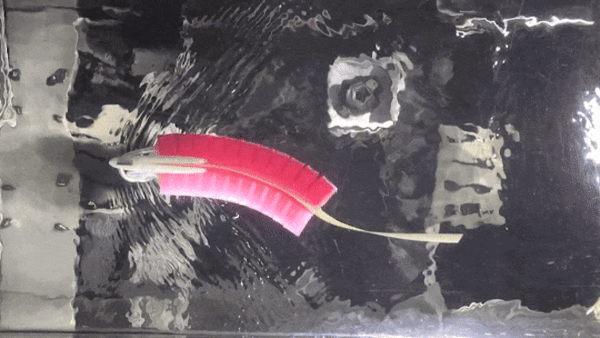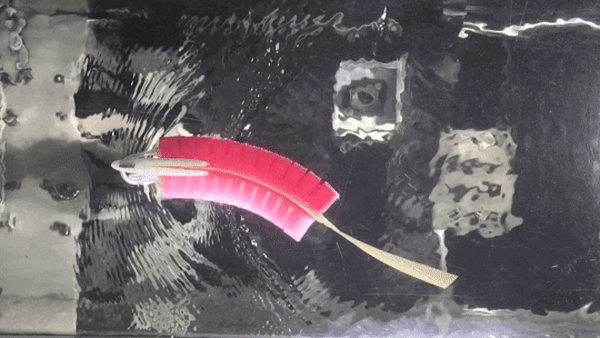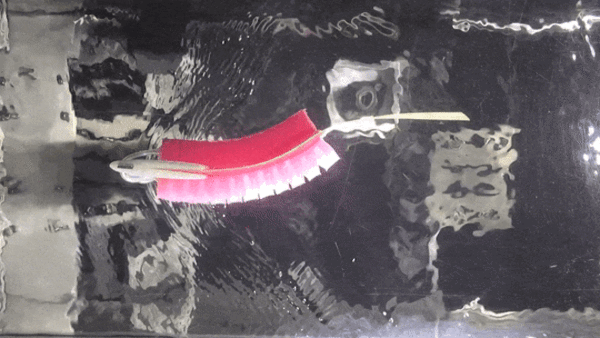
Soft robotic fish: real-time tail-beat control using eGaIn strain sensing and a lightweight-data-driven model.
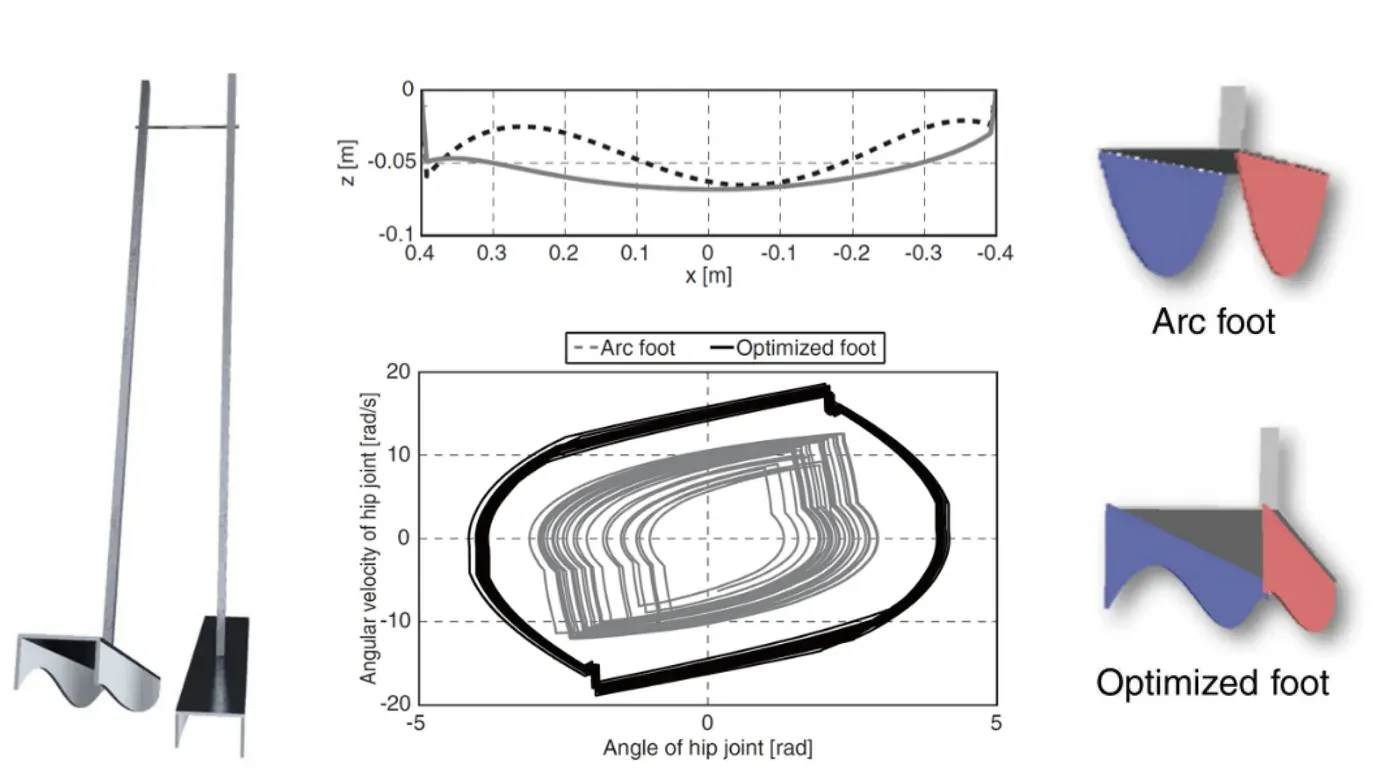
Optimized feet shape of the passive dynamic walker enhance its walking robustness in slope angles.
Optimizing foot shape of a passive dynamic walker enables robust walking against changes in slope inclination.