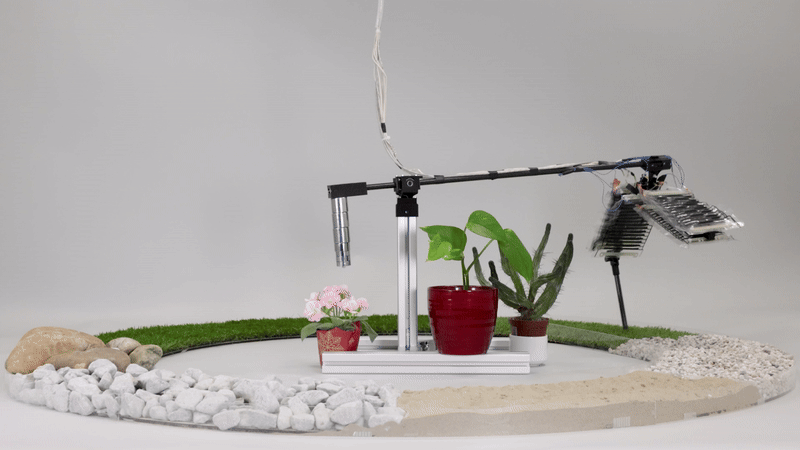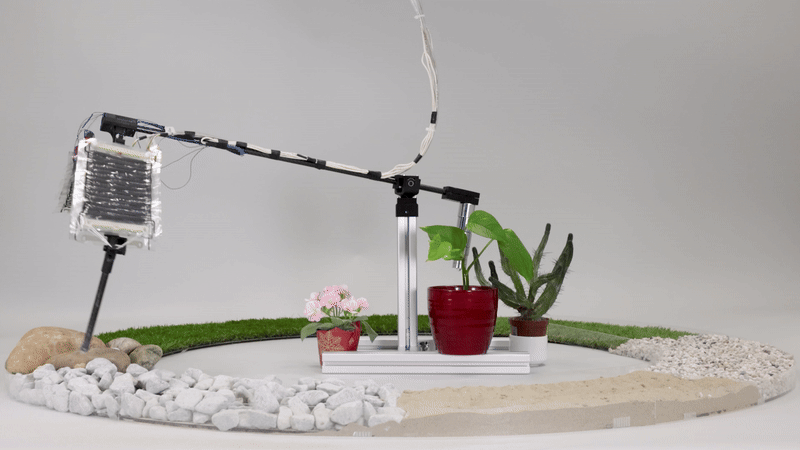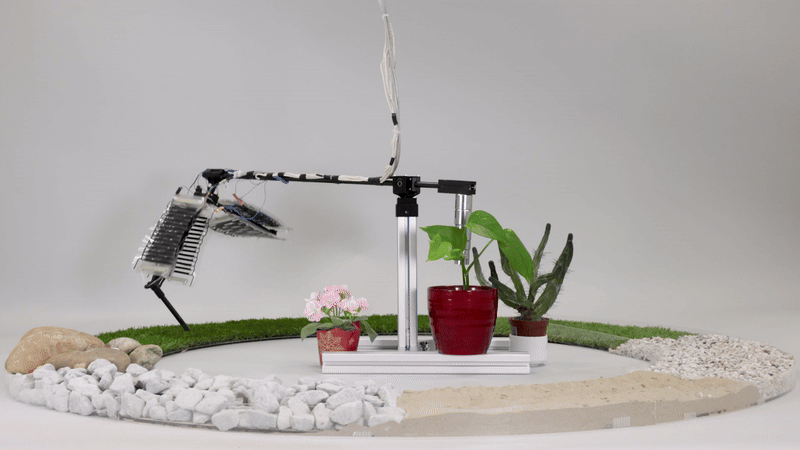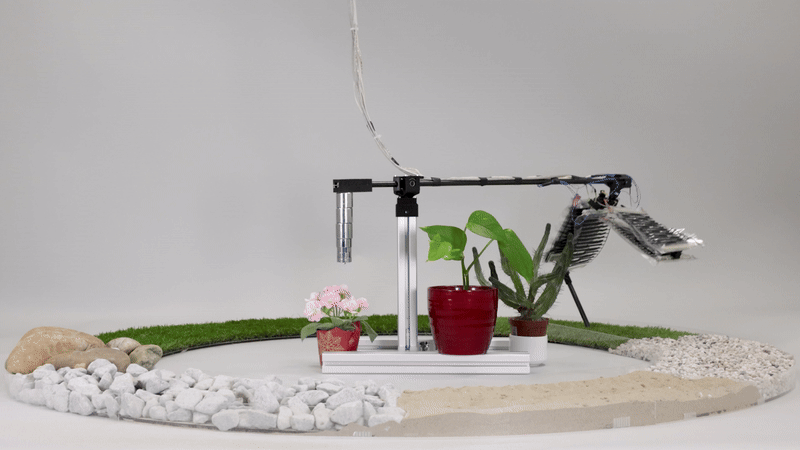
Electrohydraulic musculoskeletal robotic leg for agile, adaptive, yet energy-efficient locomotion
Soft electrohydraulic artificial muscles enable robotic legs for agile, adaptive, yet energy-efficient locomotion.

tag
Soft electrohydraulic artificial muscles enable robotic legs for agile, adaptive, yet energy-efficient locomotion.
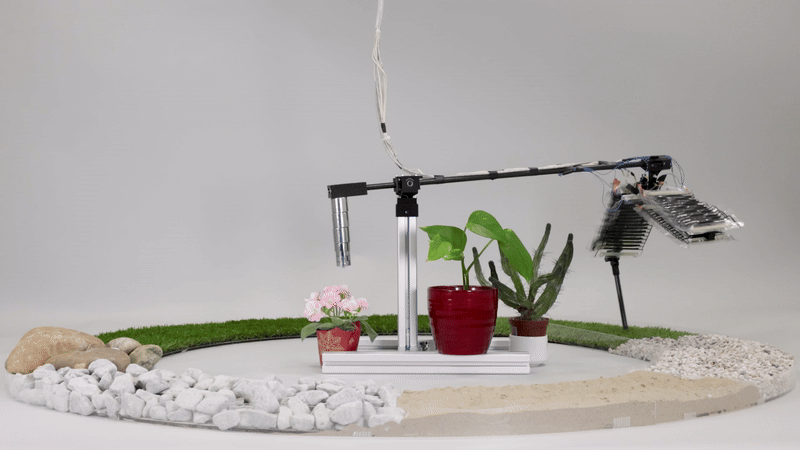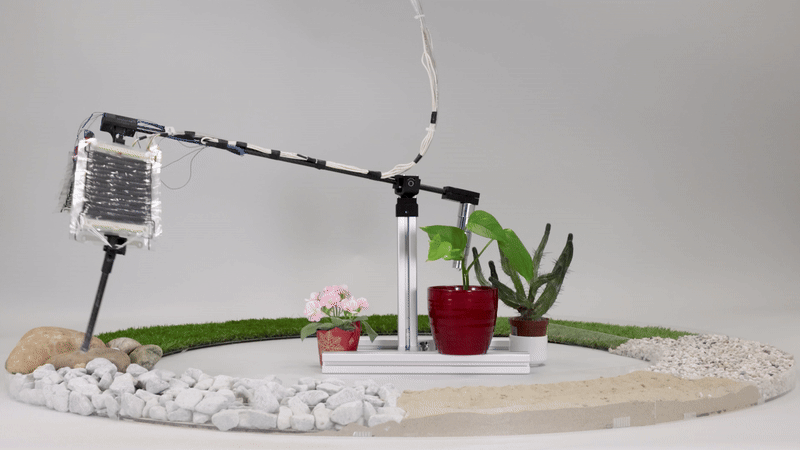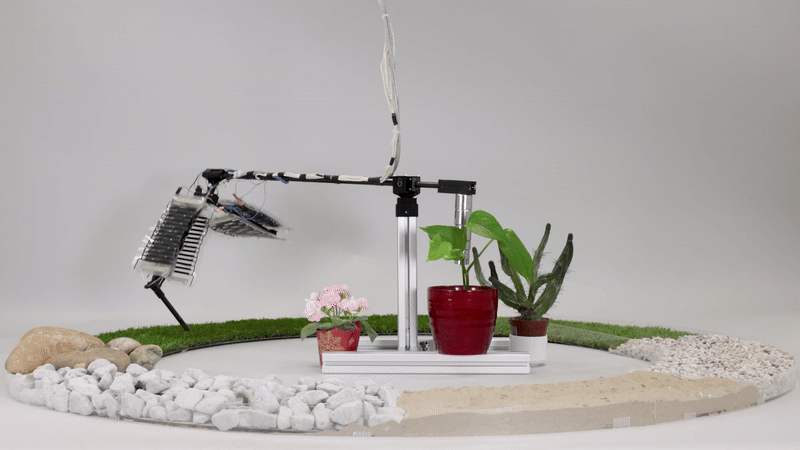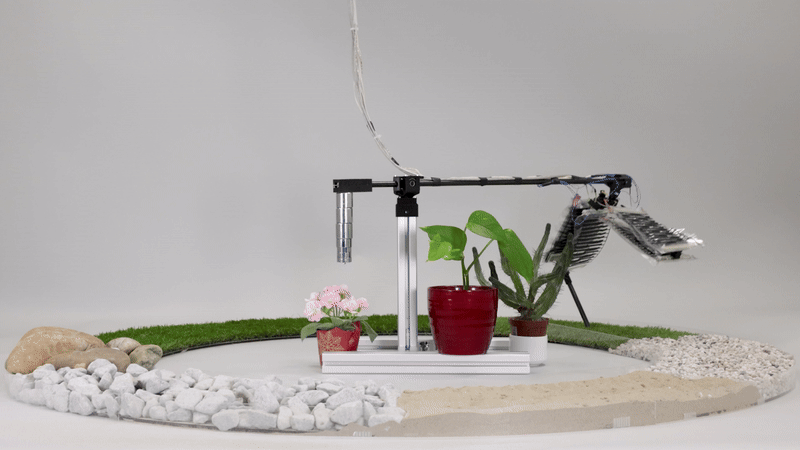
A robotic leg powered by electrohydraulic artificial muscles achieves agile, adaptive, yet energy-efficient locomotion.
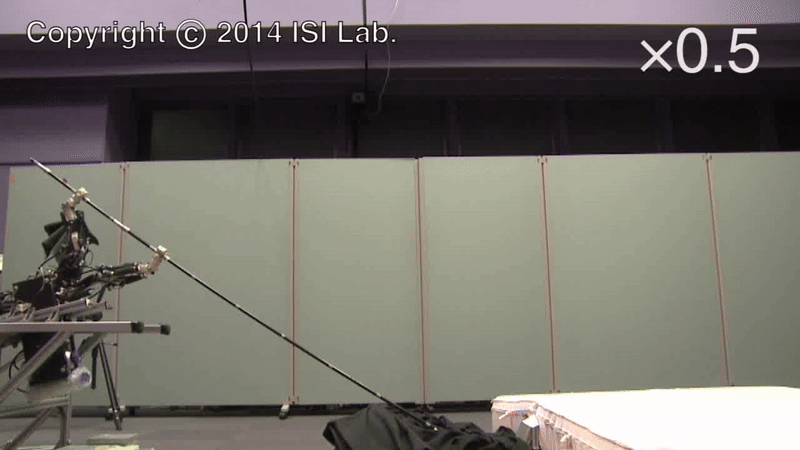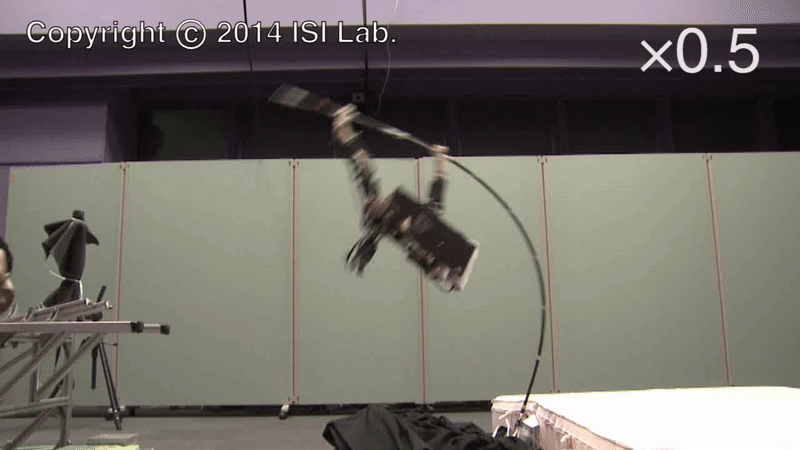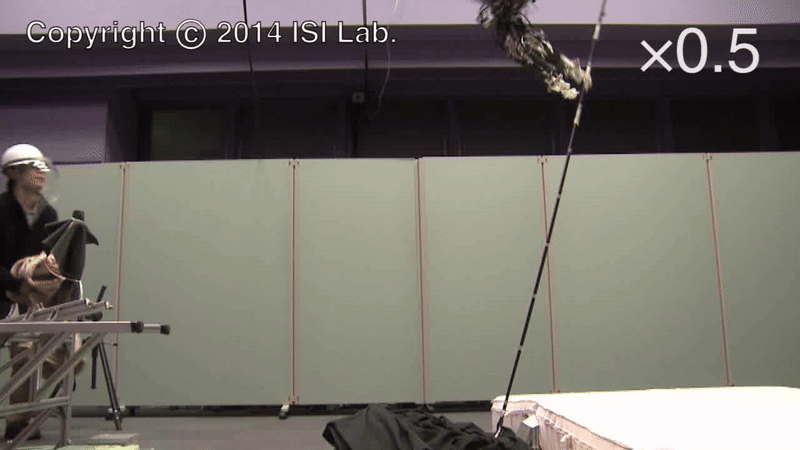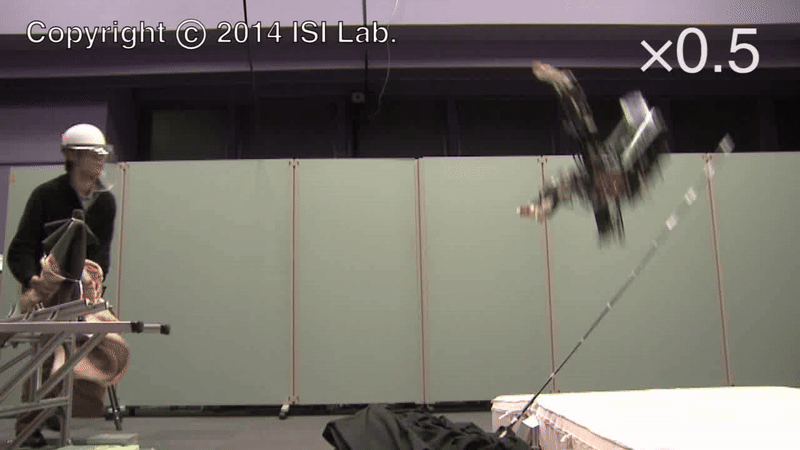
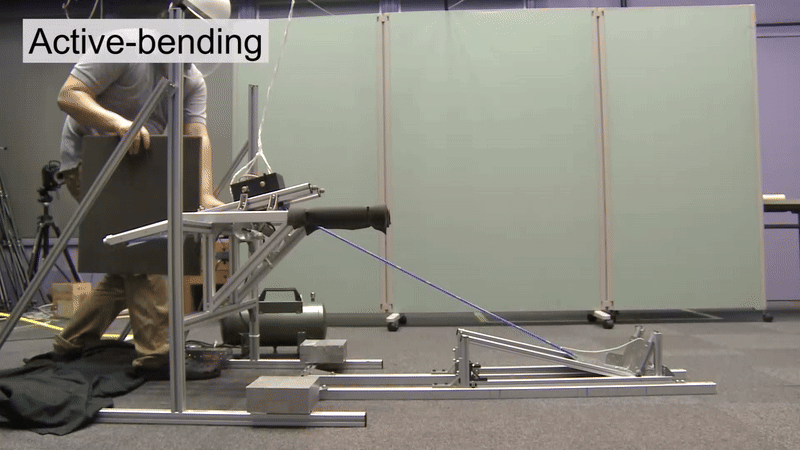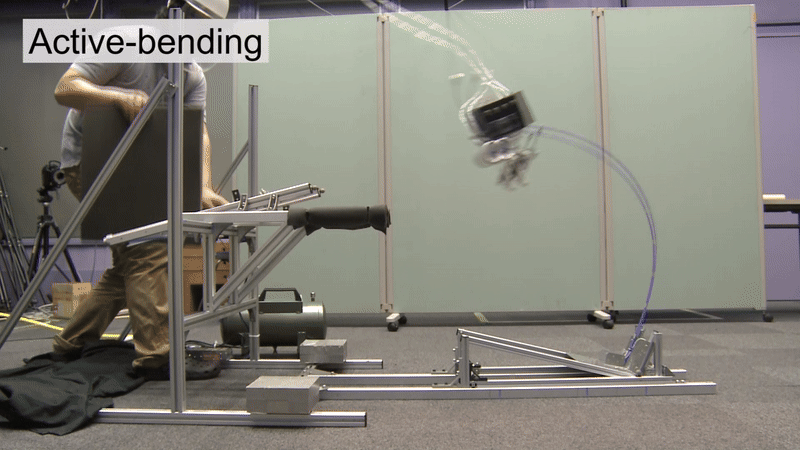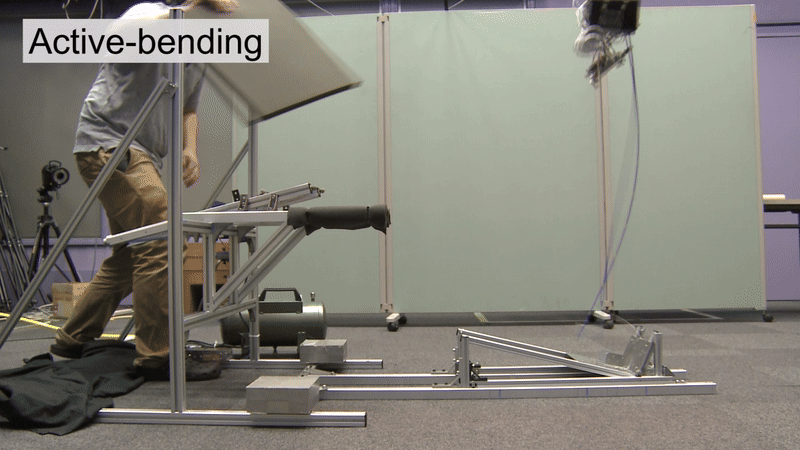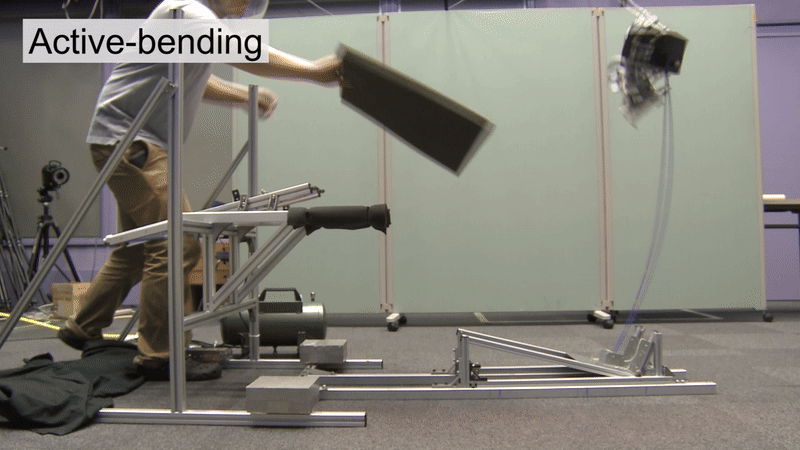
A dual hand robot achieves pole vaulting to jump 1.67m.
Sports Biomechanics from the Perspective of Robotics
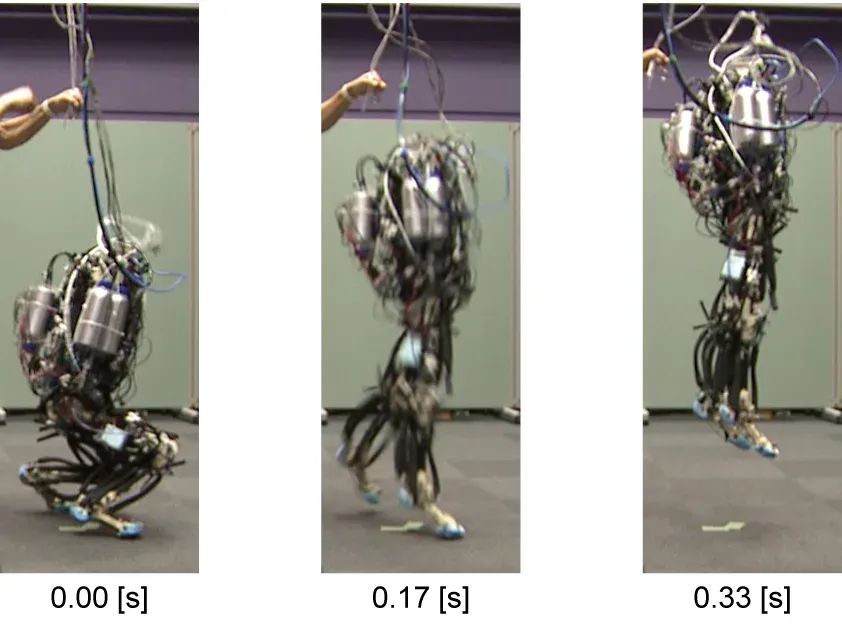
Angle-dependent moment arm (ADMA) extends the range of possible jumping postures for musculoskeletal robots.
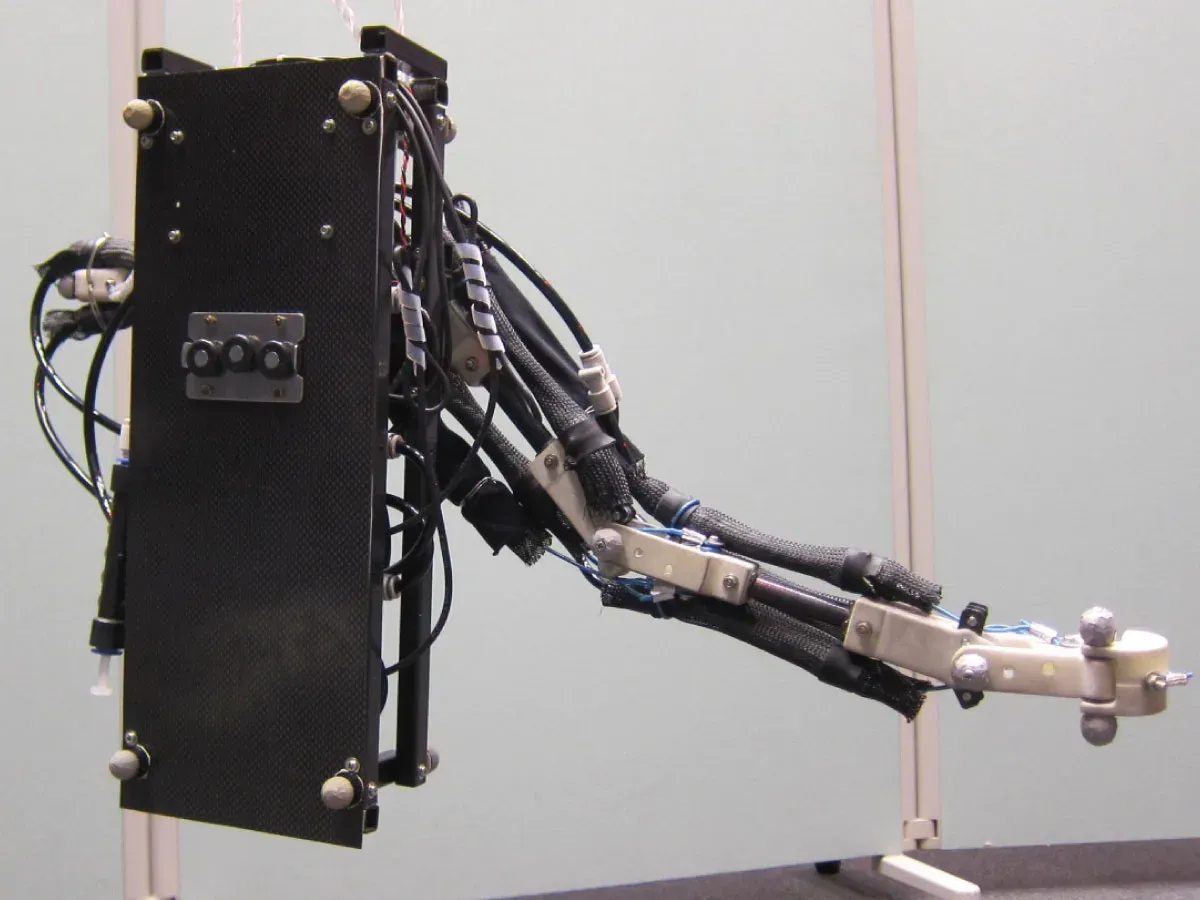
The swing-up motion in pole vaulting inertially generates bending moment on the pole.