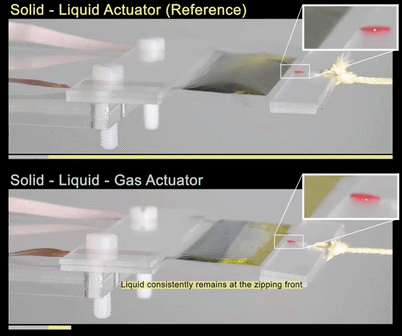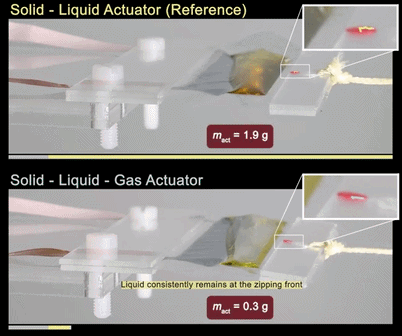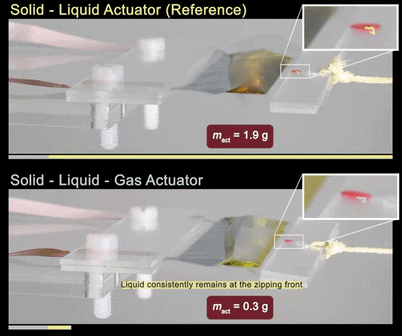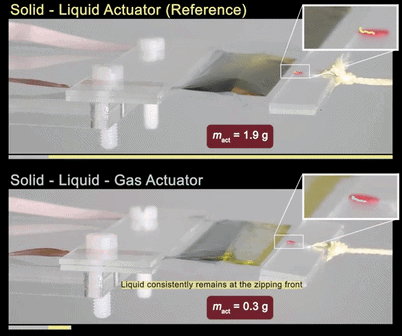
Ultralight soft electrostatic actuators based on solid-liquid-gas architectures
The introduction of the third phase, gaseous dielectrics, into solid-liquid actuators allows for the creation of ultralight soft electrostatic actuators.

tag
The introduction of the third phase, gaseous dielectrics, into solid-liquid actuators allows for the creation of ultralight soft electrostatic actuators.
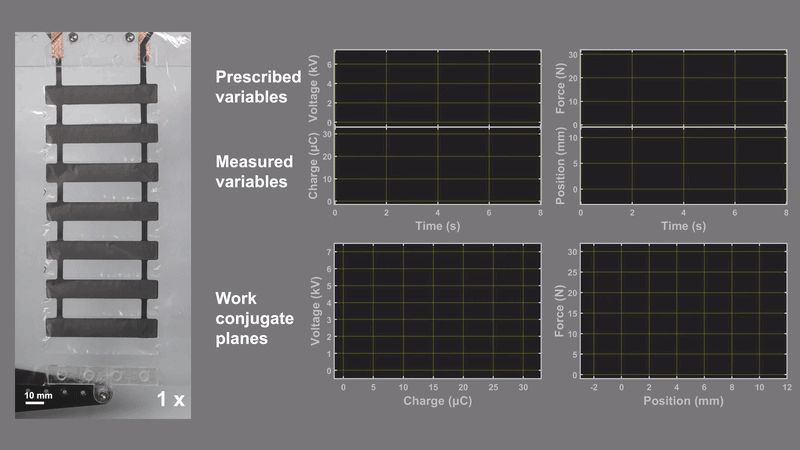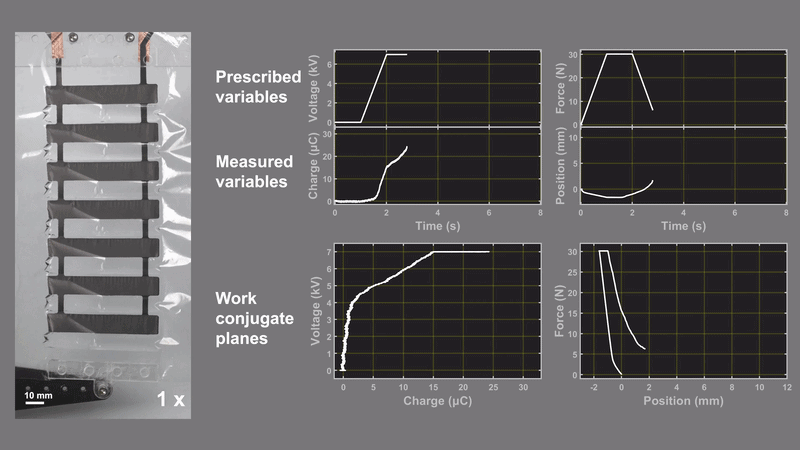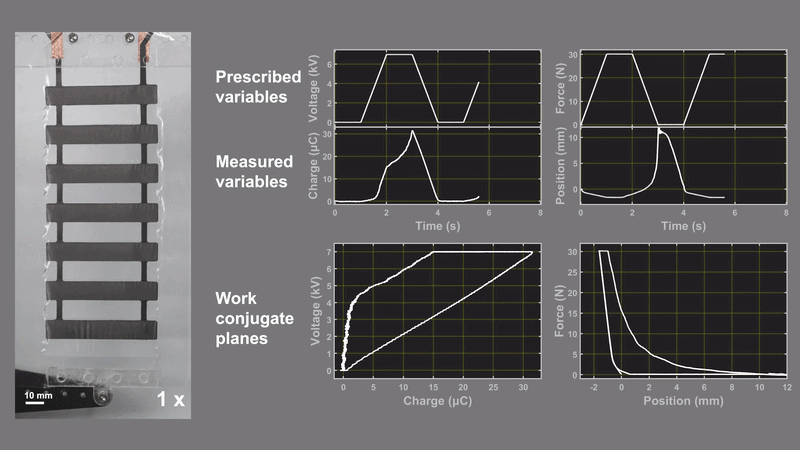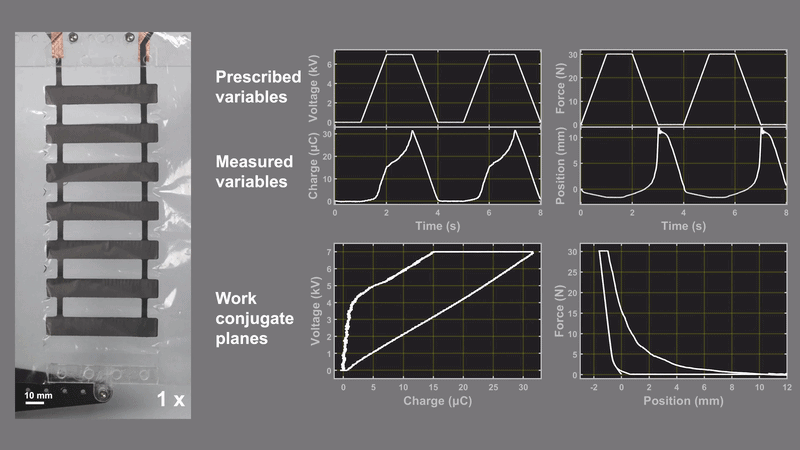
Closed cycles on the work conjugate planes enables study and enhance energy efficiency of soft electrostatic actuators.
Soft electrohydraulic artificial muscles enable robotic legs for agile, adaptive, yet energy-efficient locomotion.
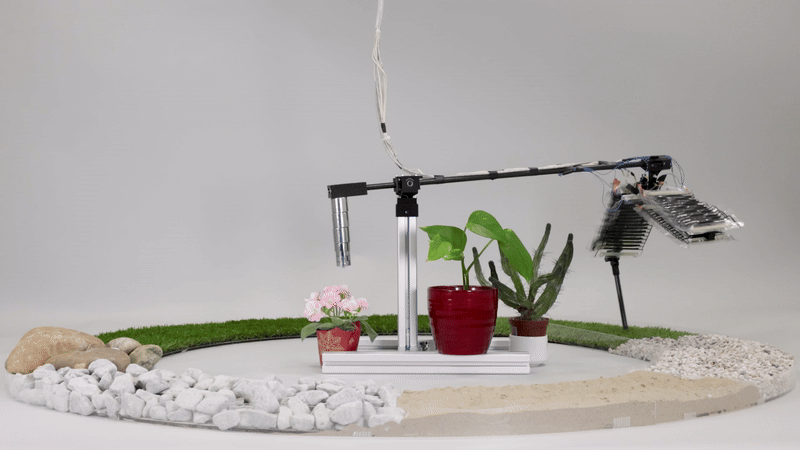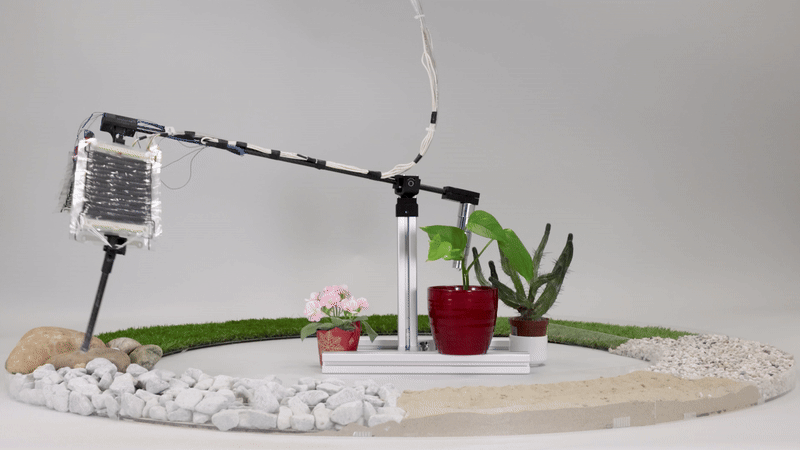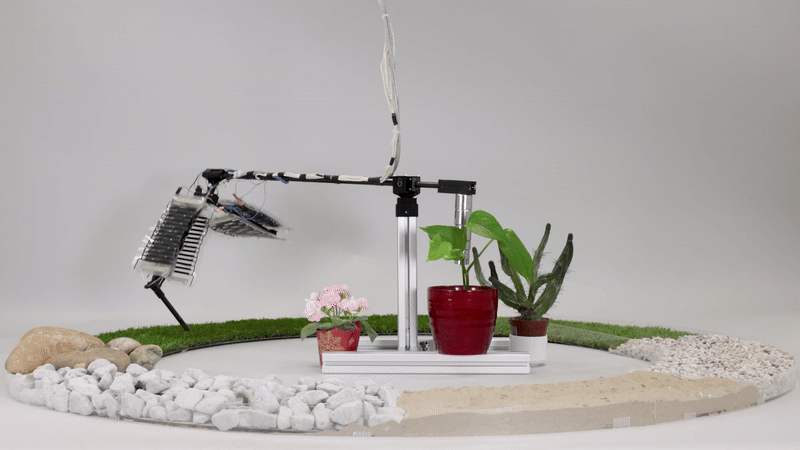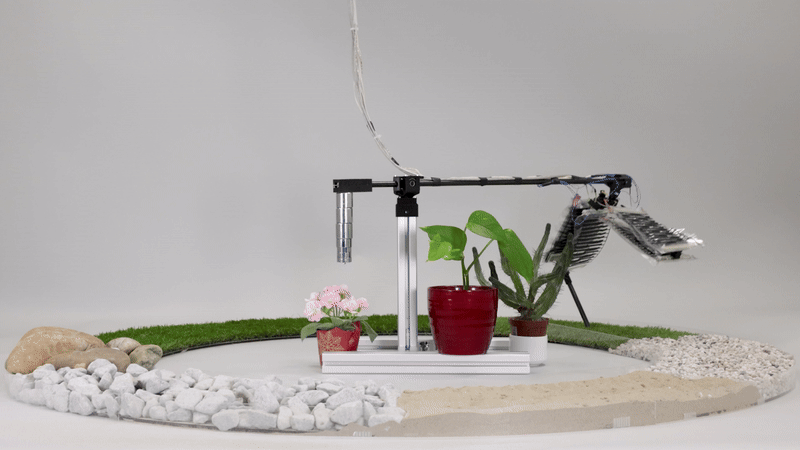
A robotic leg powered by electrohydraulic artificial muscles achieves agile, adaptive, yet energy-efficient locomotion.
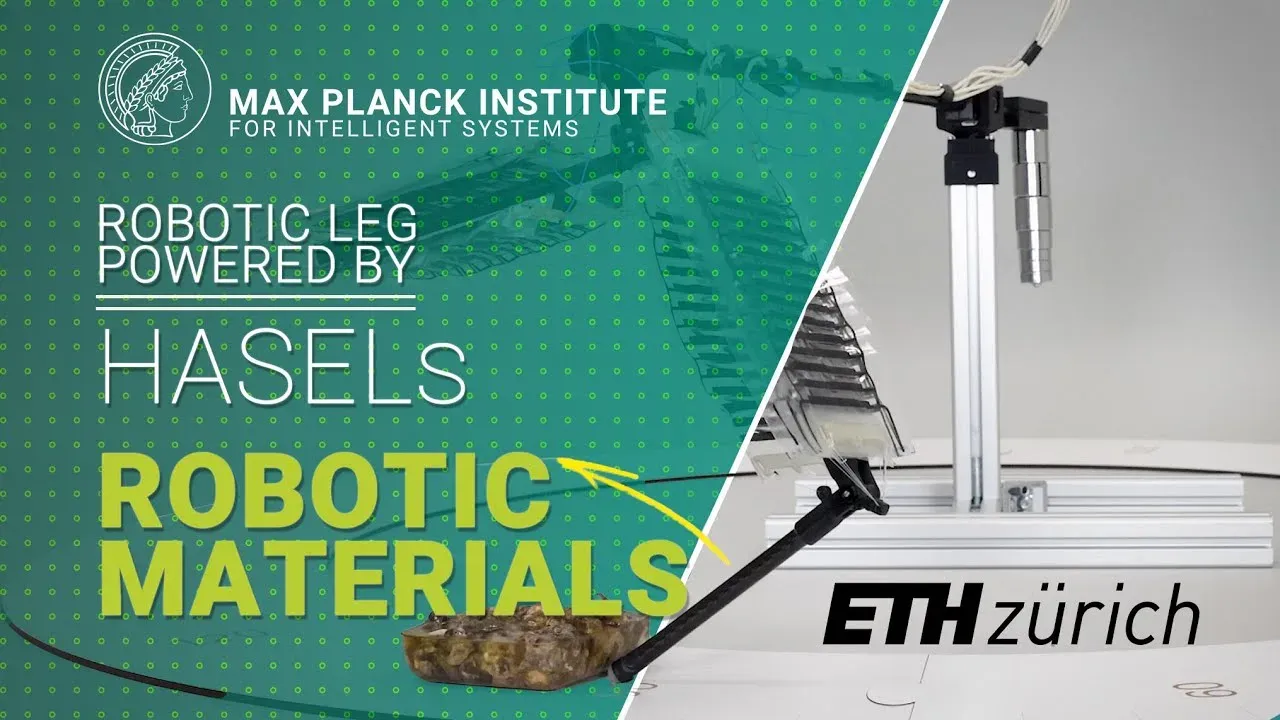
An electrohydraulic musculoskeletal robotic leg for agile, adaptive, yet energy-efficient locomotion.
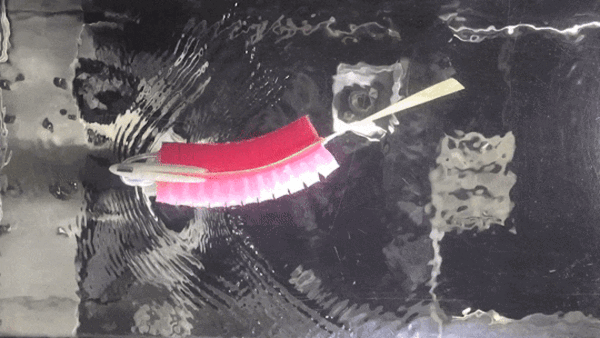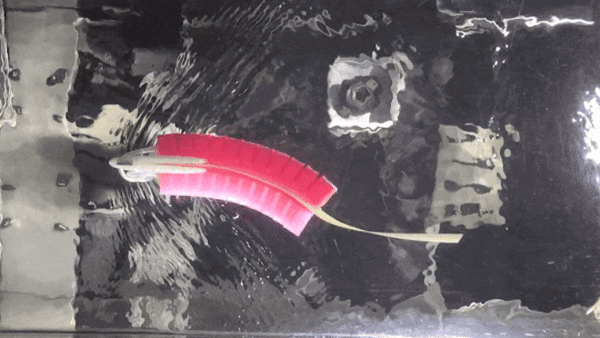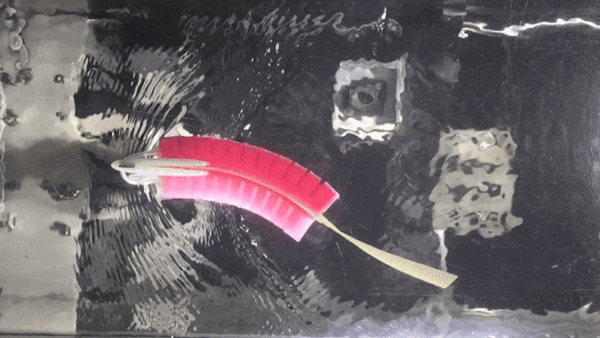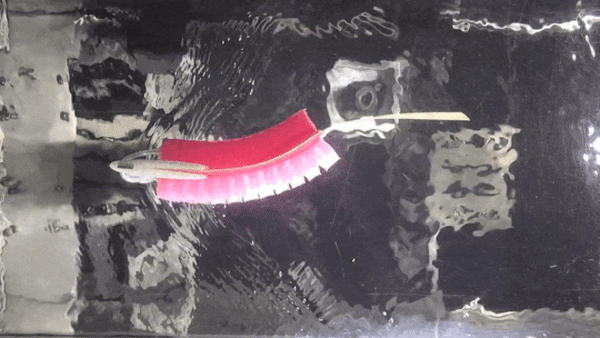
A fish robot as a robotic animal for understanding the biology of muscle activity for swimming locomotion
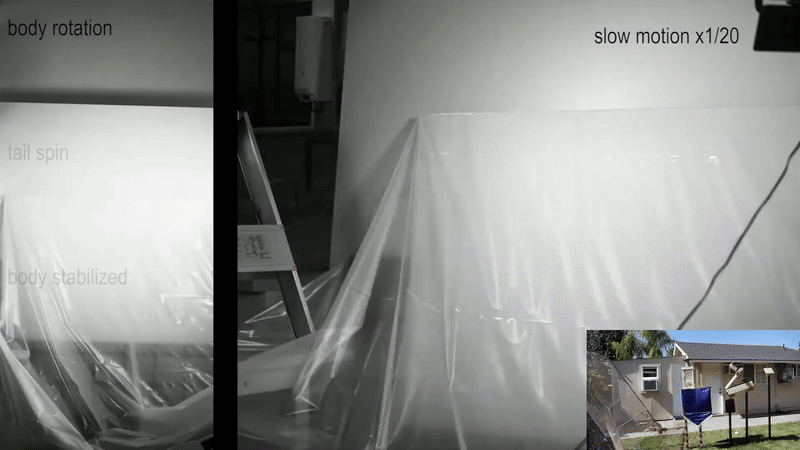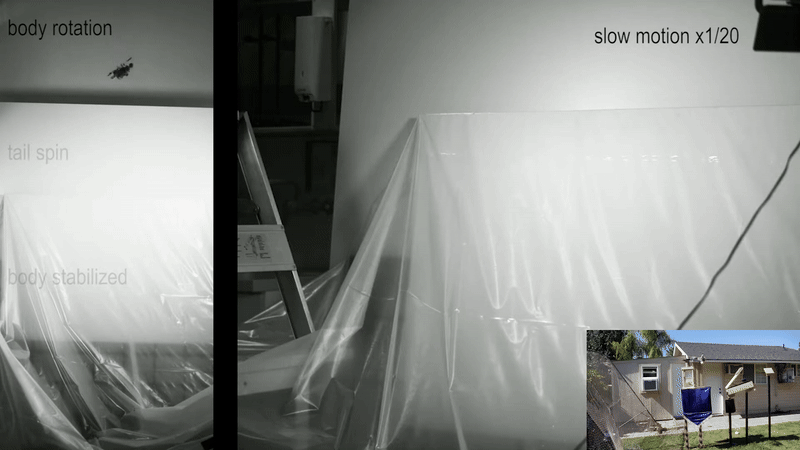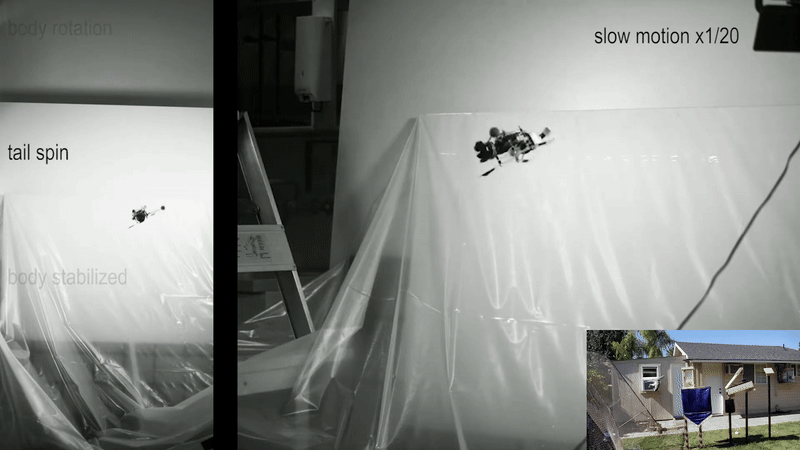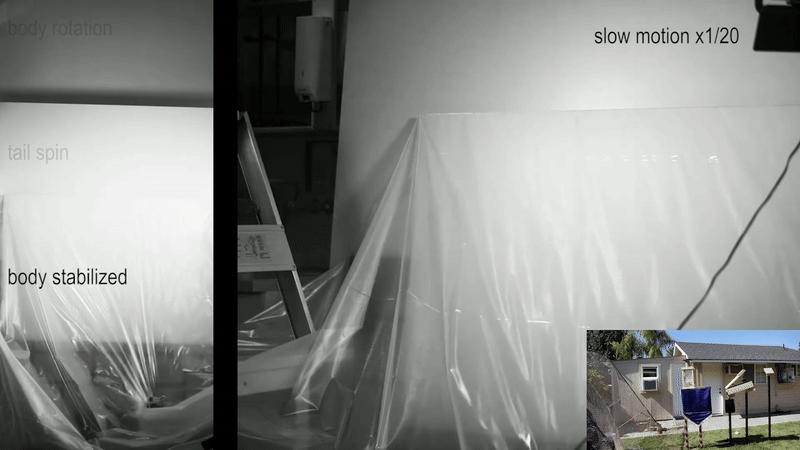
Squirrel’s very light tail (just 3% of body mass) can inertially stabilize their body from unexpected falls.
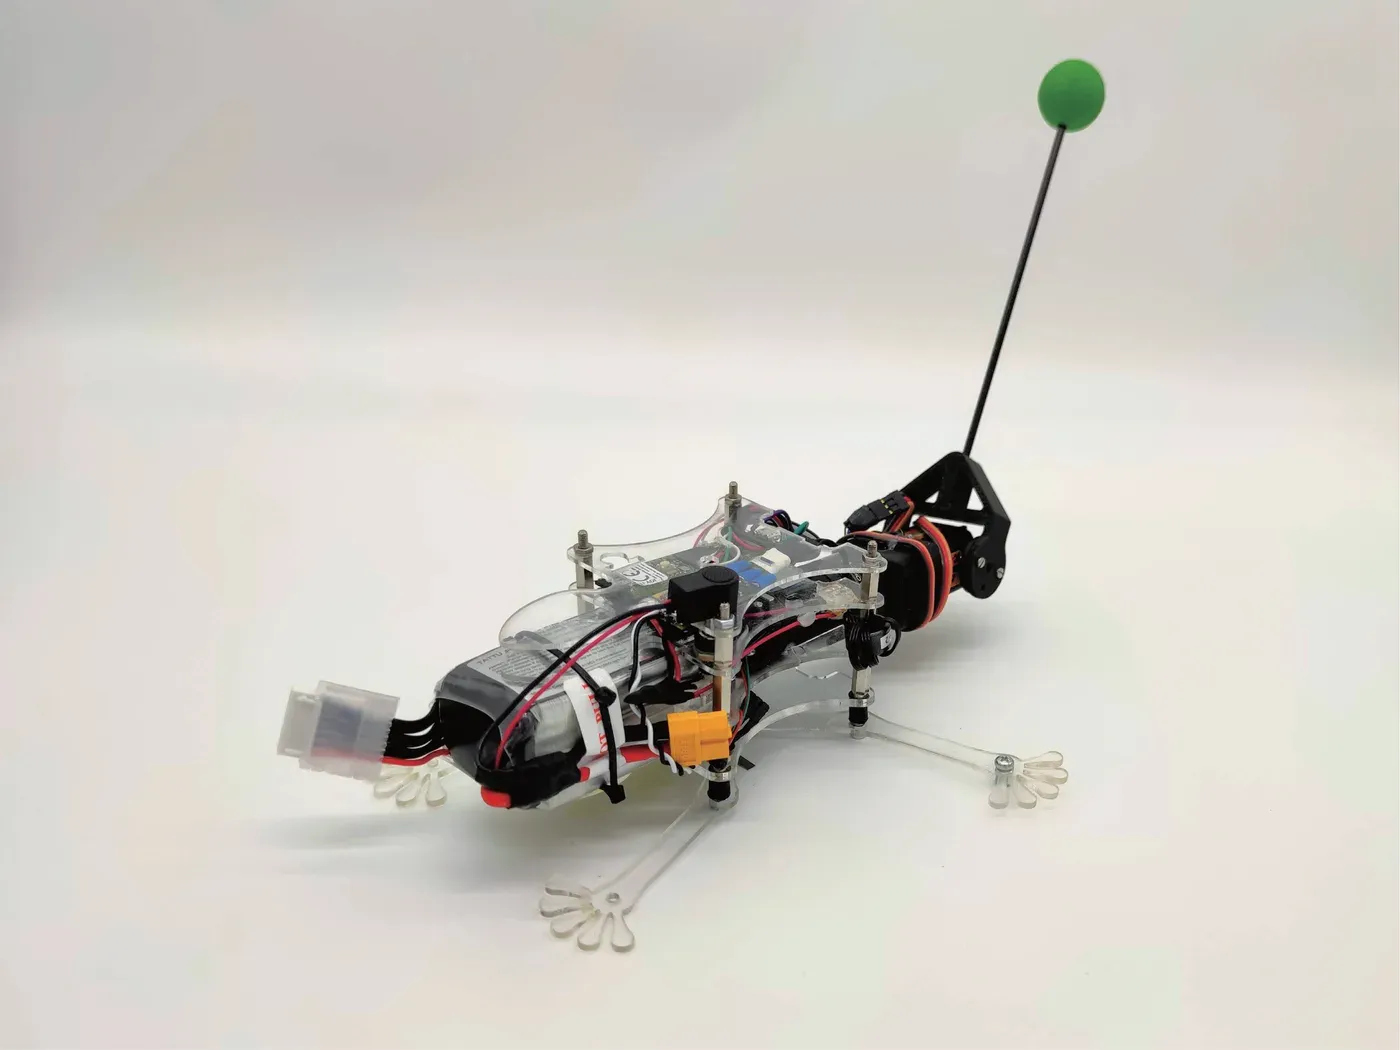
A squirrel robot for studying squirrel's aerial righting ability.
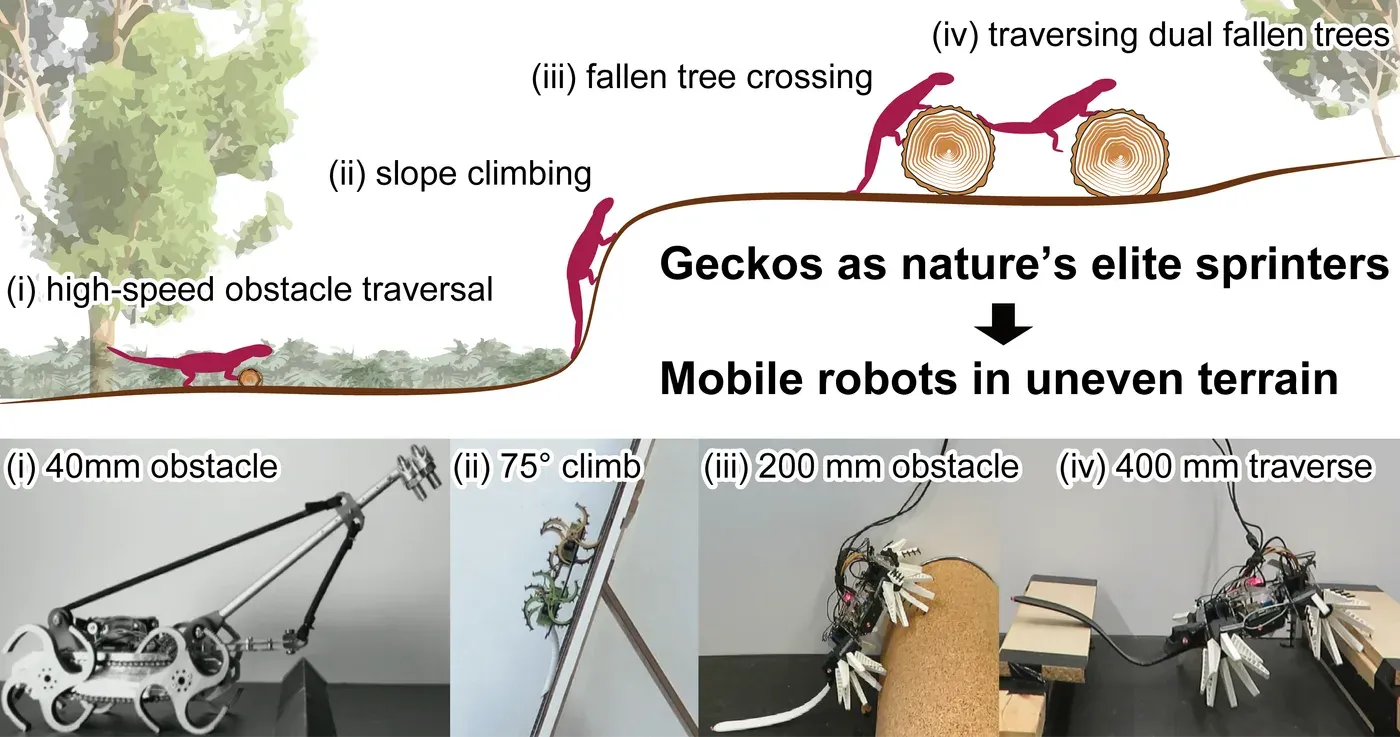
Geckos, as nature's elite sprinters, inspire mobile robots on uneven terrain.
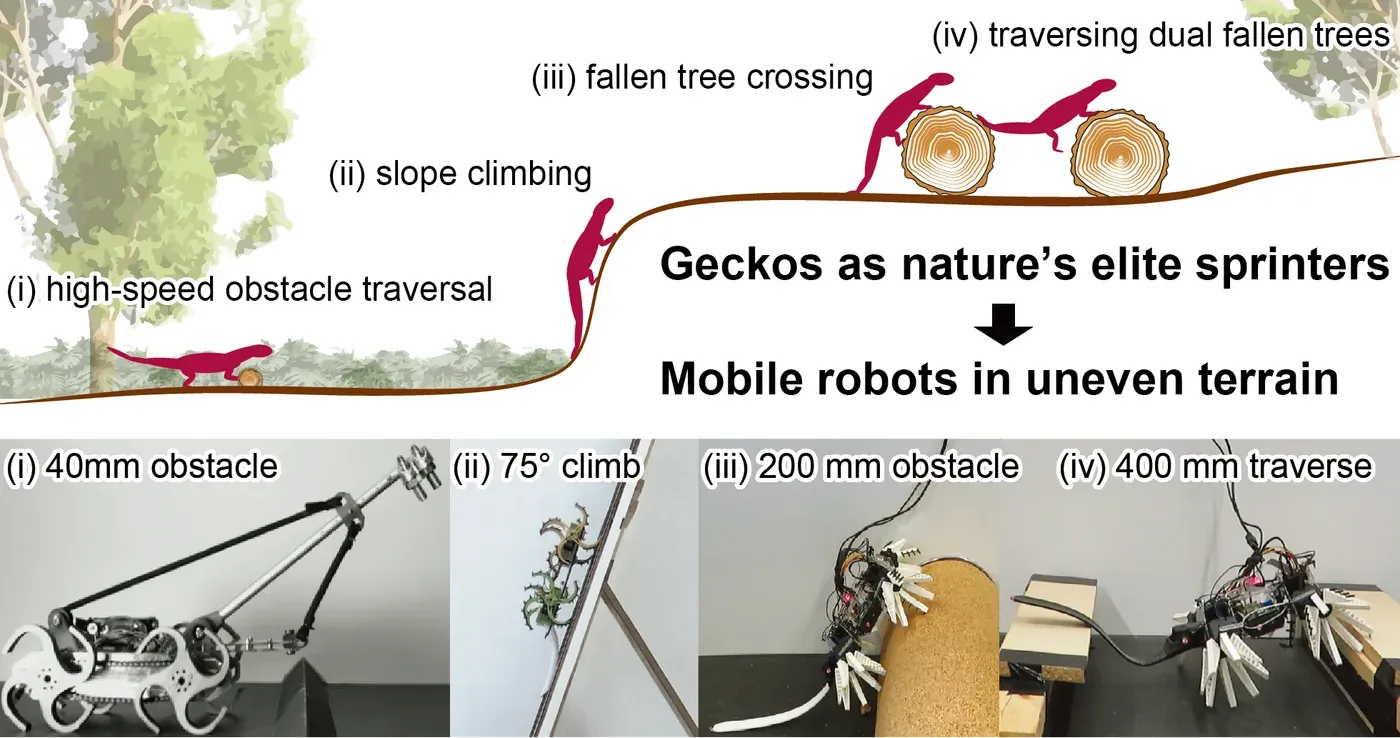
Geckos robots inspired from a nature's elite sprinter.
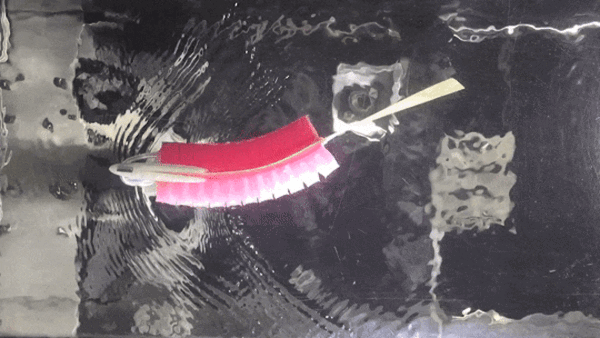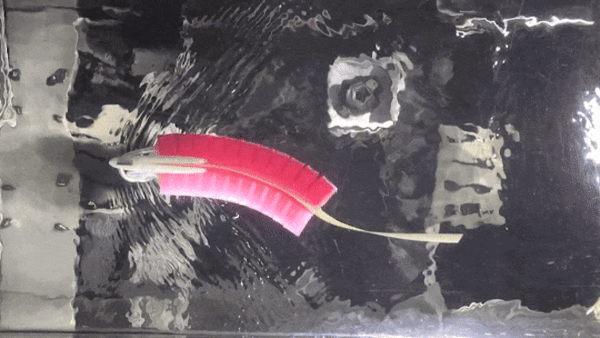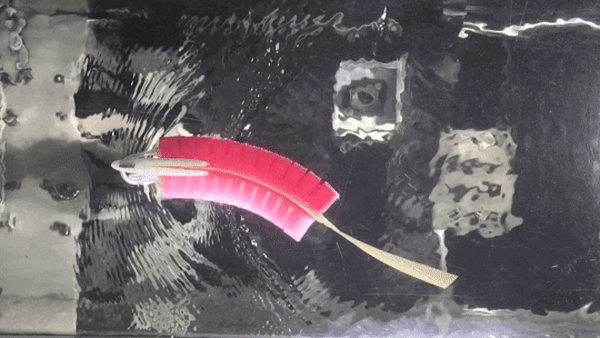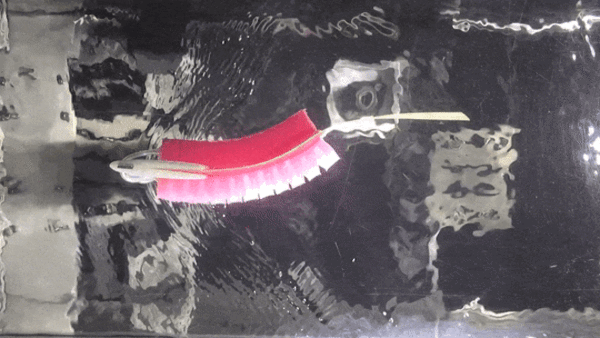
Soft robotic fish: real-time tail-beat control using eGaIn strain sensing and a lightweight-data-driven model.
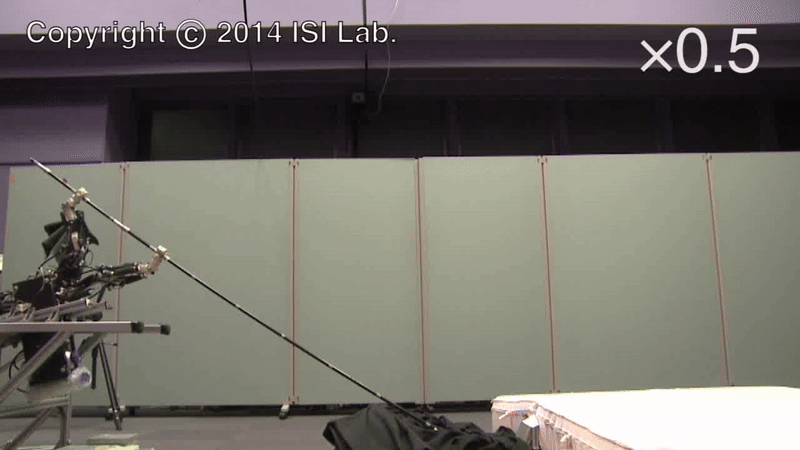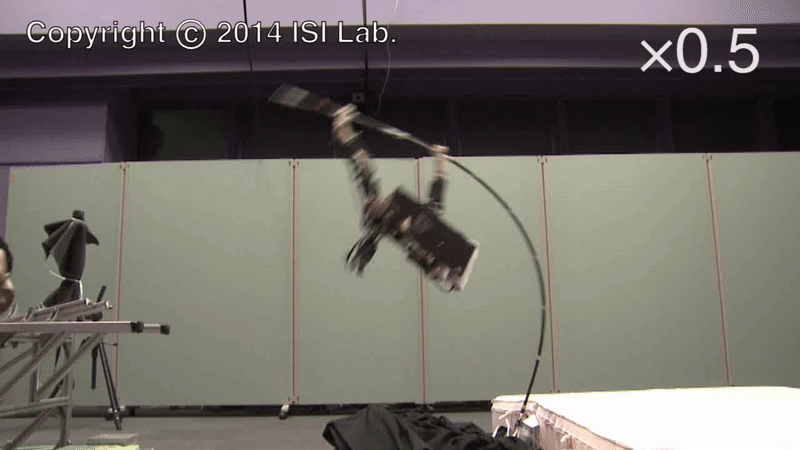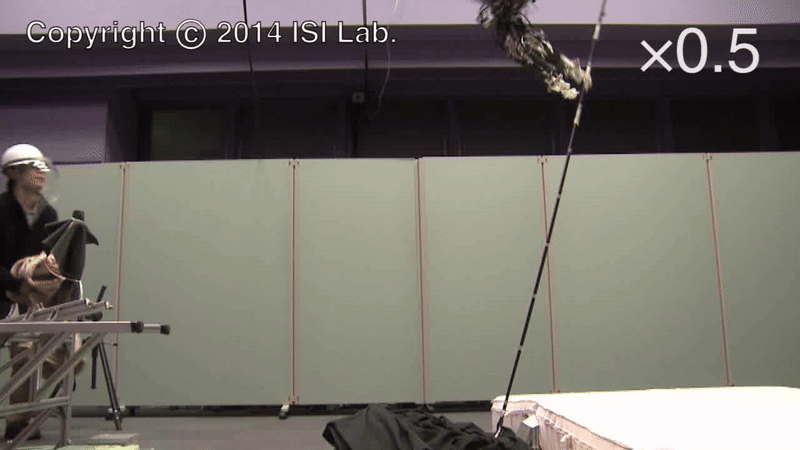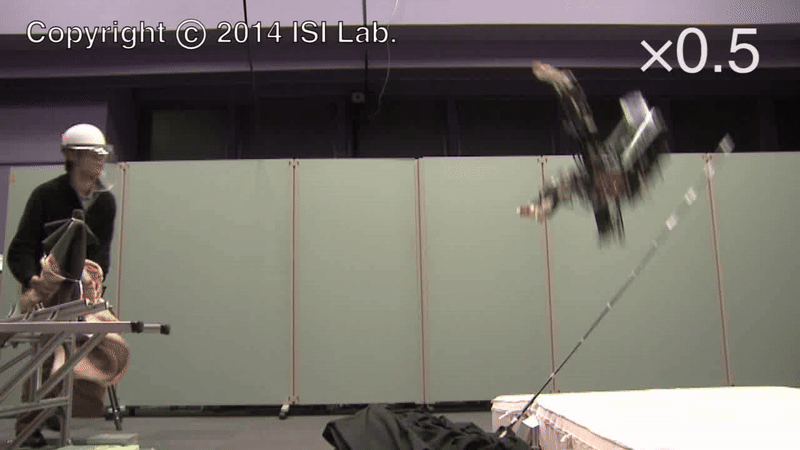
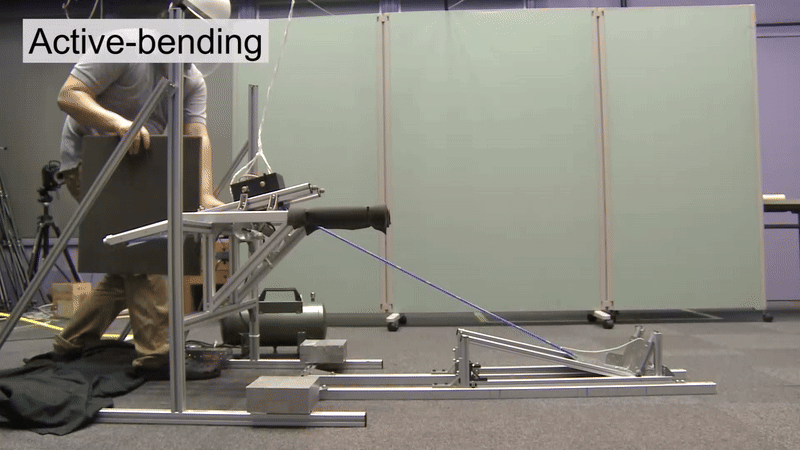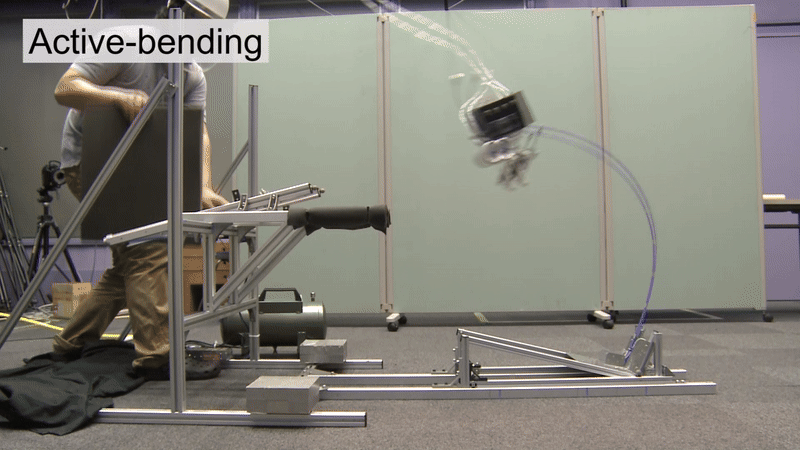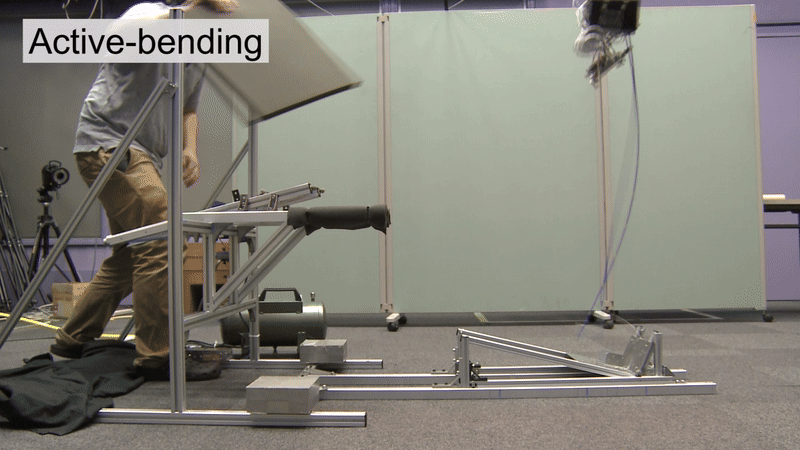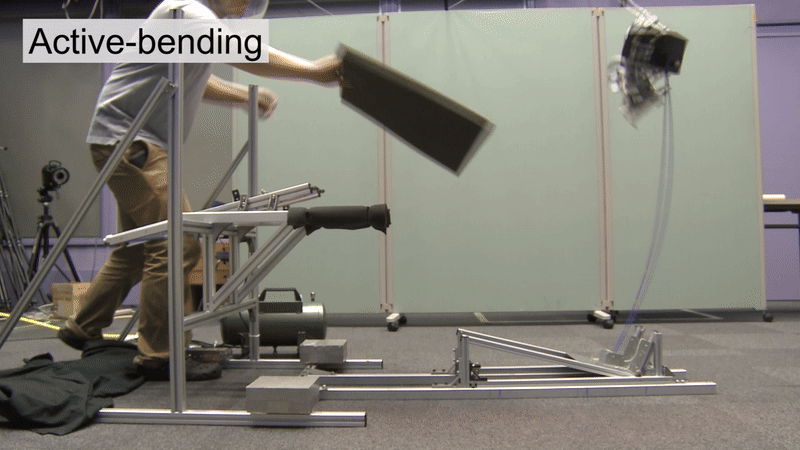
A dual hand robot achieves pole vaulting to jump 1.67m.
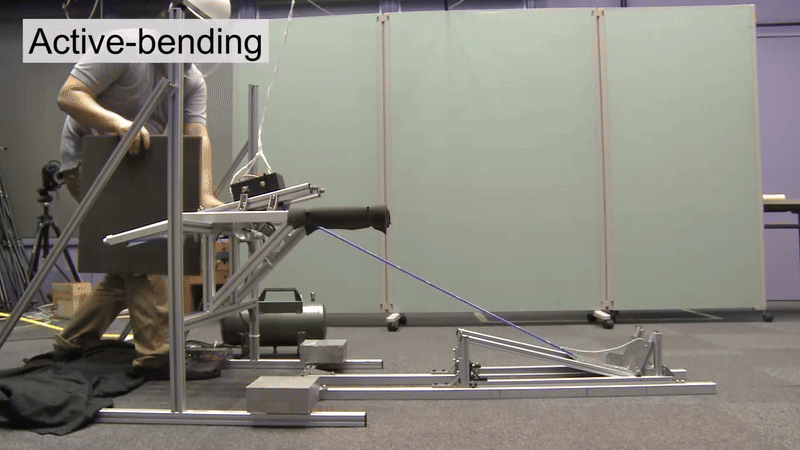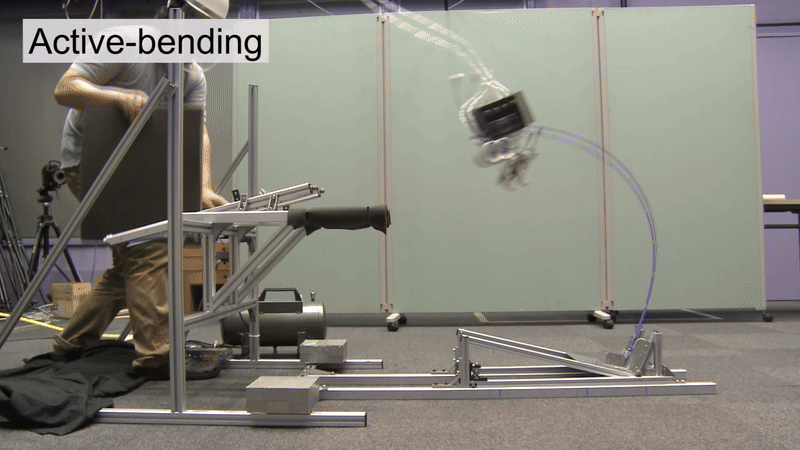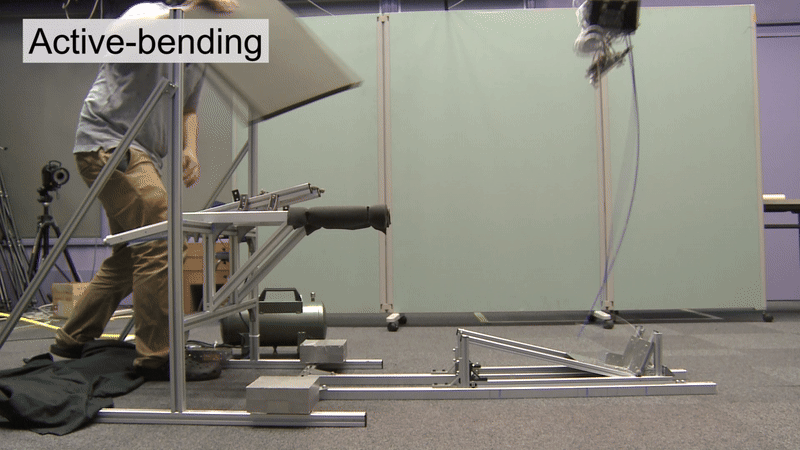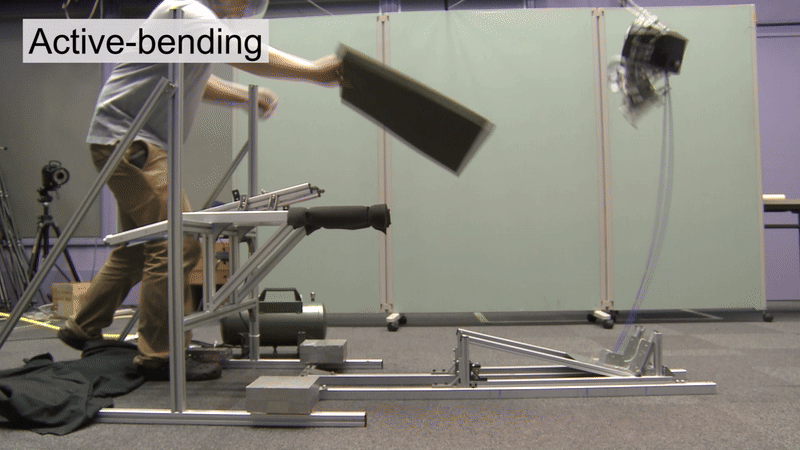
Robotic active bending motion during pole support phase improves reachable height of the robot.
Sports Biomechanics from the Perspective of Robotics
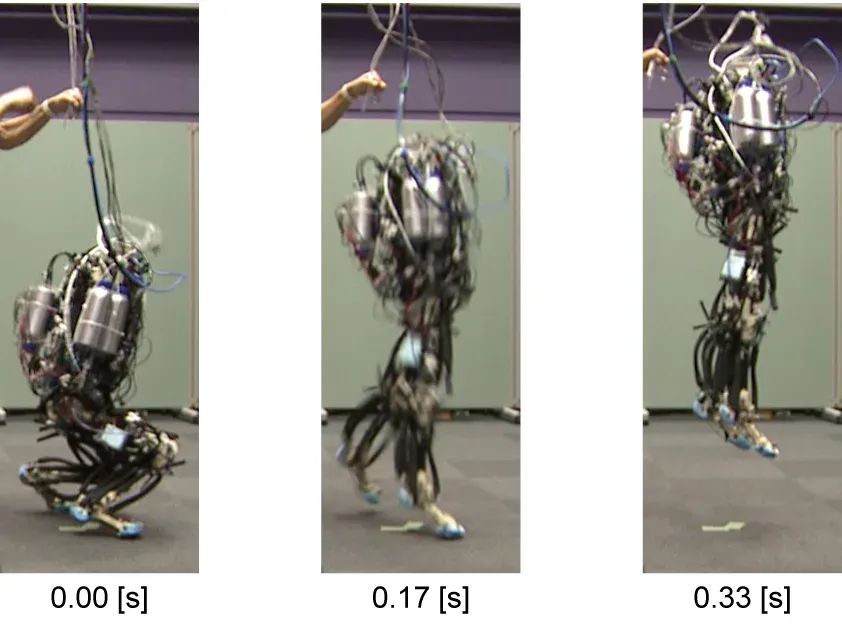
Angle-dependent moment arm (ADMA) extends the range of possible jumping postures for musculoskeletal robots.
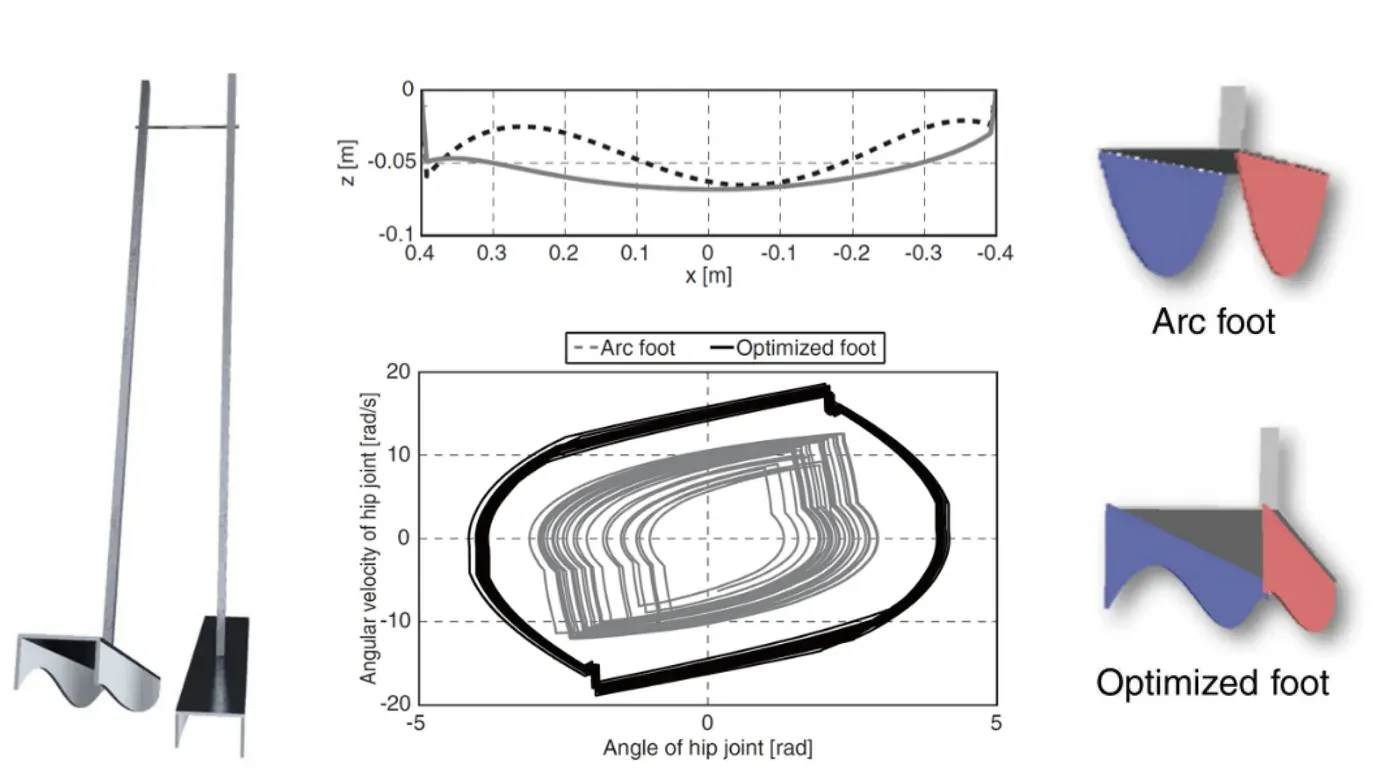
Optimized feet shape of the passive dynamic walker enhance its walking robustness in slope angles.
Optimizing foot shape of a passive dynamic walker enables robust walking against changes in slope inclination.
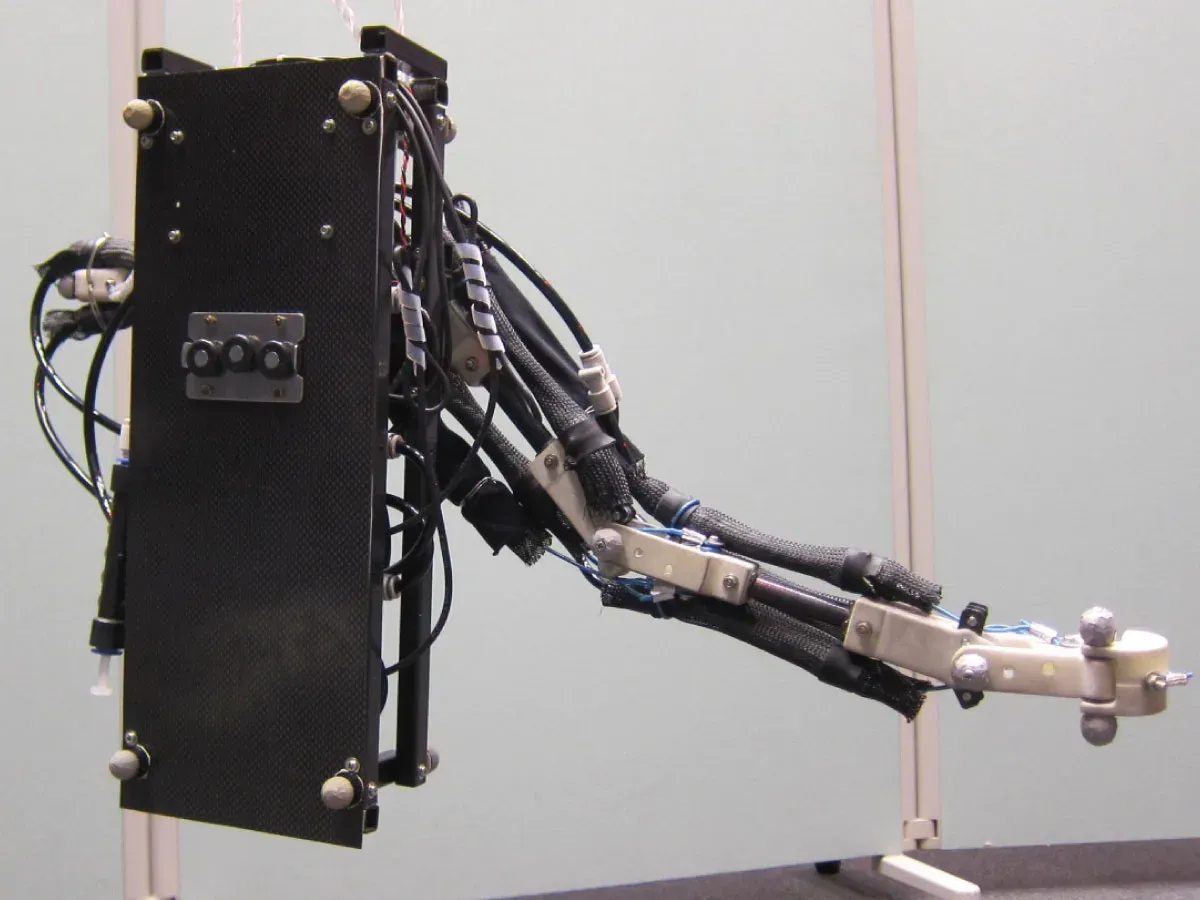
The swing-up motion in pole vaulting inertially generates bending moment on the pole.