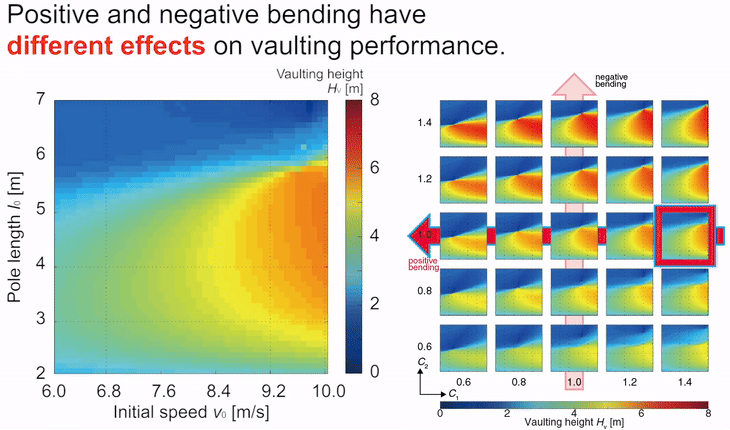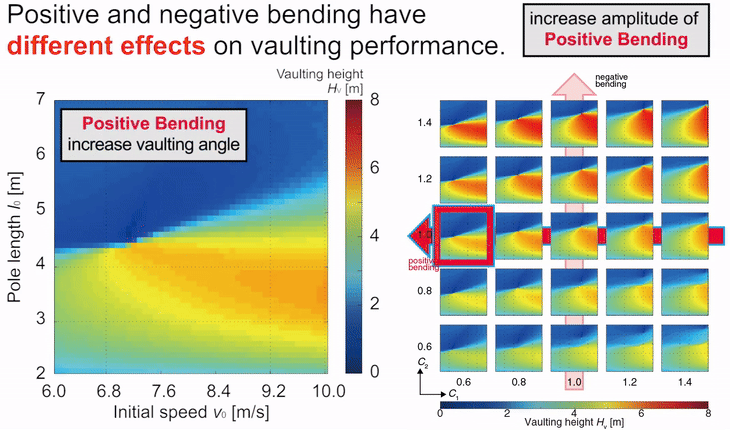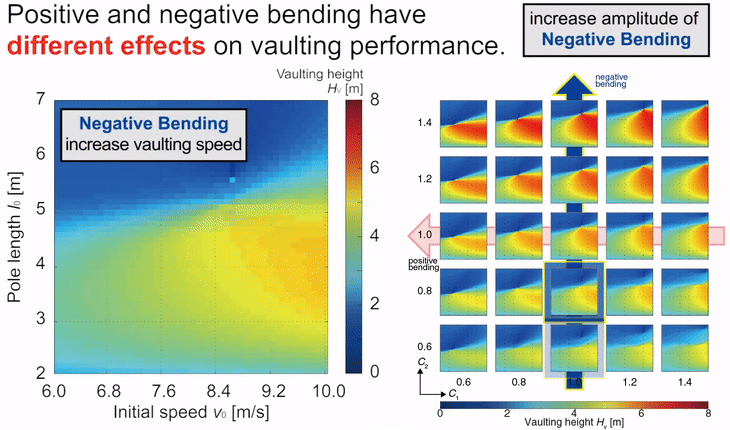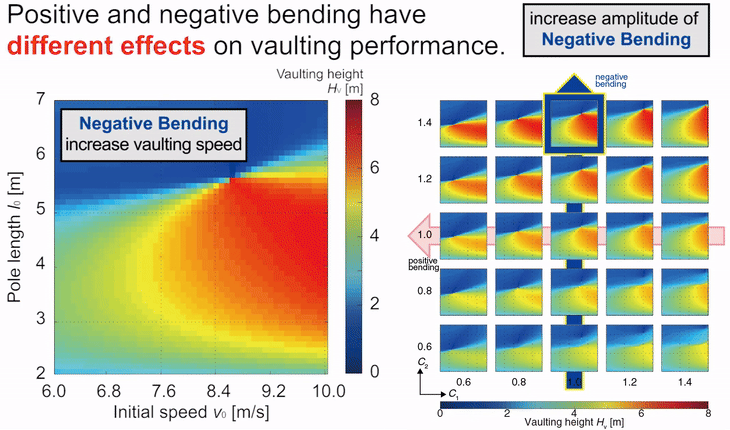
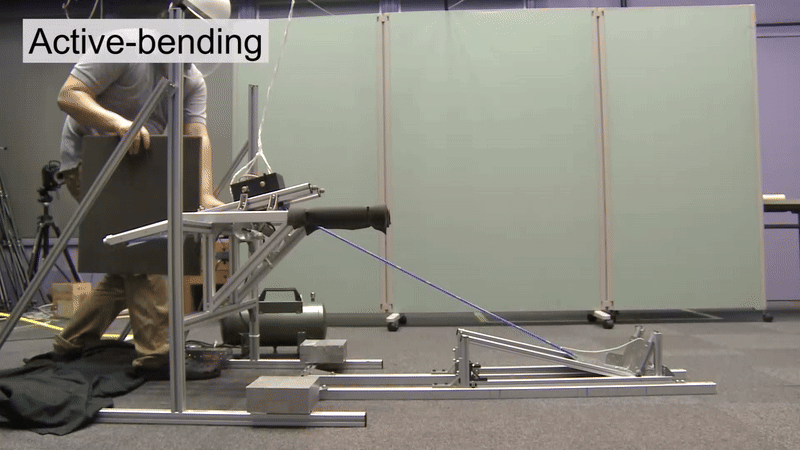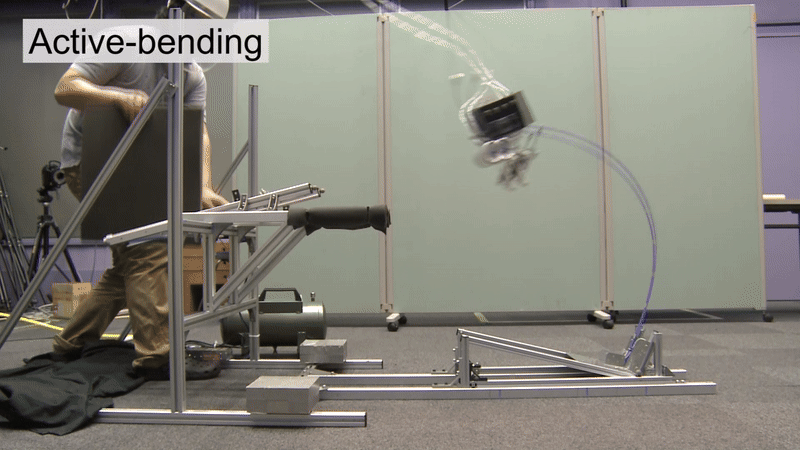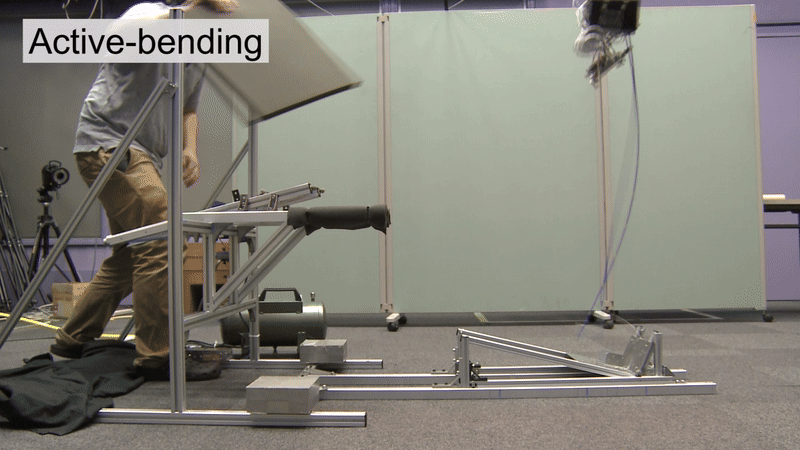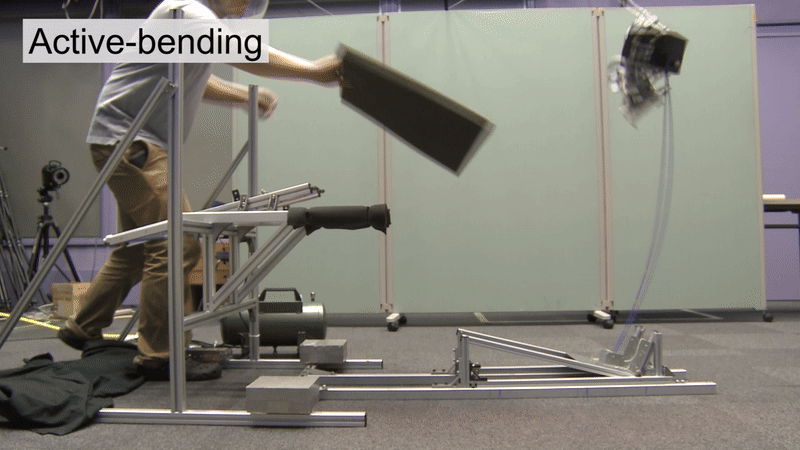
Active pole bending effect in pole support phase
Globally explore sensitivities and interacteve effects of motion parameters during pole support phase to increase vaulting height

tag
Globally explore sensitivities and interacteve effects of motion parameters during pole support phase to increase vaulting height
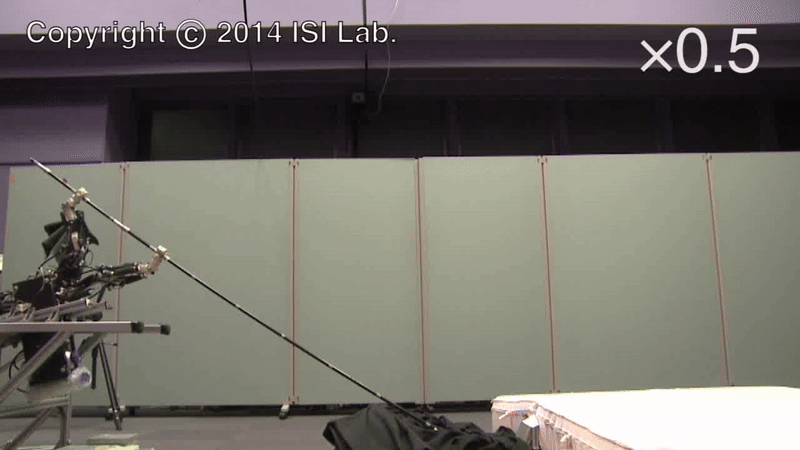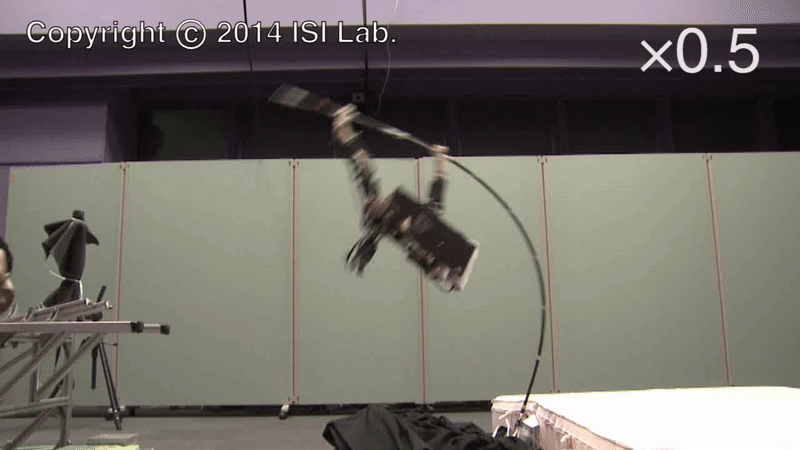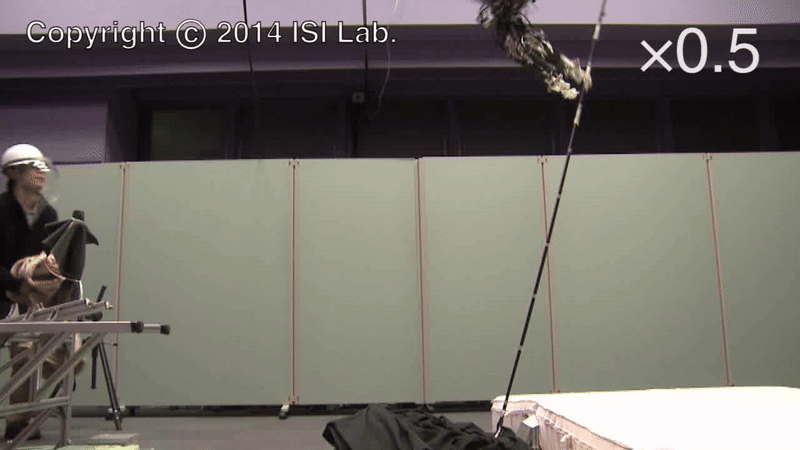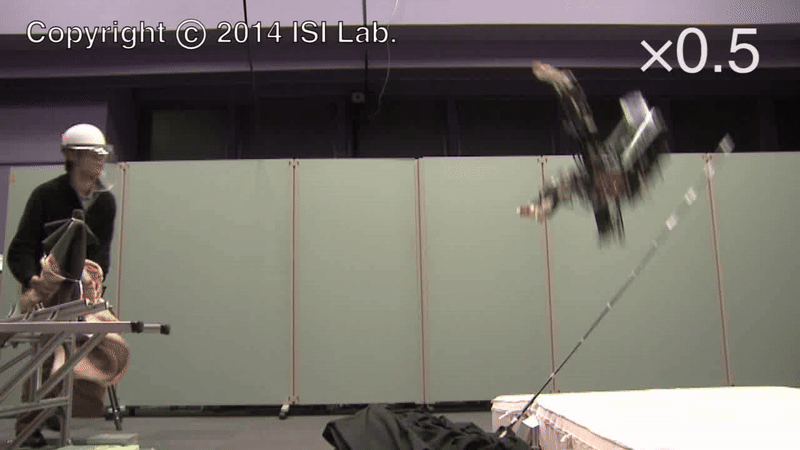
A dual hand robot achieves pole vaulting to jump 1.67m.
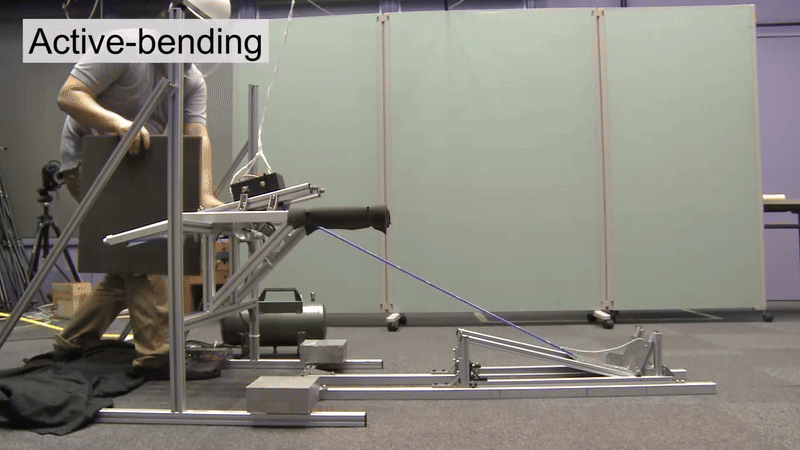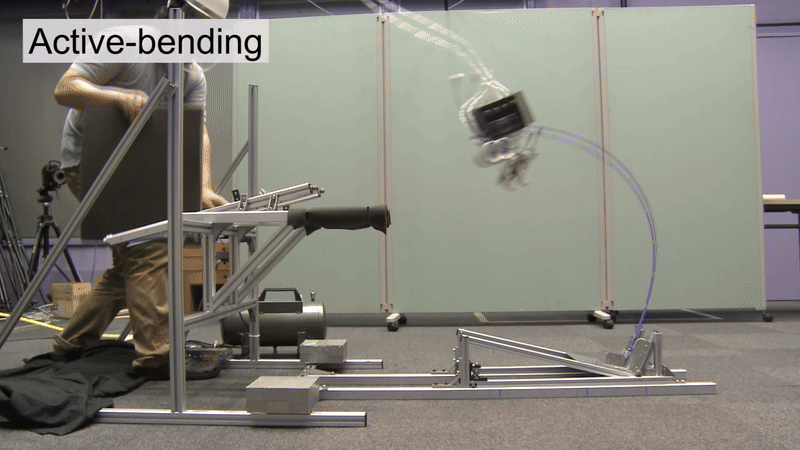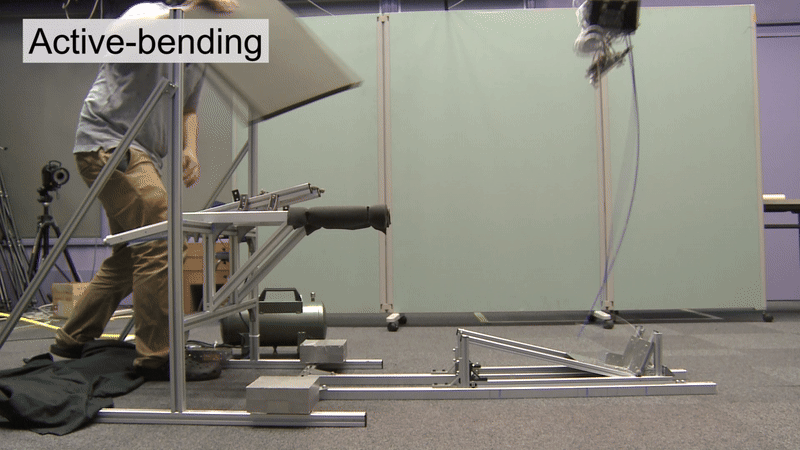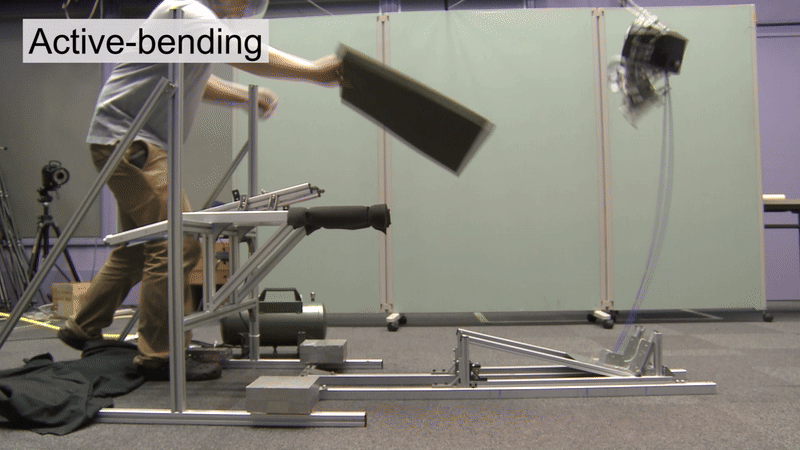
Robotic active bending motion during pole support phase improves reachable height of the robot.
Sports Biomechanics from the Perspective of Robotics
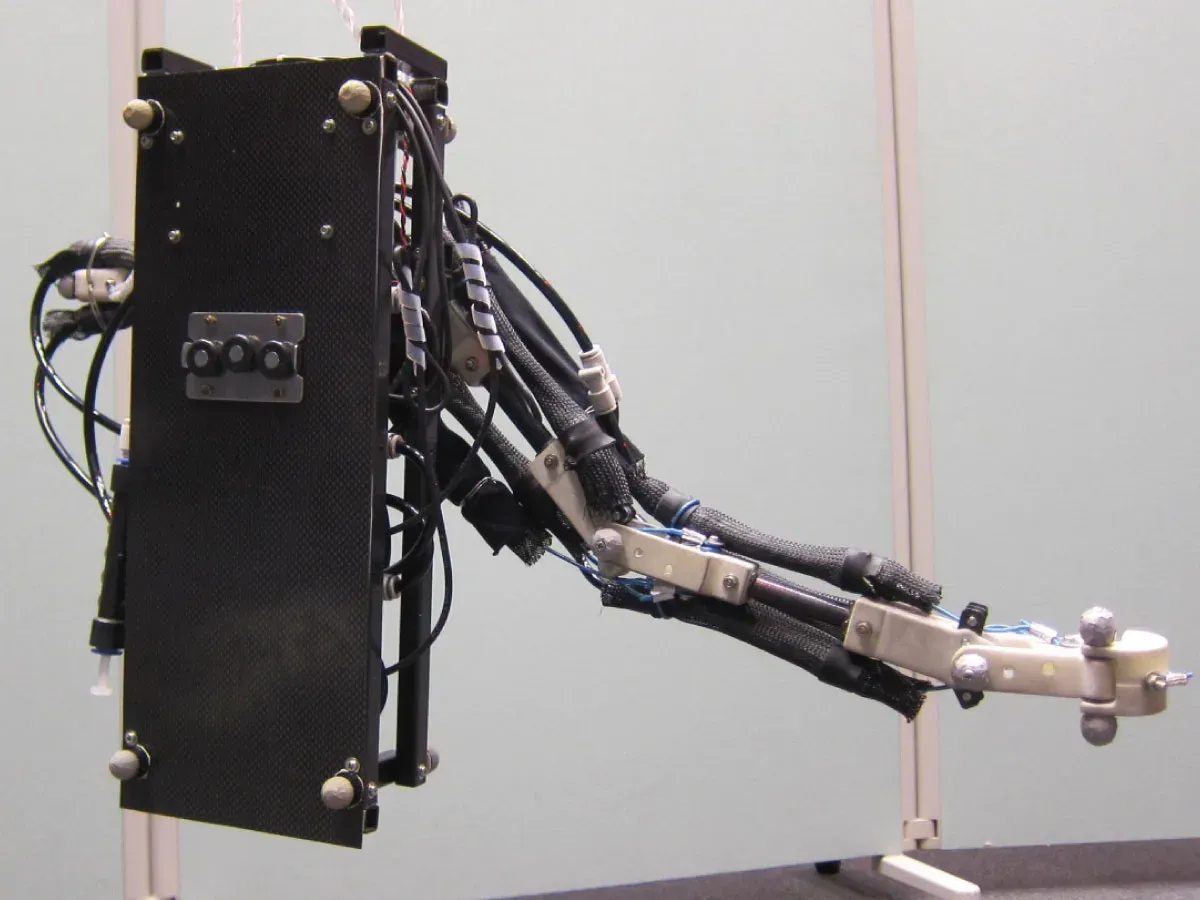
The swing-up motion in pole vaulting inertially generates bending moment on the pole.
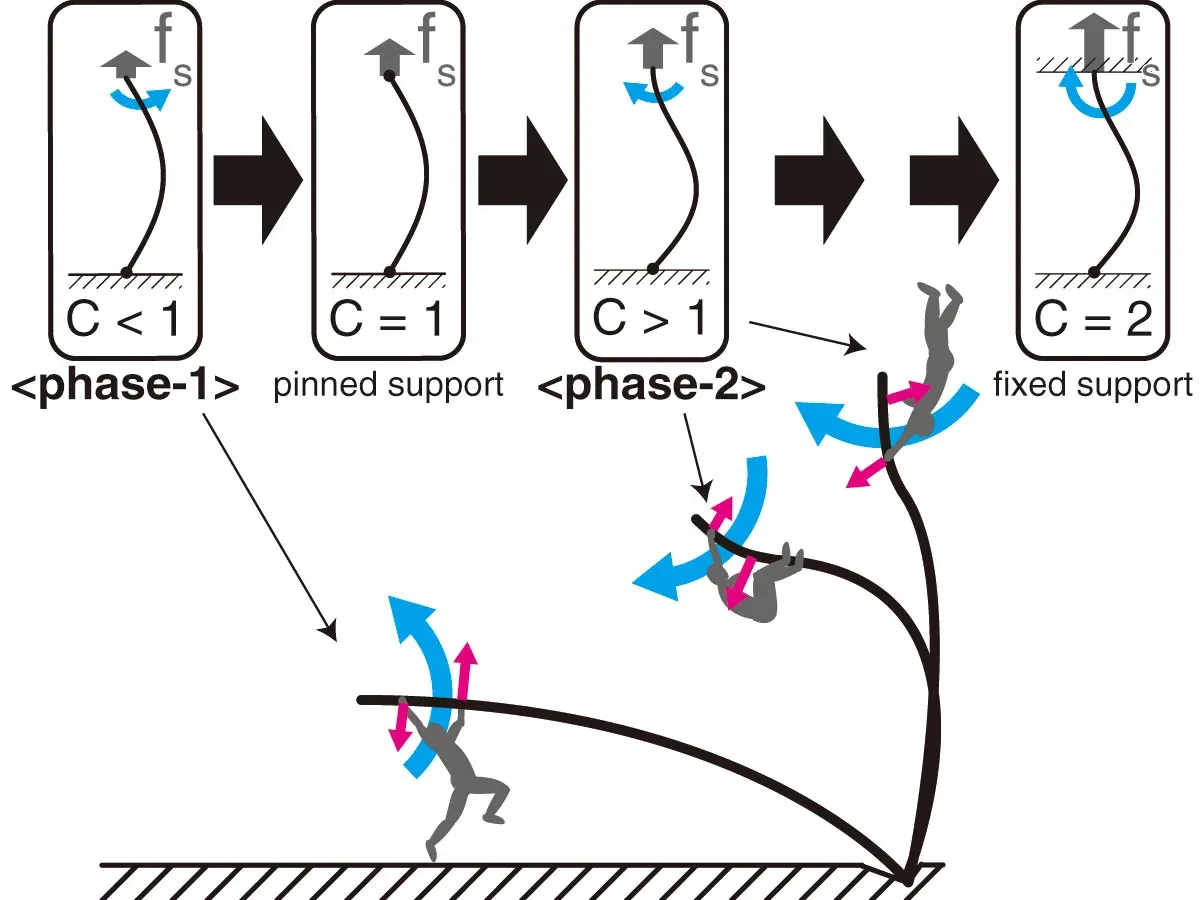
Pole vaulters actively bend the poles to improve vaulting height.