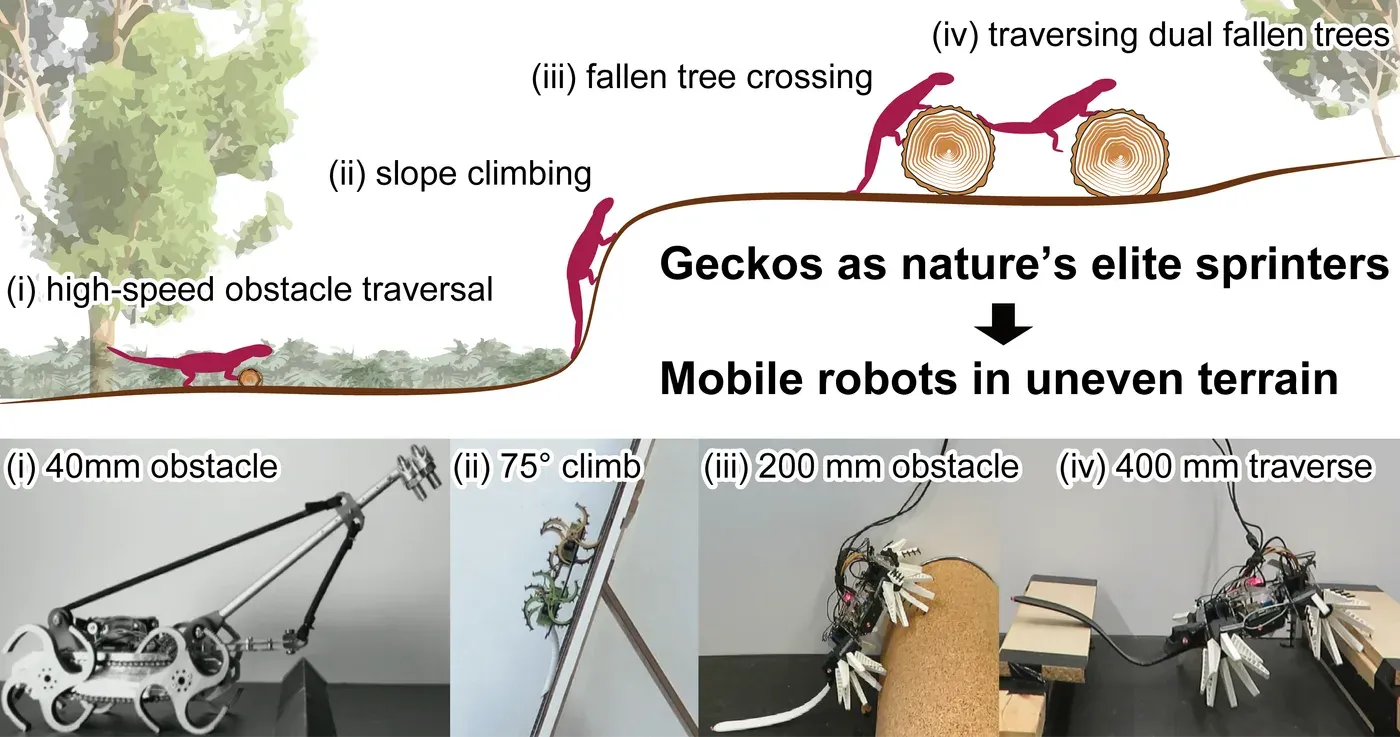
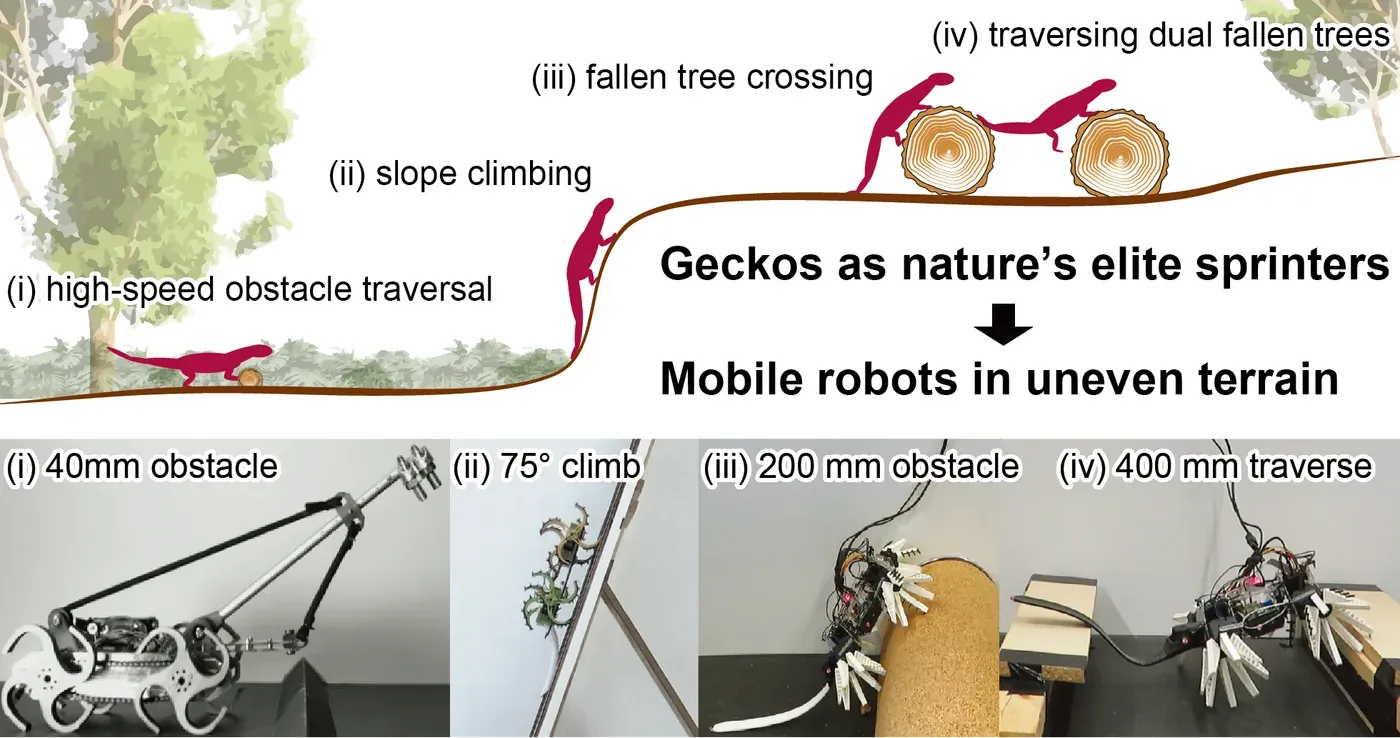
Compliance, mass distribution and contact forces in cursorial and scansorial locomotion with biorobotic physical models自然界のトップスプリンターであるトカゲの形態学的知性は、ロボットの非構造的環境下におけるロコモーションを可能にする。