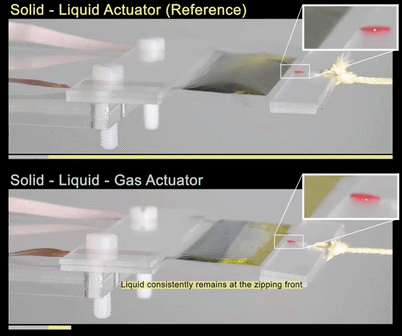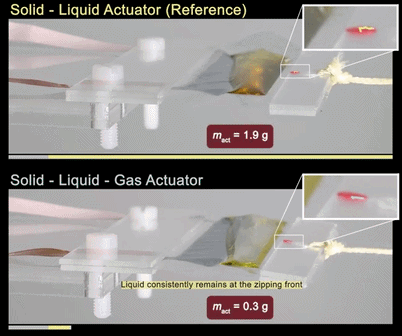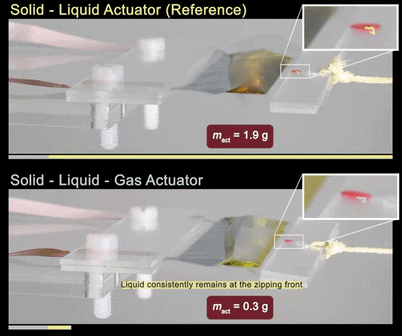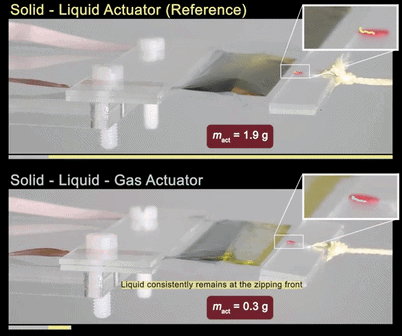
Ultralight soft electrostatic actuators based on solid-liquid-gas architectures
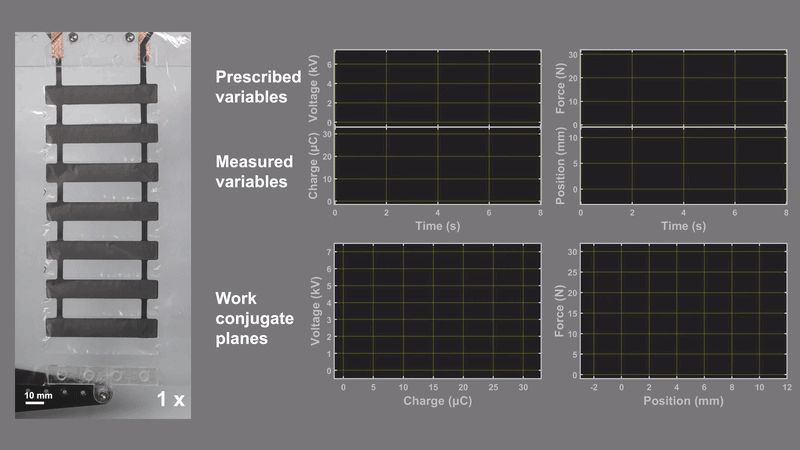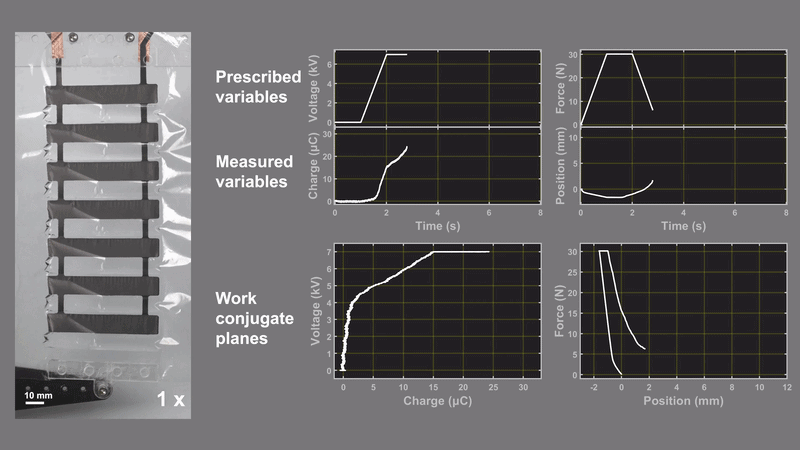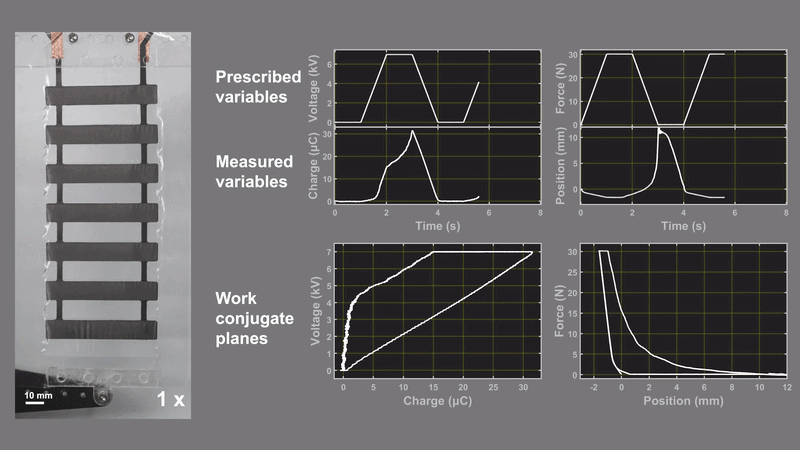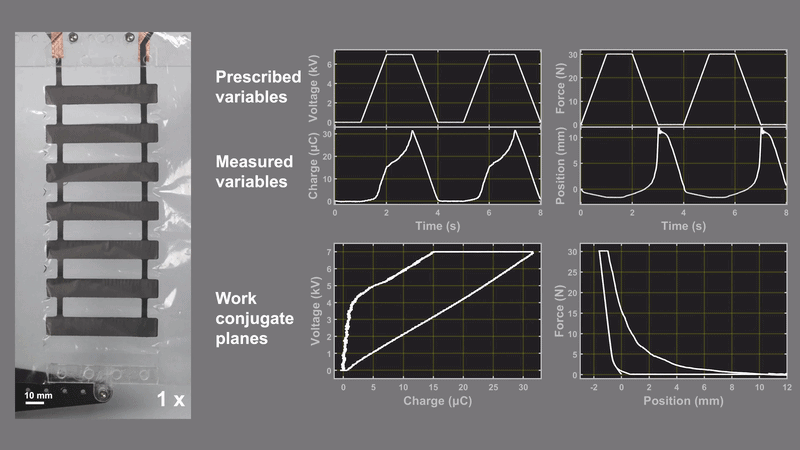
液体–固体アクチュエーターに第3相の気体誘電体を導入することで超軽量ソフト静電アクチュエーターを実現する。

publications
この条件に一致する項目はありません。別のカテゴリーや条件を選択してください。
液体–固体アクチュエーターに第3相の気体誘電体を導入することで超軽量ソフト静電アクチュエーターを実現する。
共役平面上の閉サイクルを利用してソフト静電アクチュエーターのエネルギー効率を解析・向上させる。
柔軟な静電油圧人工筋肉は脚式ロボットの俊敏で適応性が高く、エネルギー効率に優れたロコモーションを実現する。
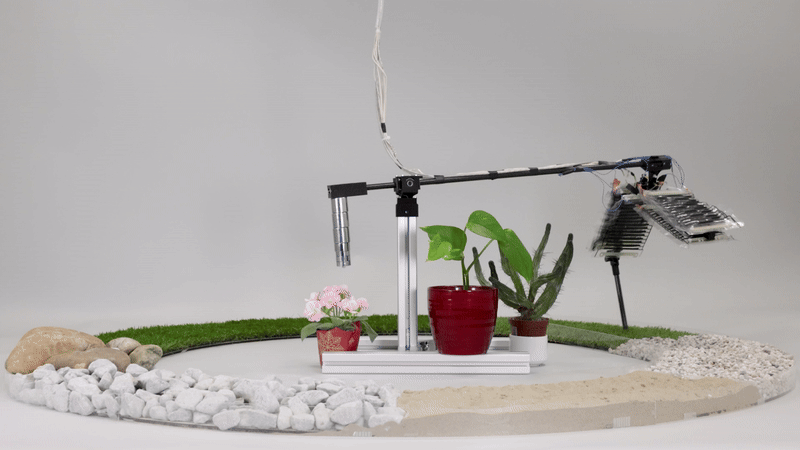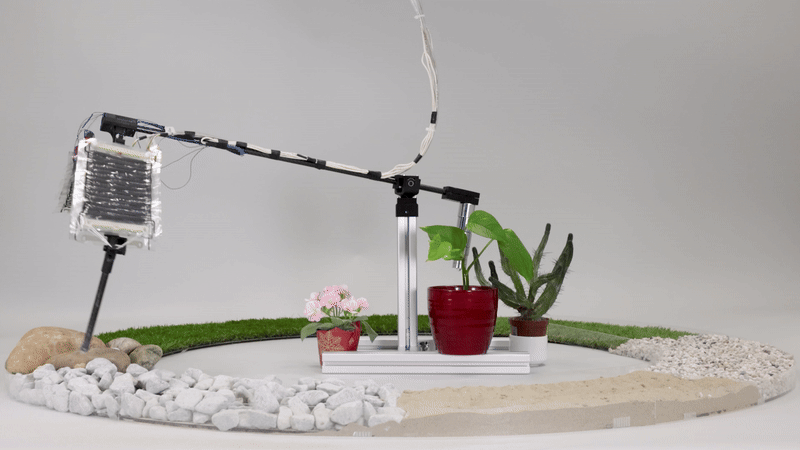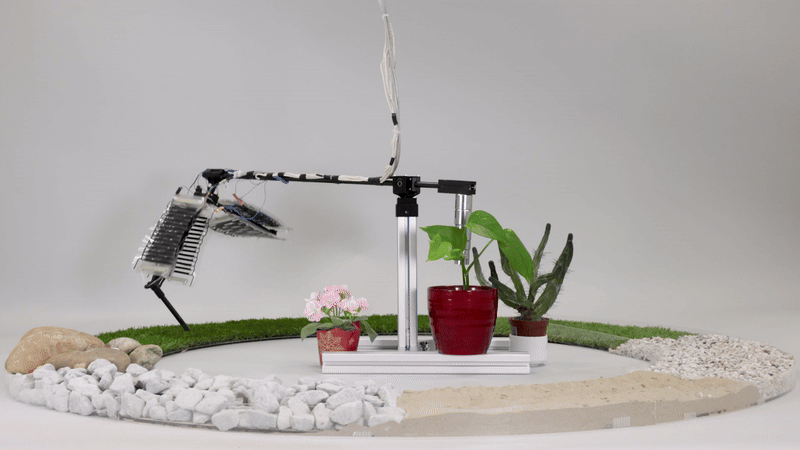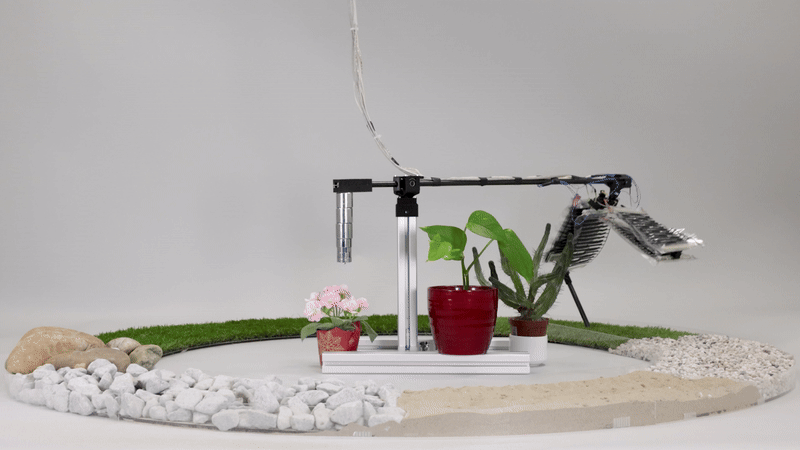
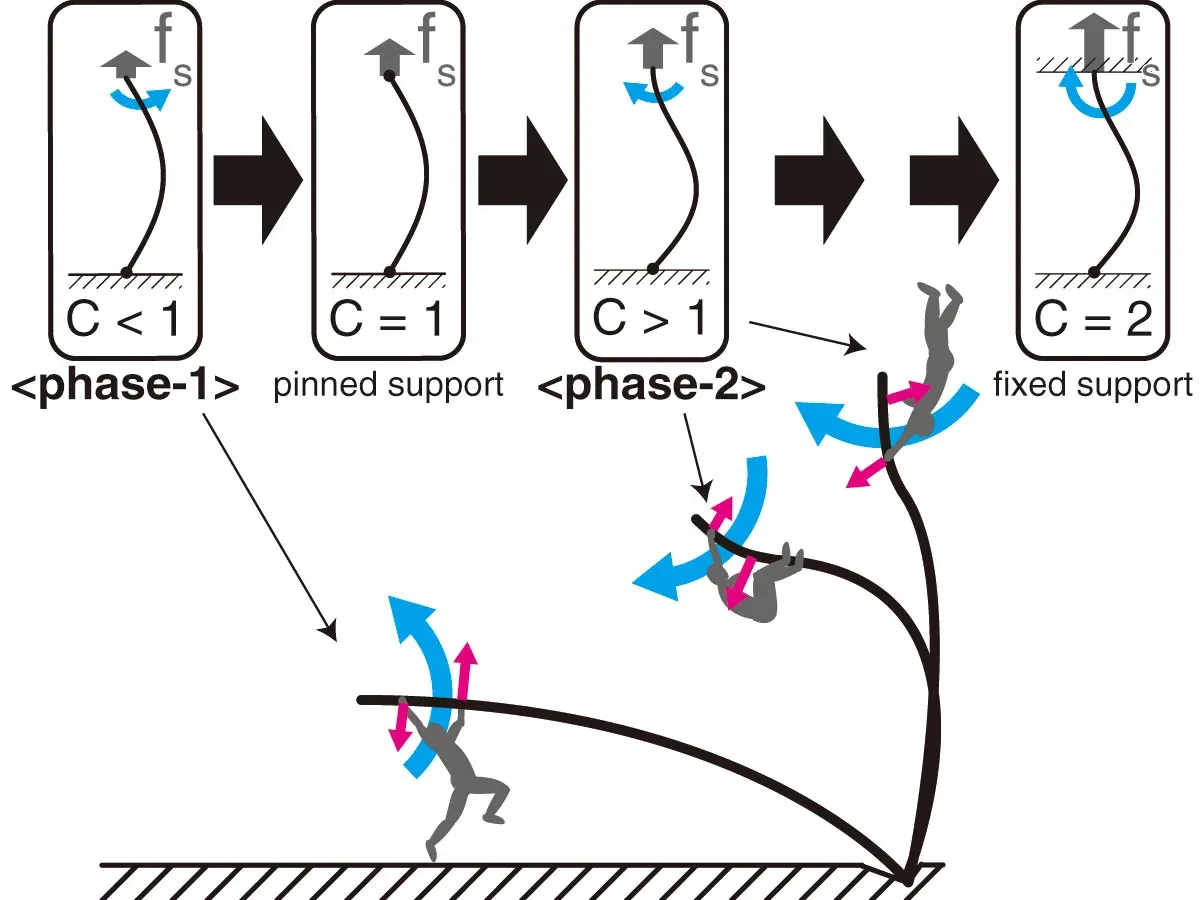
ポール高跳び高さ向上のために大域的かつ相互作用を考慮したポール支持期の動作パラメーター空間を探索する。
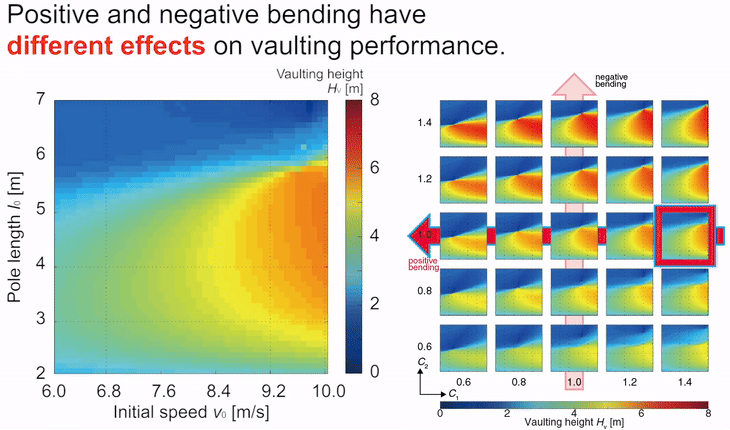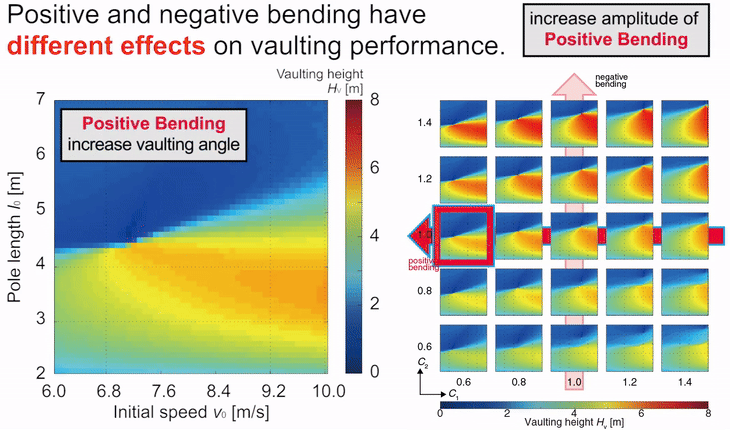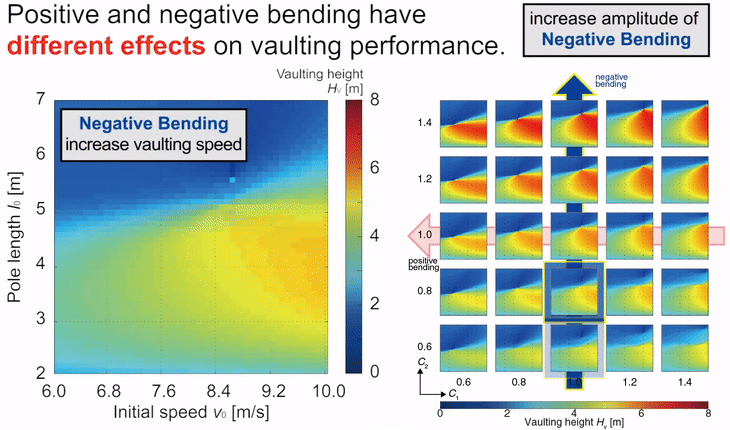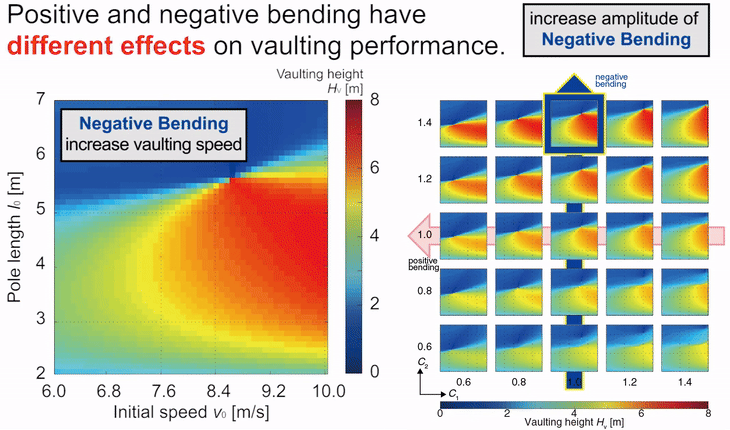
Integrative and Comparative Biology
リスの体重のたった3%重量の尻尾の慣性力は、予想外な落下から空中で立ち直りを可能にし、安全な着地を実現する。
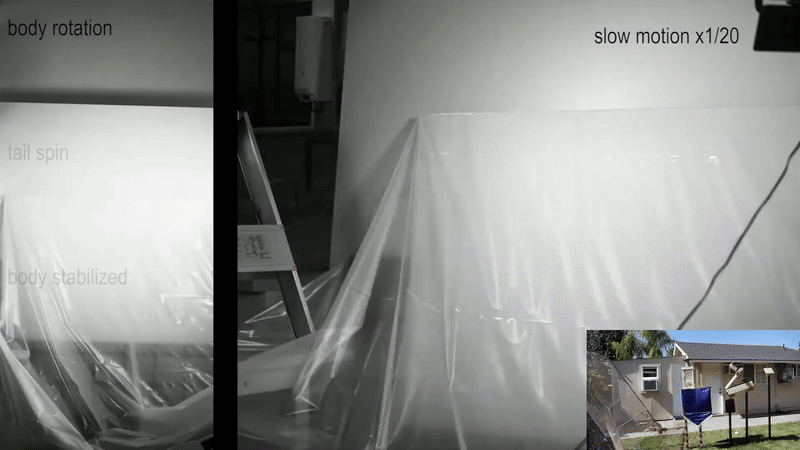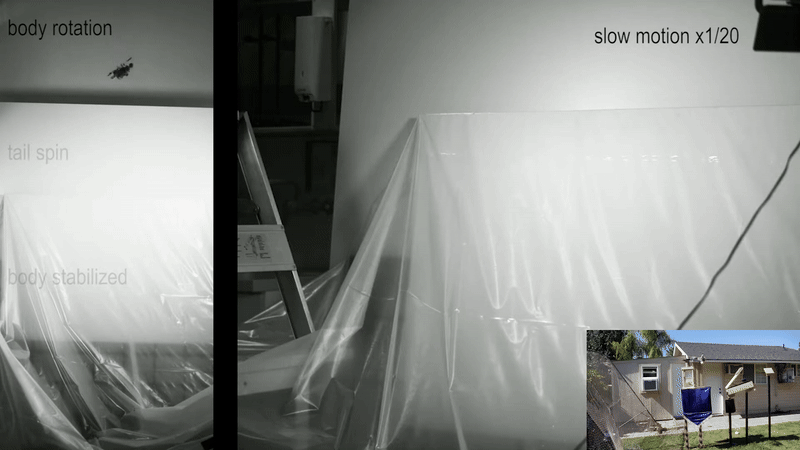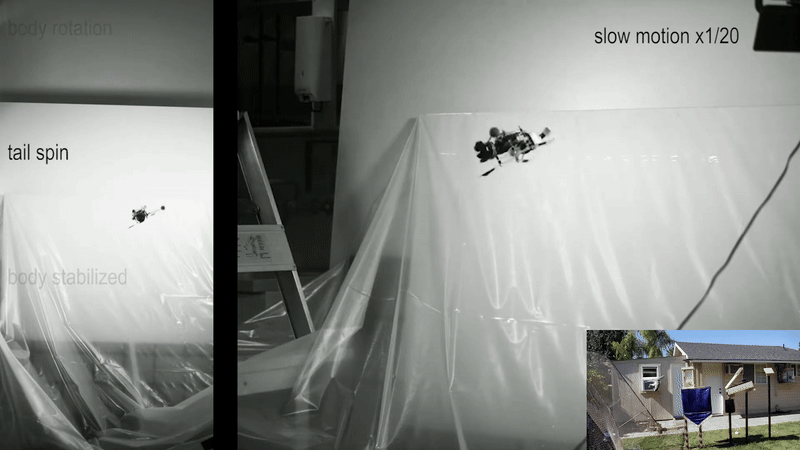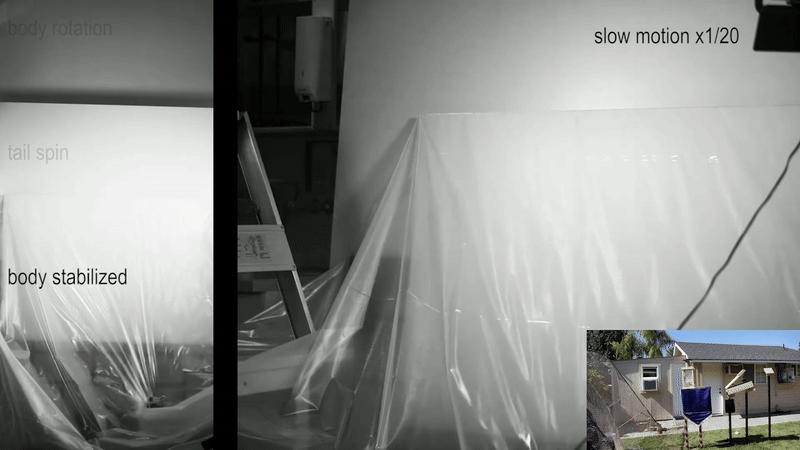
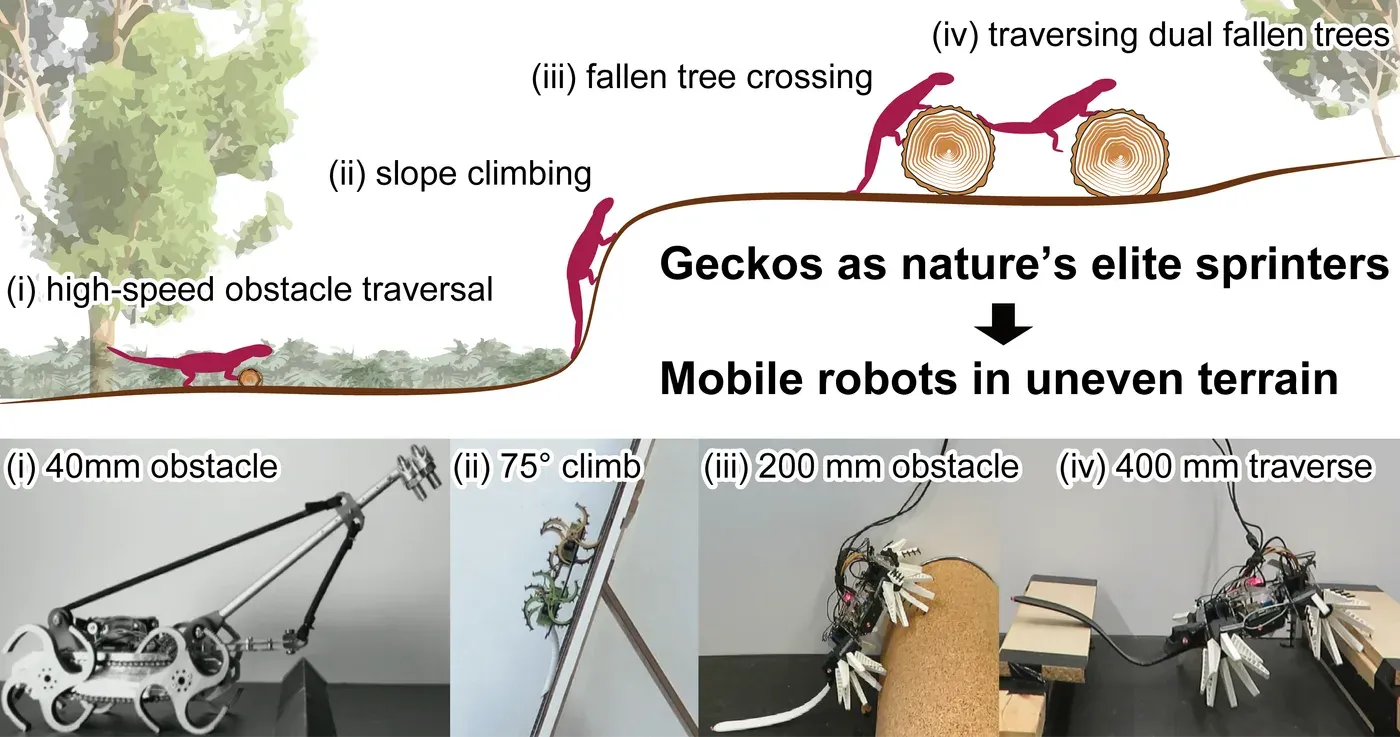
自然界のトップスプリンターであるトカゲの形態学的知性は、ロボットの非構造的環境下におけるロコモーションを可能にする。
eGaInセンサーとデータドリブンなモデルで完全に柔軟な魚ロボットの実時間制御を実現する。
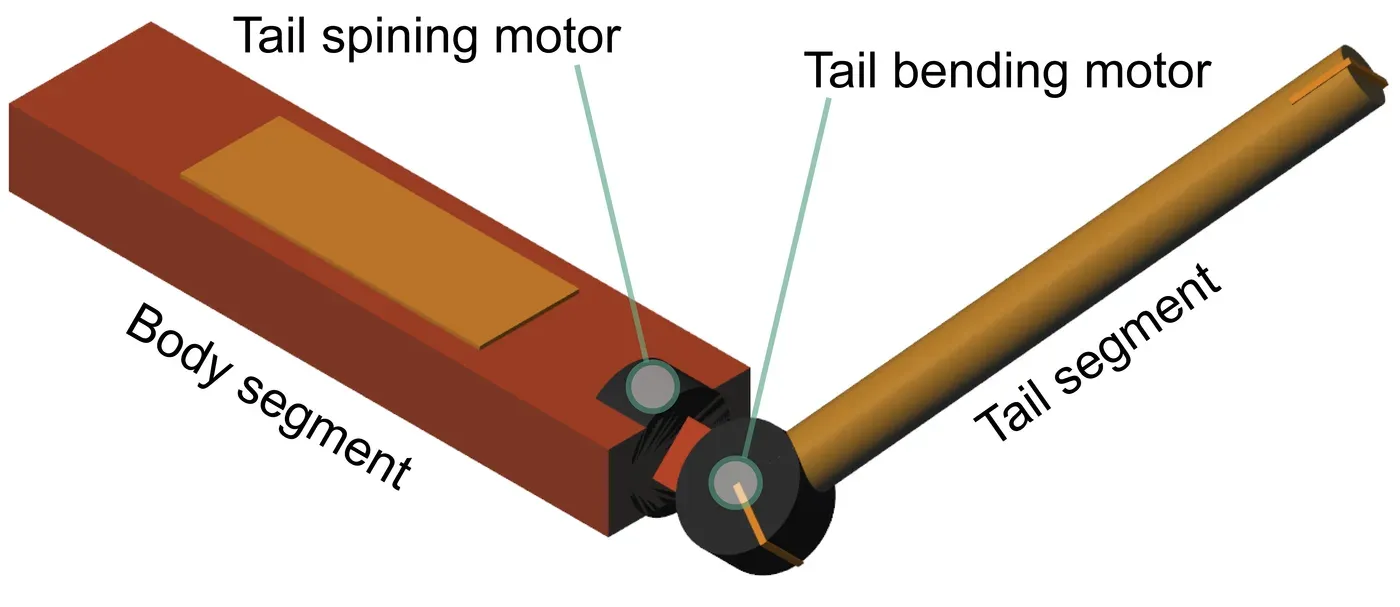
尻尾の慣性動作はリスの空中での姿勢制御を可能にする。
双腕ヒューマノイドロボットにより、1.67mの棒高跳びに成功する。
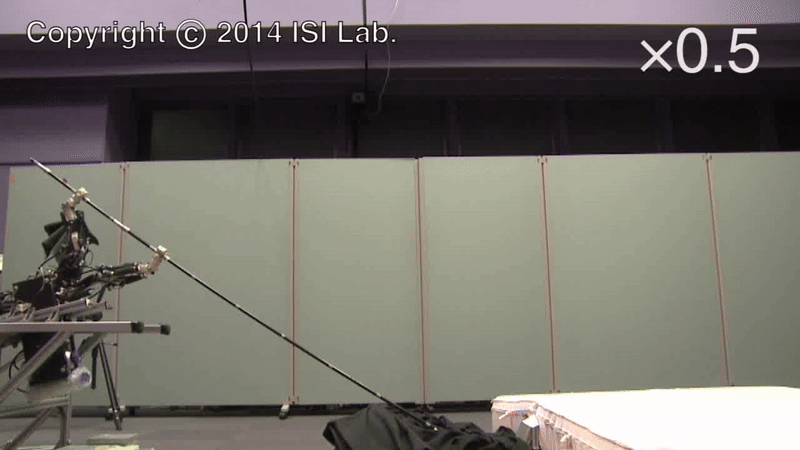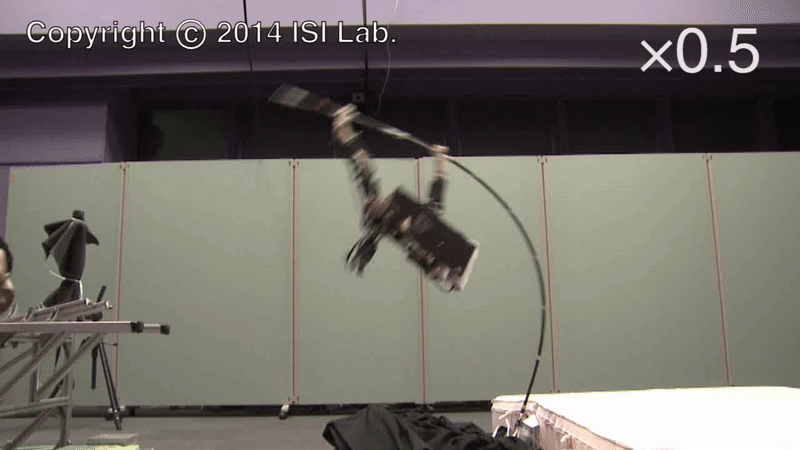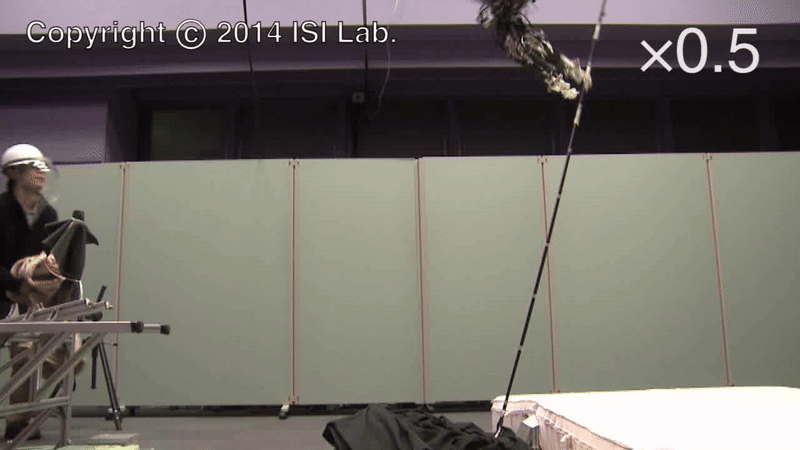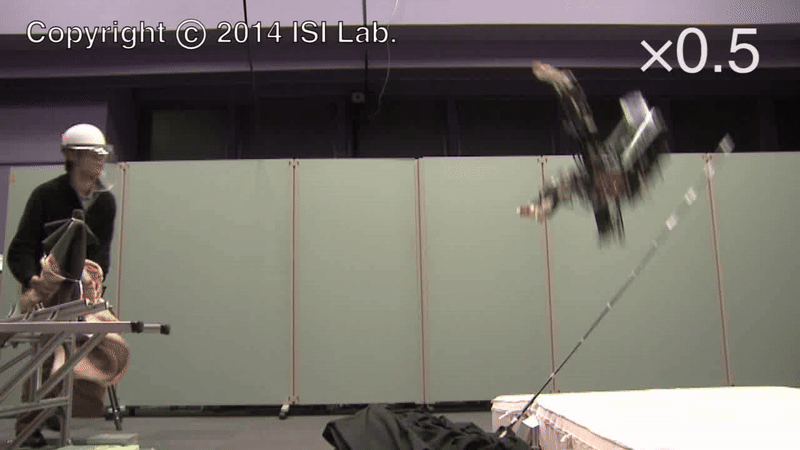
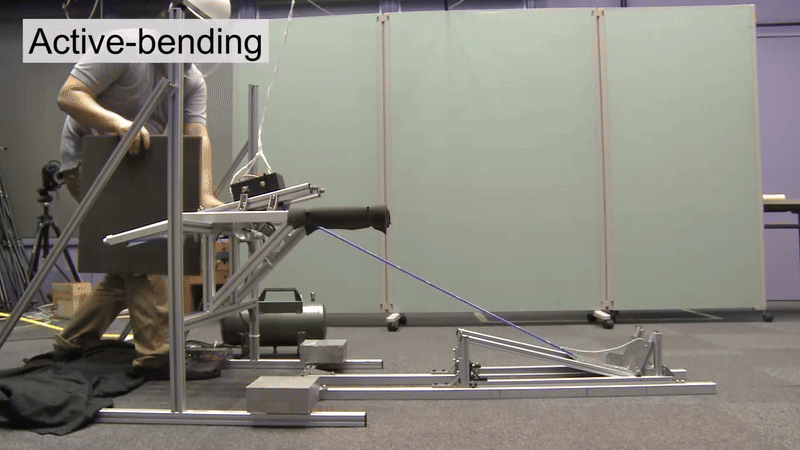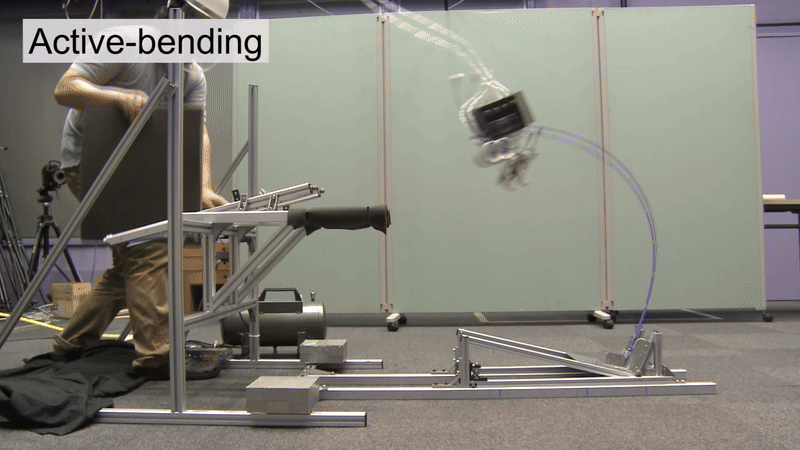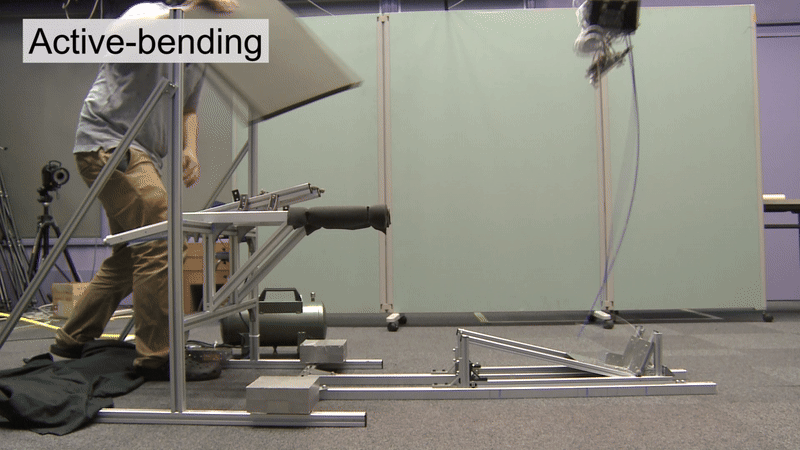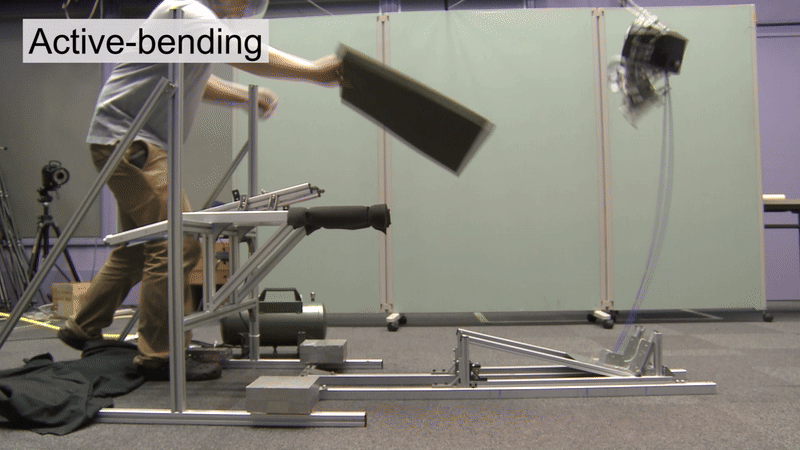
ポール支持期における能動ポール曲げ動作は棒高跳びロボットの跳躍高さを向上させる。
角度依存モーメントアーム機構は筋骨格ロボットの跳躍可能姿勢の幅を広げる
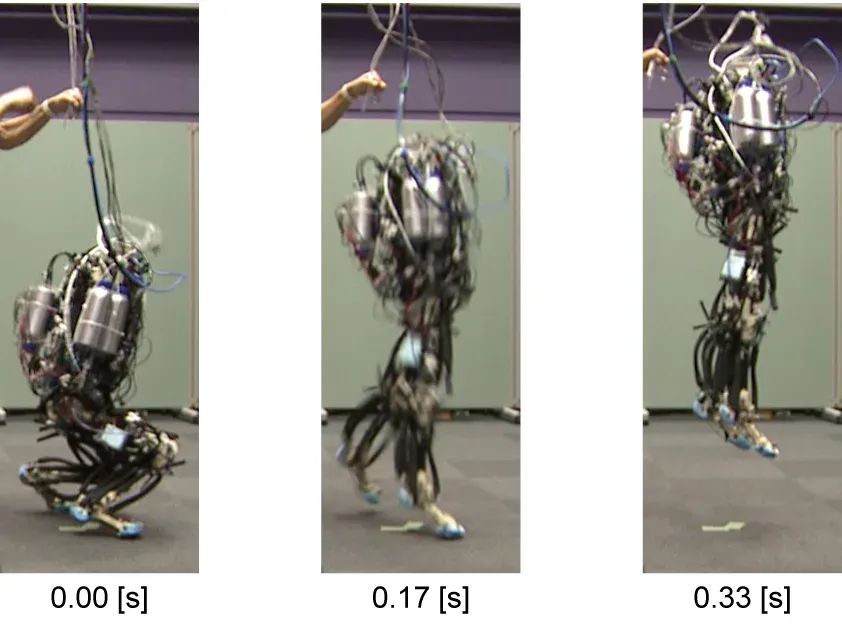
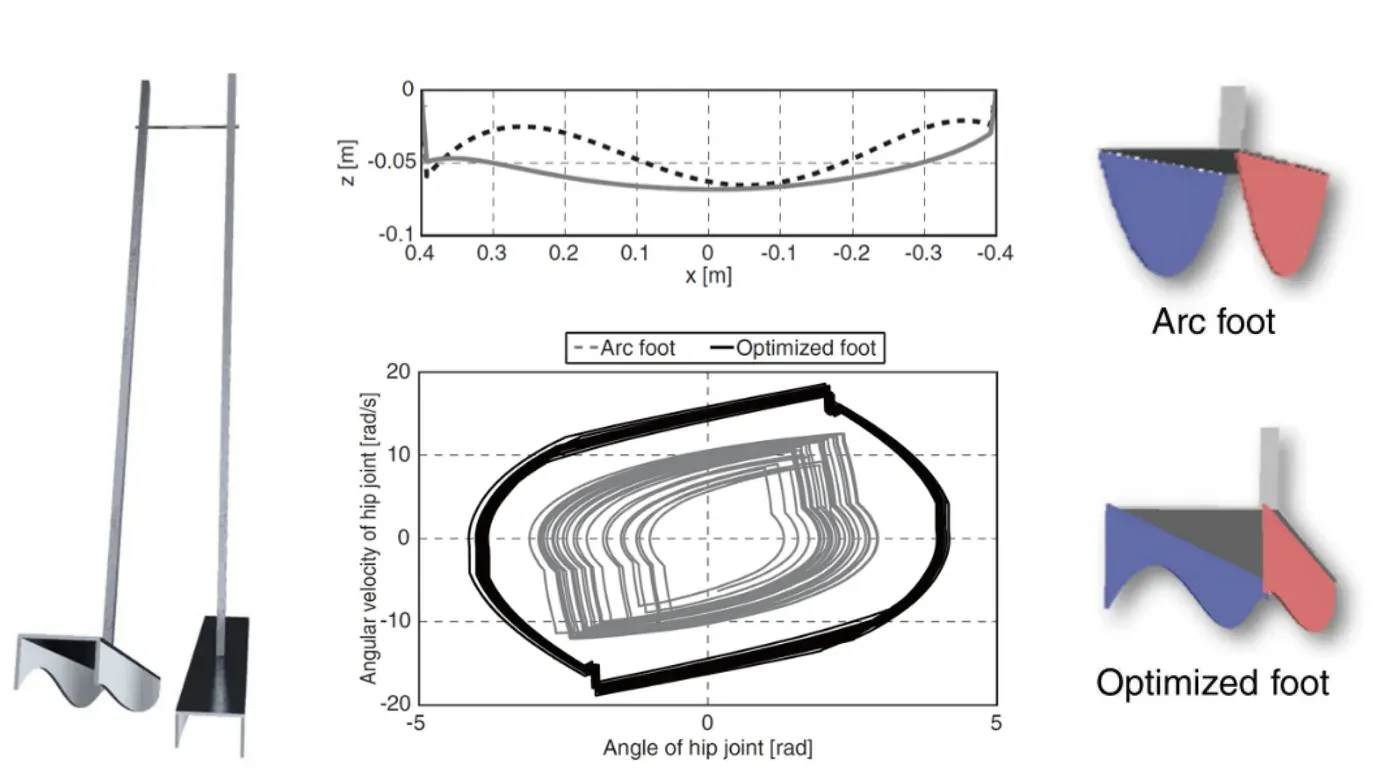
棒高跳びにおけるスイング動作は慣性的にポールに曲げモーメントを印可する。
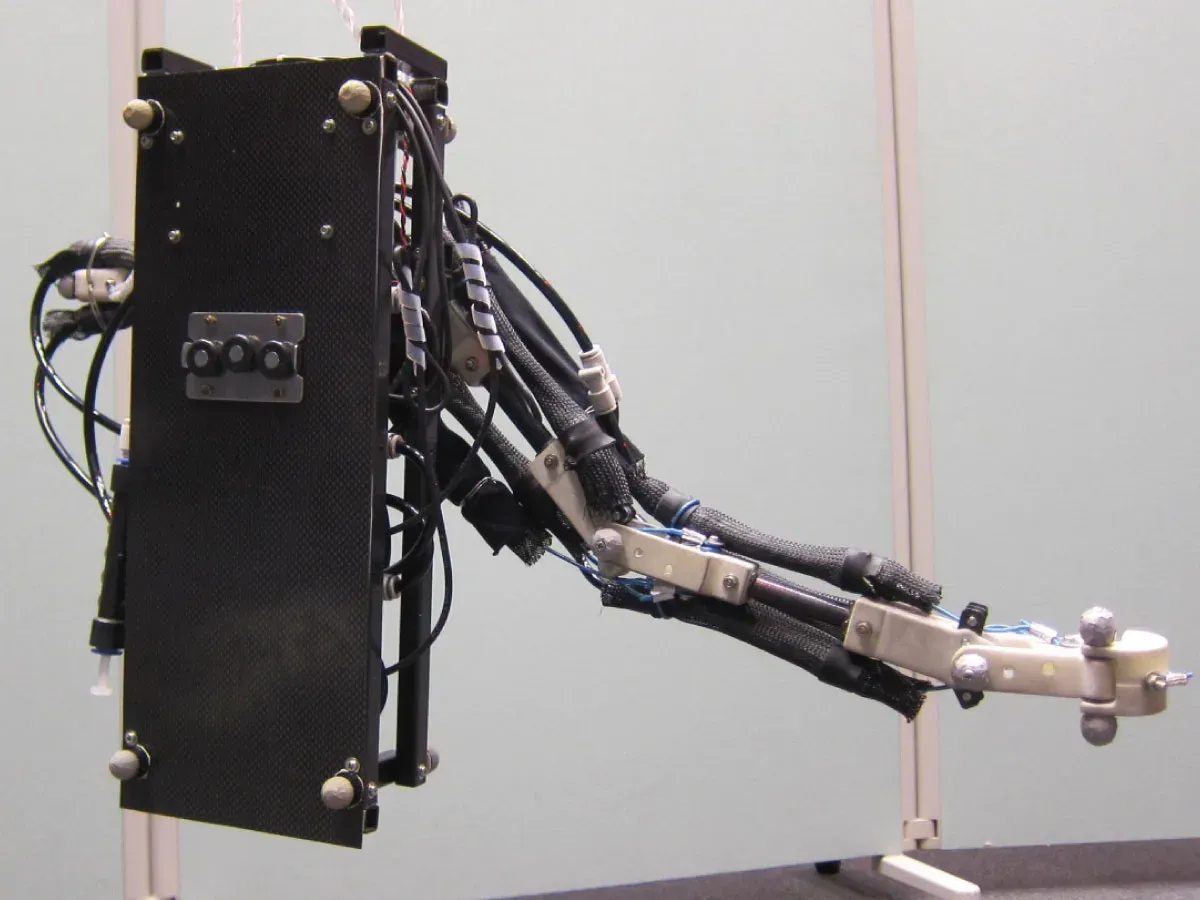
棒高跳びにおける能動的ポール曲げ動作は跳躍高さを向上させる。