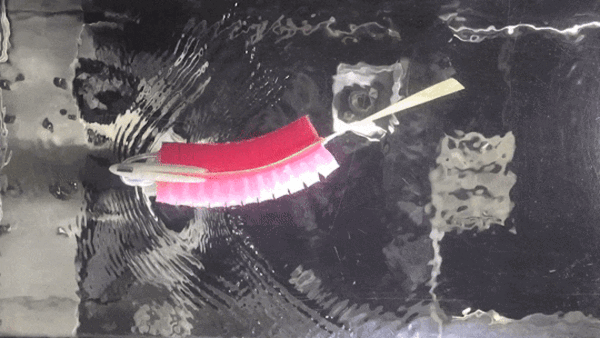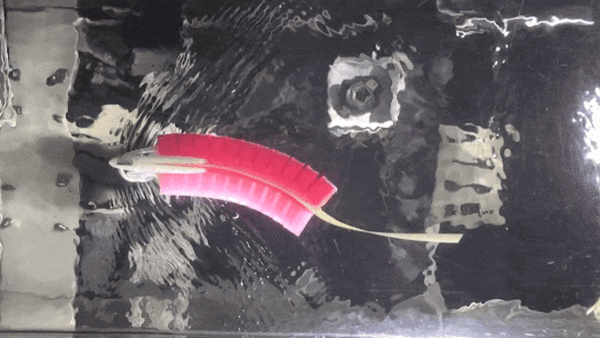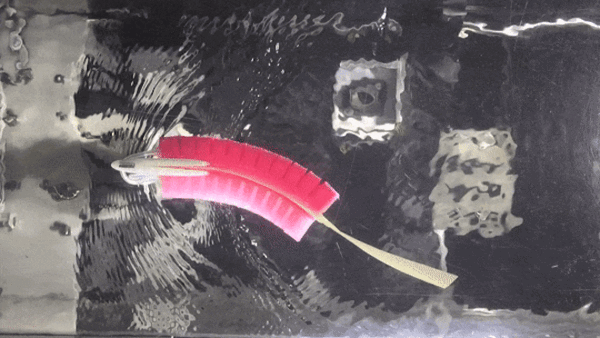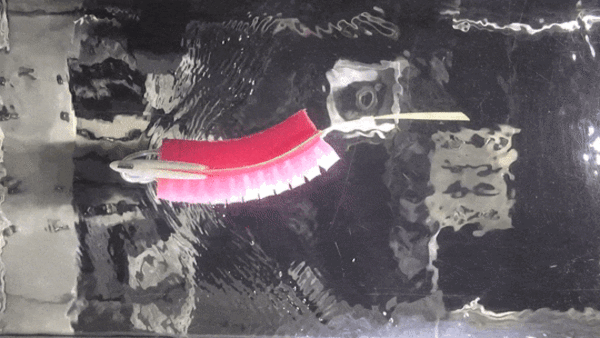
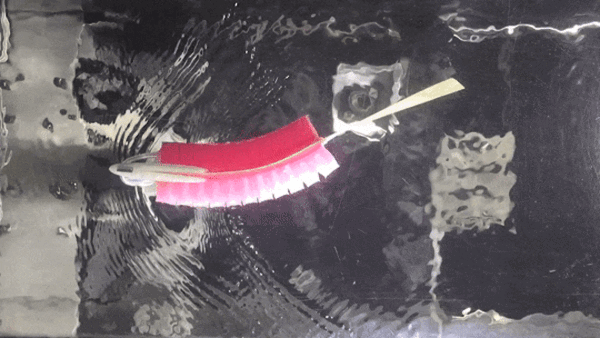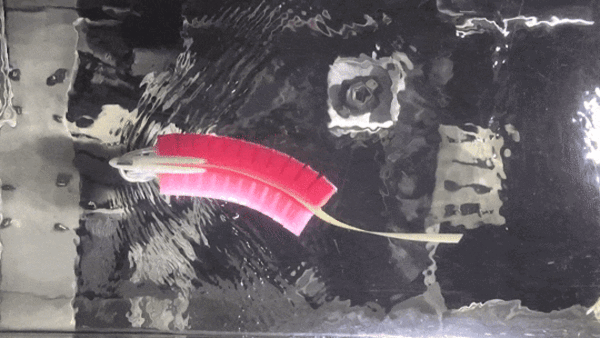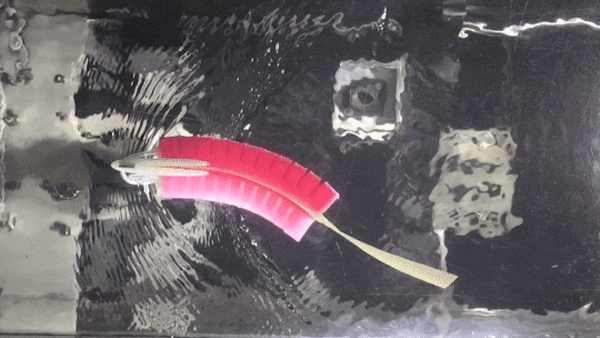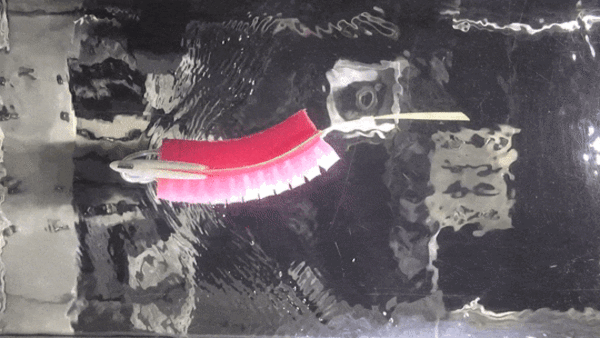
Modeling and control of a soft robotic fish with integrated soft sensingeGaInセンサーとデータドリブンなモデルで完全に柔軟な魚ロボットの実時間制御を実現する。