
Abstract
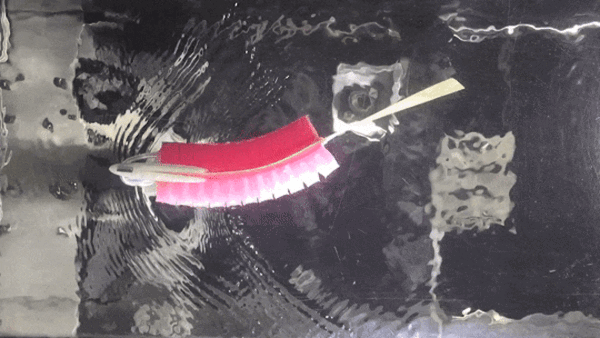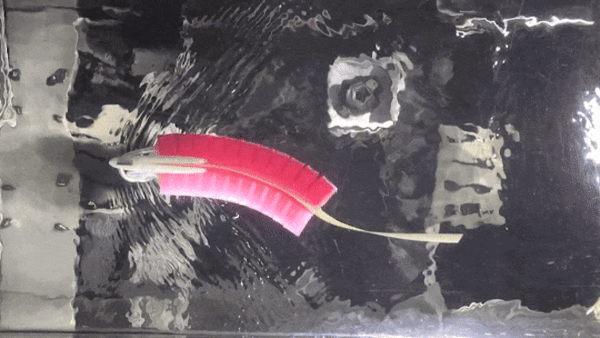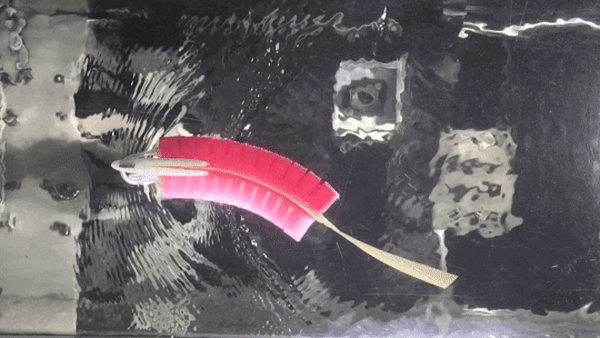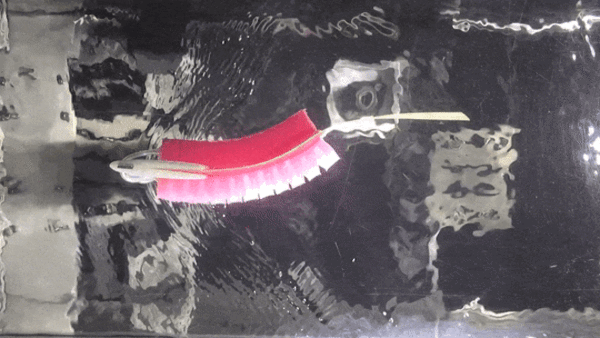
ソフトロボティクスは、よりリアルで斬新な運動形態を実現する手段としてだけでなく、ロボットモデル動物を用いて複雑なバイオメカニクスを理解するツールとしても利用できる。ここでは、拮抗的な高速 PneuNet アクチュエータと、ひずみ計測用のシリコンチャンネルに埋め込まれた超弾性ガリウム-インジウム共晶(eGaIn)を用いた、完全にソフトな subcarangiform で遊泳可能な魚ロボットのうねりの力学的制御について紹介する。コントローラを設計するために、実験データと遺伝的アルゴリズムを用いて調整し、正確かつ軽量なシミュレーションを可能にする、シンプルなデータドリブンなパラメータアプローチを開発した。このモデルは、ソフトアクチュエータの拮抗的共収縮の影響を含め、駆動周波数の範囲と圧力振幅の範囲にわたってロボットの挙動を正確に予測する。このモデルを用いて振幅コントローラを試作し、ロボットに適用することで、完全なソフトアクチュエータとリアルタイムのひずみ計測を用いて、尾部の振幅を制御する。
Citation
@article{lin2023modeling,
 author = {Lin, Yu-Hsiang and Siddall, Robert and Schwab, Fabian and Fukushima, Toshihiko and Banerjee, Hritwick and Baek, Youngjoon and Vogt, Daniel and Park, Yong-Lae and Jusufi, Ardian},
 journal = {Advanced Intelligent Systems},
 number = {4},
 pages = {2000244},
 title = {Modeling and control of a soft robotic fish with integrated soft sensing},
 volume = {5},
 year = {2023}
}
Download BibTeXロボット魚動物尻尾ソフトロボティクス生物規範ロボット制御ロコモーション遊泳身体性知能形態学的知性空圧アクチュエーターEGaInシミュレーション最適化日本語